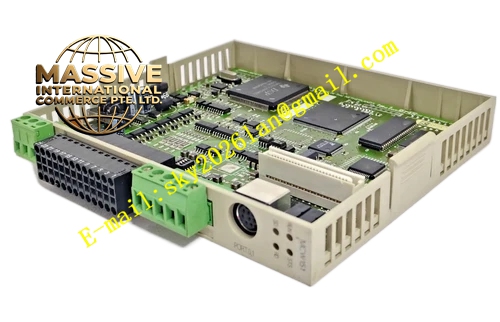
Description
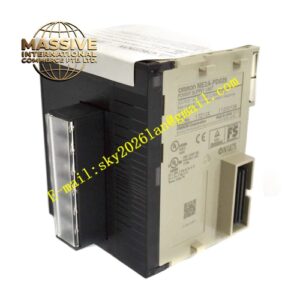
OMRON R88A‑MCW151‑E
Technical Specifications: Controllable axis quantity: 1 real axis, 1 virtual axis, 1 configurable auxiliary axis; programming language: BASIC motion programming; power supply requirement DC24 V external power input; total power consumption 4.0 W; built‑in digital I/O: 8‑point input, 4‑point output; 2 hardware registration trigger inputs; differential encoder input and output interface (A+,A‑,B+,B‑,Z+,Z‑); communication interfaces: Host Link serial port; multi‑task program execution support; operating temperature 0‑55°C; storage temperature ‑20‑70°C; operating humidity 10‑90%RH without condensation; dimensions 20 mm × 142 mm × 128 mm; weight 200 g; DIN‑rail mounting structure.
Functional Features: Stand‑alone motion operation without PLC host requirement; BASIC programming realizes flexible custom motion logic; supports electronic cam curve operation and multi‑axis virtual synchronization; hardware registration input completes high‑speed position capture task; built‑in local digital I/O processes sensor and actuator signal directly; differential encoder interface resists industrial field electromagnetic interference; multi‑task function runs multiple independent motion programs simultaneously; Host Link interface connects to configuration software and HMI operator terminals.
Application Scenarios: Packaging machinery cam motion control; material processing equipment single‑axis positioning system; winding and unwinding tension auxiliary motion control; labeling machine position trigger control; Sigma‑II servo system transformation and legacy equipment spare‑part replacement.
Performance Parameters: Differential encoder circuit effectively suppresses industrial‑field common‑mode noise; motion control loop maintains stable response under rated working conditions; vibration‑resistance and shock‑resistance comply with IEC cabinet‑mount component standards; supports continuous 24‑hour stable operation inside industrial control cabinets.
Material Composition: Light‑gray V0 flame‑retardant engineering‑plastic housing; internal FR‑4 multilayer glass‑fiber printed‑circuit board; motion‑control main‑processing chip; differential signal transceiver chips; green spring‑type pluggable terminal blocks; high‑brightness multi‑color LED RUN and STATUS indicators; metal spring‑loaded DIN‑rail mounting buckle.
Structural Features: Narrow‑body DIN‑rail module profile; rear‑side integrated spring‑type DIN‑rail buckle for fast cabinet installation; front‑panel layout of spring‑type I/O terminal block, communication port and multi‑group LED status indicators; compact overall structure without extra fan cooling requirement.
Working Principle: User BASIC motion program downloads and stores into R88A‑MCW151‑E internal flash memory. After power‑on, internal motion kernel runs program in multi‑task mode, calculates position and speed reference value. Speed reference command transmits to matched Sigma‑II servo drive. Encoder feedback signal returns to motion unit through differential interface for closed‑loop position calculation. Built‑in local digital I/O collects external sensor signals and outputs driving signals to on‑site actuators. Internal circuit monitors running state continuously and drives LED indicators to display working status and fault information.
Installation Requirements: Secure R88A‑MCW151‑E onto standard cabinet DIN rail; reserve adequate ventilation clearance around module housing; use shielded twisted‑pair cables for encoder signal wiring; separate motion signal cables from high‑power motor and inverter power cables; apply stable DC24 V external power supply; implement reliable protective grounding for control cabinet.
Usage Notes: This unit only supports Sigma‑II series servo drives, cannot match Sigma‑I series hardware; confirm DC24 V power supply voltage stays within allowable tolerance range; hot‑plugging of encoder and I/O cables under powered‑on running state is forbidden; do not deploy in environments with condensation or corrosive gas; regularly inspect spring‑type terminal block insertion condition.