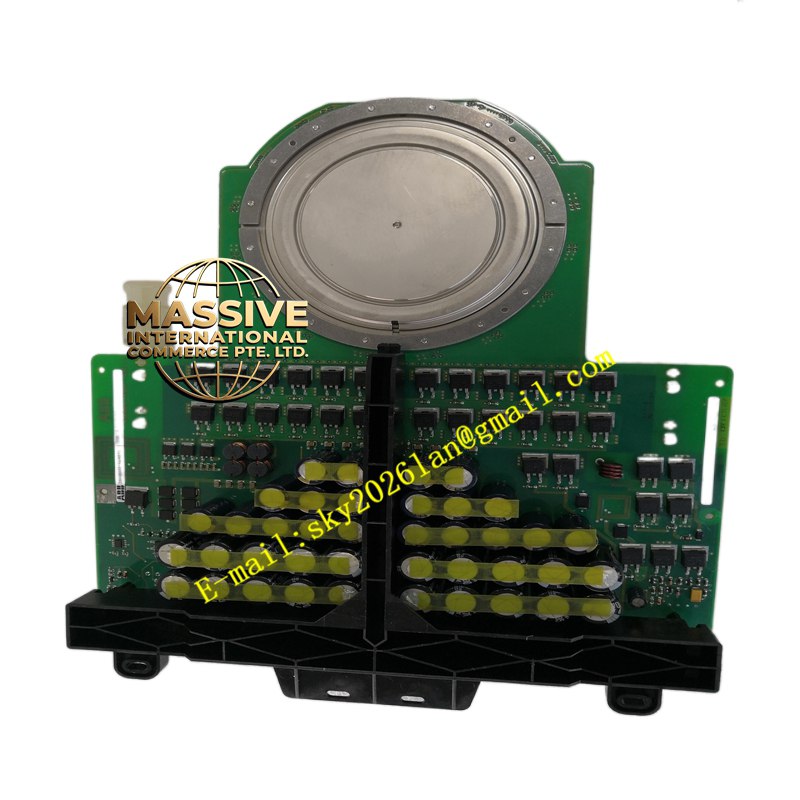
Description
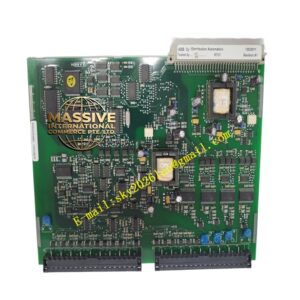
ABB 3HAC031851-001
Technical Specifications:
- Brand: ABB
- Model Number: 3HAC031851-001
- Product Type: Serial Measurement Board (SMB)
- System Compatibility: ABB IRC5 Robot Controllers
Functional Features:
- Encoder Signal Processing: Accurately processes high-resolution feedback signals from motor encoders to determine exact axis positioning.
- Battery Backup Management: Maintains the robot’s master counter (origin position) during power-off states to prevent data loss.
- Reliable Communication: Ensures stable, noise-free serial data transmission between the drive modules and the robot axes.
Application Scenarios:
- Installed directly on or near the servo motors within the robot manipulator base.
- Replaced during maintenance when the robot experiences encoder communication faults or master counter loss.
Performance Parameters:
- Data Accuracy: Zero-latency processing of position feedback for high-precision robotic movements.
- Retention Reliability: Seamless switching to battery power to guarantee non-volatile memory retention.
Material Composition & Structural Features:
- PCB Assembly: Multi-layer printed circuit board with protective conformal coating against industrial dust and moisture.
- Robust Connectors: Vibration-resistant connectors designed to withstand the mechanical stress of continuous robotic motion.
Working Principle:
The board continuously reads raw pulse signals from the motor encoders, converts them into digital serial data, and transmits this information to the IRC5 controller. It also monitors the backup battery voltage and automatically switches to battery power when the main system power is disconnected.
Installation Requirements:
- Mount securely in the designated location on the robot axis.
- Ensure all motor encoder and battery cables are firmly seated and properly routed to avoid pinch points.
Usage Precautions:
- Always install a fresh, high-quality backup battery before powering on a newly installed SMB.
- Replacing this board will require a complete master calibration (updating the master counters) to restore absolute positioning accuracy.