



Description
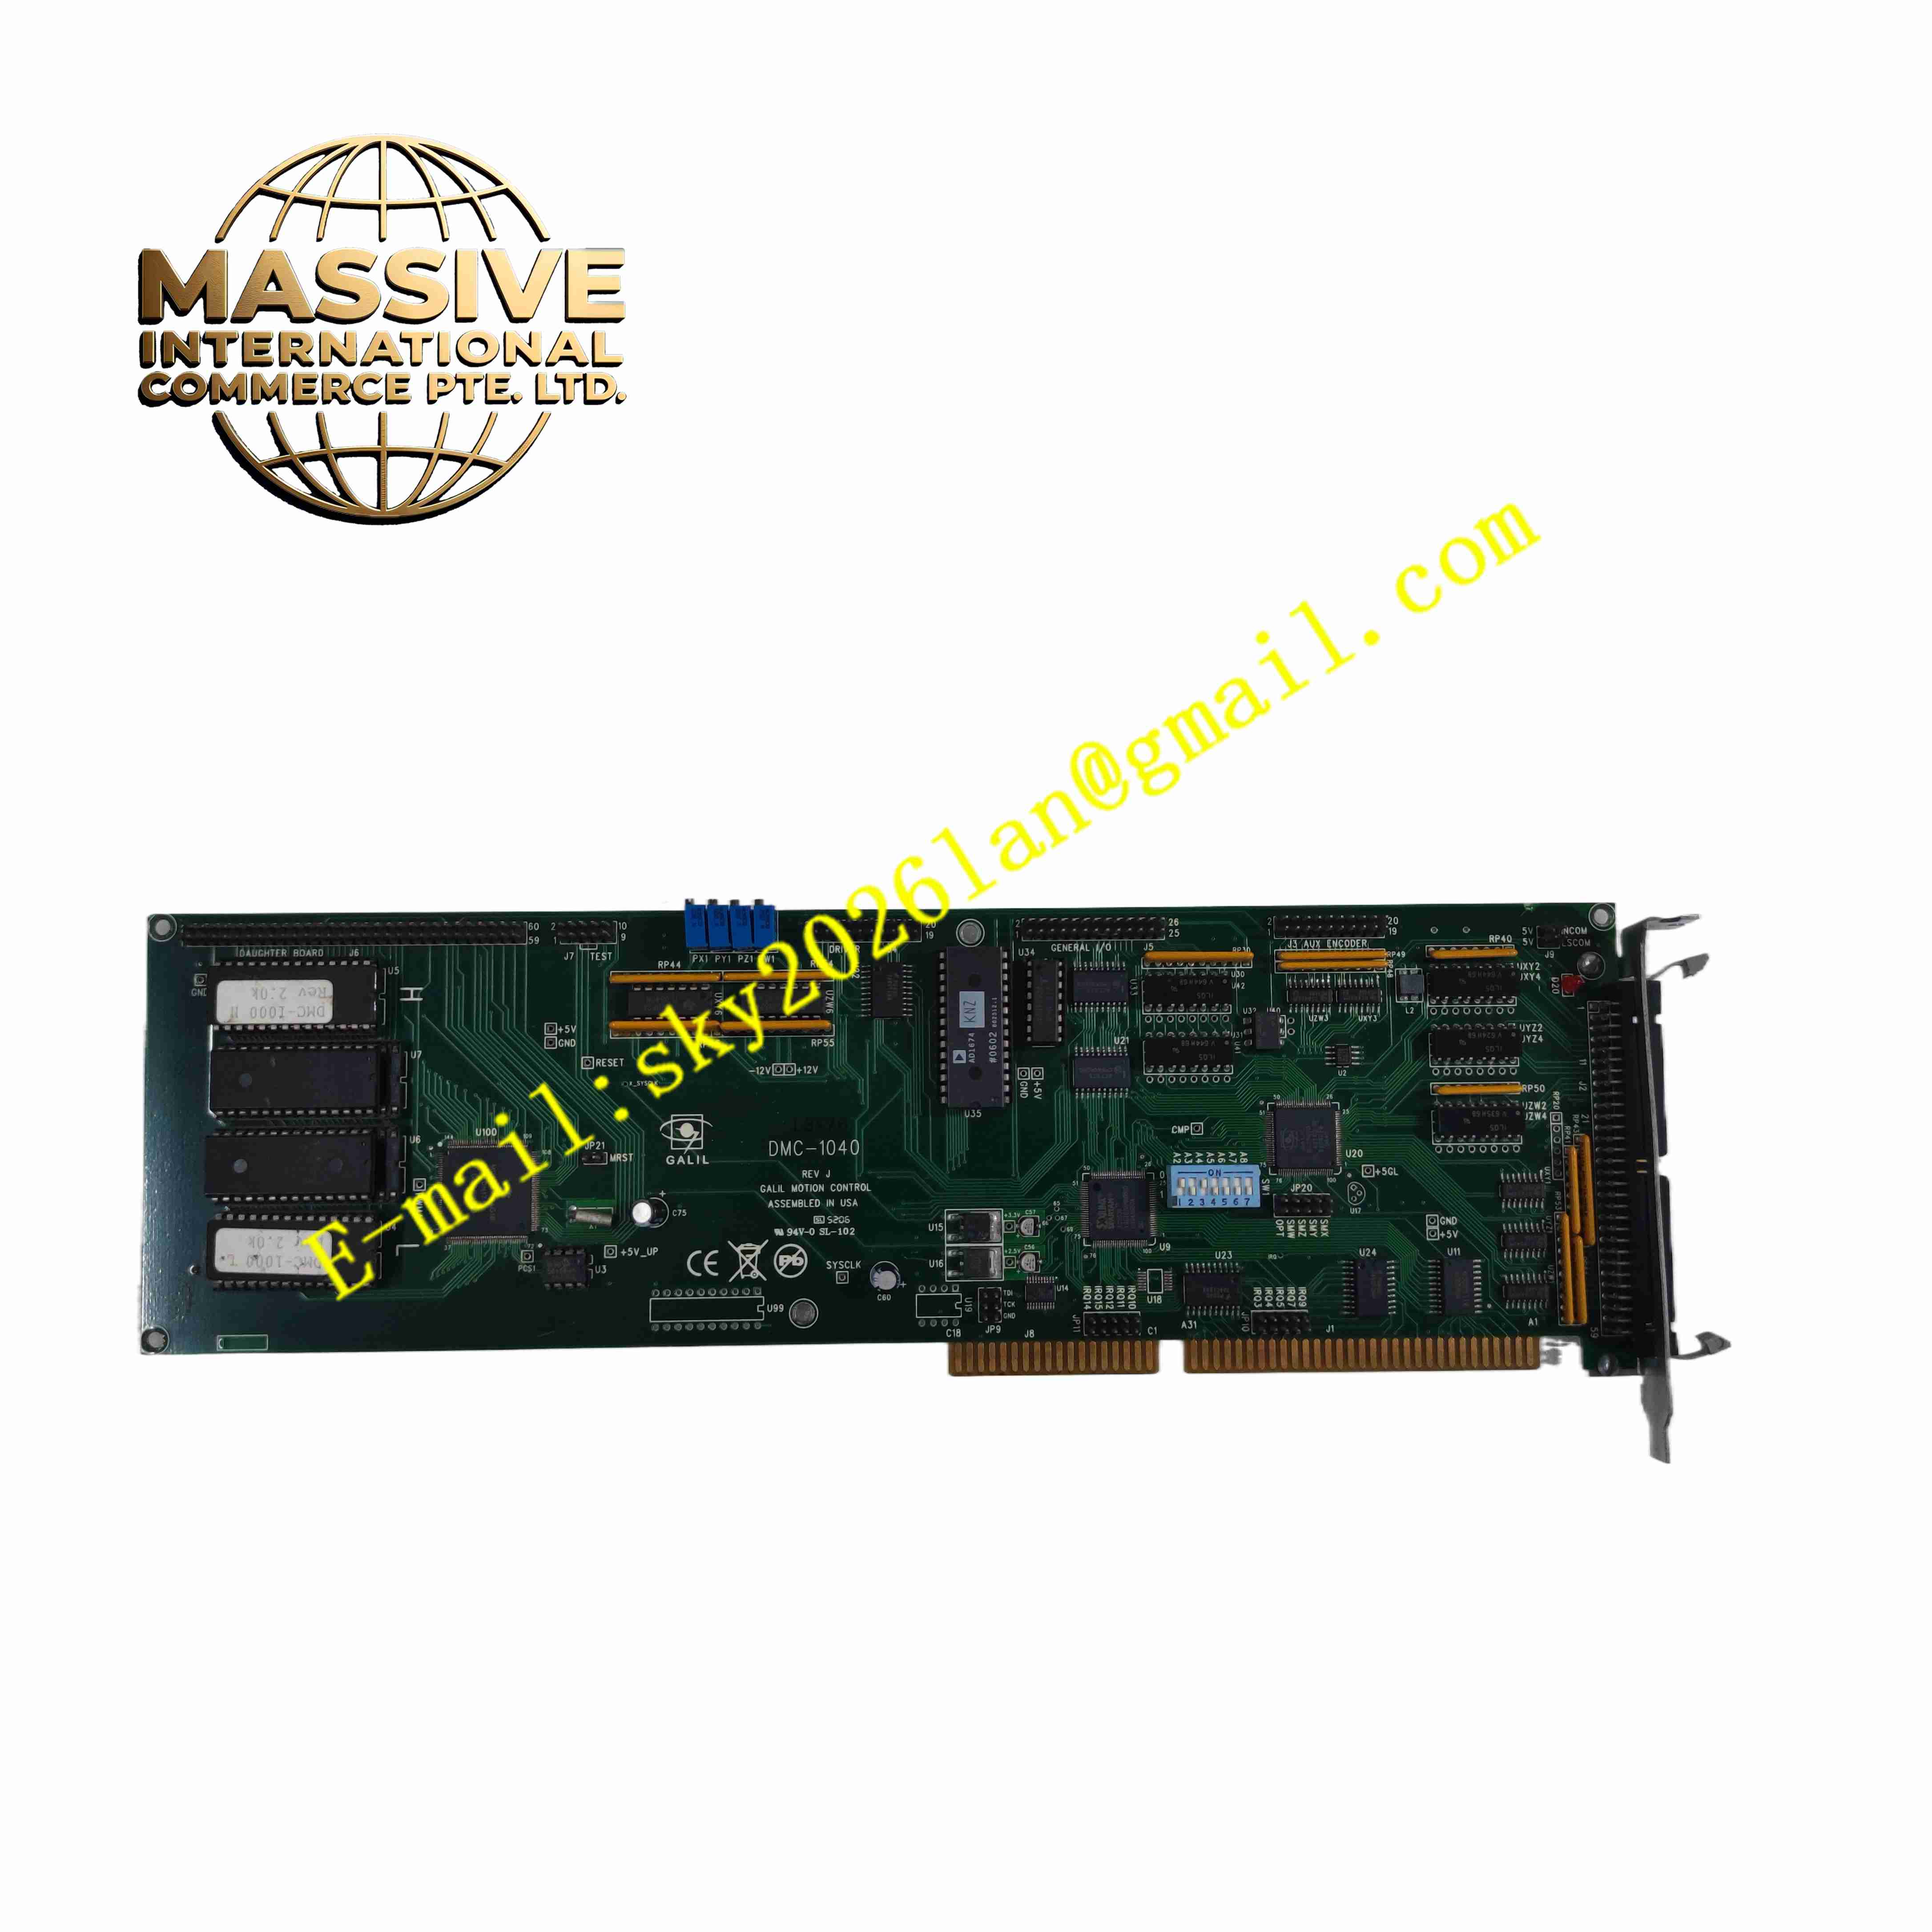
Galil DMC-1040
Technical Specifications:
- Axis Quantity: 4 axes
- Control Loop Update Rate: 62μs for 1-2 axes, 125μs for 3-4 axes
- Supported Motor: Brush servo, brushless servo and stepper motors
- Encoder Interface: Quadrature encoder input
- Digital Input: 8 opto-isolated digital inputs
- Digital Output: 8 opto-isolated digital outputs, 500mA sourcing
- Power Supply: 20V to 80V DC
- Communication: Ethernet and RS232 serial port
- Operating Temperature: -20°C ~ +65°C
- Storage Temperature: -40°C ~ +85°C
- Protection Grade: IP20
Function Features:
- Point-to-point positioning, linear interpolation, circular interpolation
- Electronic cam, gantry synchronization and contour motion control
- Built-in PID servo algorithm with feedforward gain adjustment
- Limit switch, home switch and emergency stop input processing
- Onboard program storage for standalone execution
- Digital I/O control for external sensor and actuator
- Built-in fault detection and axis status reporting
- Support Galil GDK software for configuration, tuning and programming
Application Scenarios:
- PCB routing and drilling machines
- Laser cutting and marking equipment
- Automated dispensing systems
- Pick and place assembly machines
- Precision positioning test equipment
Material Composition:
- Housing: Cold rolled steel sheet metal enclosure with black coating
- PCB: Multilayer FR4 fiberglass printed circuit board
- Control Core: High speed DSP motion processor
- Interface Chips: Optocoupler isolation chips, encoder receivers
- Terminals: Screw type copper alloy terminals
Structural Features:
- Panel mount metal enclosure
- Front panel LED indicators for power, communication and axis status
- Separate terminal blocks for power, motor command, encoder and digital I/O
- Compact footprint for cabinet installation
Working Principle: User downloads motion program into onboard memory via Ethernet or RS232. Controller executes motion sequence and generates command signal to external servo amplifiers. Encoders feed back motor position signal. DSP runs PID algorithm to calculate position error and adjust output command. Digital I/O channels handle sensor signals and trigger external actuators according to motion sequence.
Installation Requirements:
- Install inside electrical control cabinet
- Keep sufficient ventilation space around controller
- Use shielded cable for encoder and command signal wiring
- Separate low voltage signal wiring from high power cables
- Complete reliable protective grounding
Usage Notes:
- Set encoder resolution and motor parameters before commissioning
- Tune PID and feedforward parameters for each axis
- Backup motion program before firmware update
- Do not exceed 80V DC maximum power supply voltage
- Disconnect power before wiring modification







