



Description
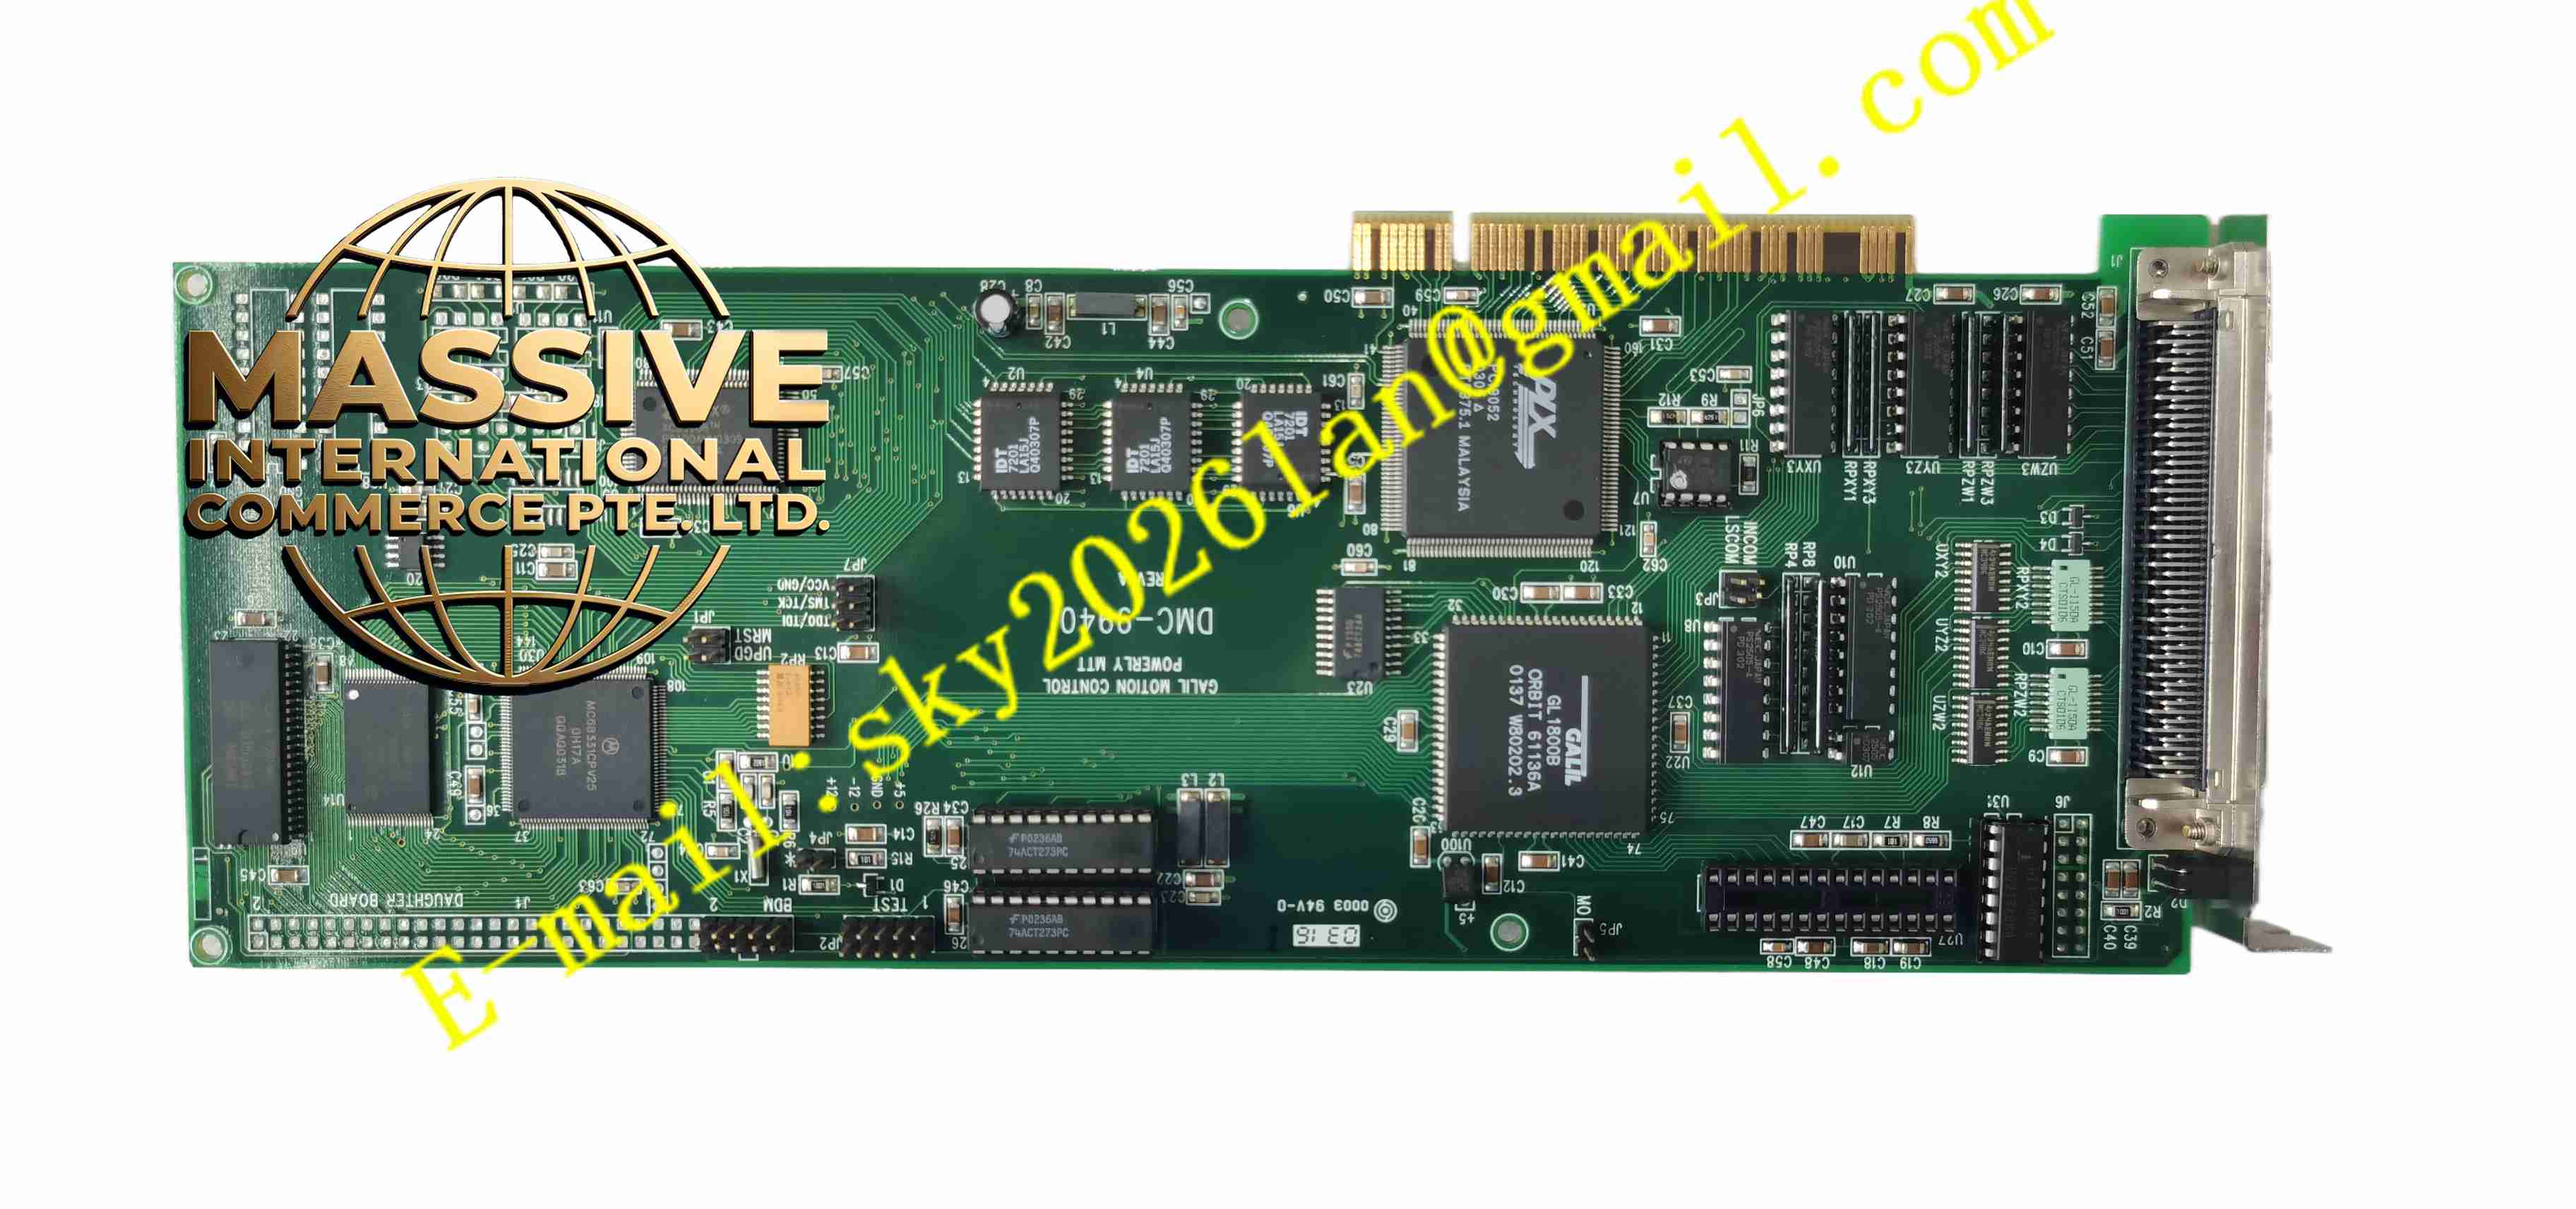
Galil DMC-9940
Technical Specifications:
- Maximum Controlled Axes: 6 axes
- Control Loop Update Rate: 100μs
- Position Resolution: 17 bits per axis
- Velocity Range: 0.01Hz to 30000Hz
- Communication Interfaces: Ethernet, RS232, RS485
- Power Supply: 12V to 24V DC
- Operating Temperature: -40°C ~ +85°C
- Storage Temperature: -40°C ~ +85°C
- Protection Grade: IP20
Function Features:
- Point-to-point positioning, linear and circular interpolation
- Electronic cam, master-slave synchronization and gantry control
- PID closed-loop control with feedforward adjustment
- Hardware limit, home and emergency stop handling
- Onboard program storage for standalone operation
- Digital input and output for sensor and actuator control
- Built-in fault diagnosis and axis status monitoring
- Support host computer communication for remote monitoring
Application Scenarios:
- Heavy duty industrial automation machinery
- Mobile and off-road automation equipment
- Environmental test equipment
- Custom multi-axis test systems
- Harsh factory floor automation applications
Material Composition:
- Housing: Reinforced aluminum alloy metal casing
- PCB: Multilayer FR4 fiberglass circuit board with conformal coating
- Control Core: Industrial grade DSP motion processor
- Interface Chips: Optocoupler isolation chips, differential receivers
- Terminals: Screw type copper alloy terminals
Structural Features:
- Compact panel mount metal enclosure
- Front panel LED indicators for power, communication and fault status
- Separated terminal blocks for power, axis command, encoder and digital I/O
- Vibration resistant internal component soldering
Working Principle: The controller executes stored motion program and generates motion profiles for each axis. Command signals transmit to external servo drives. Encoders feed back real-time motor position. DSP runs high speed PID algorithm to reduce position error. Digital I/O channels collect field sensor signals and trigger motion events. Communication ports enable connection to upper monitoring system.
Installation Requirements:
- Install inside protected electrical cabinet
- Avoid direct exposure to dust, moisture and vibration sources
- Use shielded cables for encoder and command signal wiring
- Separate low voltage signal wiring from high power cables
- Complete reliable protective grounding
Usage Notes:
- Confirm power supply voltage within 12-24V DC range
- Set encoder resolution and motor parameters before startup
- Tune PID parameters for each axis according to mechanical load
- Backup motion program and parameters
- Disconnect power before wiring modification







