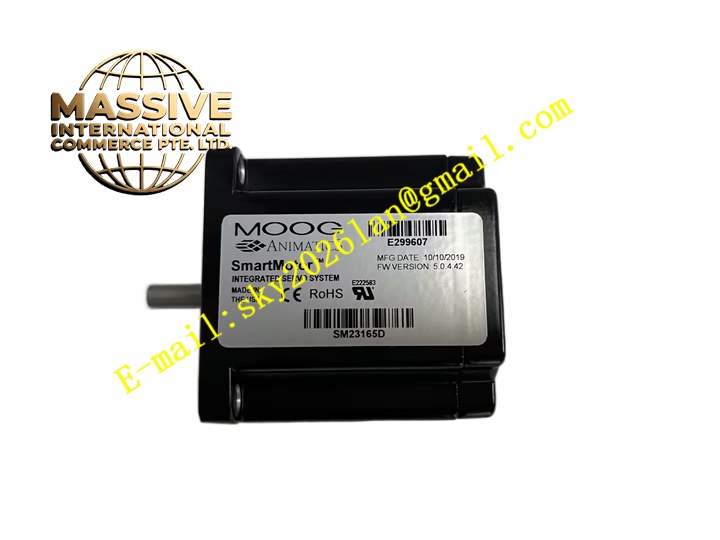
Description
MOOG SM23165D
Technical Specifications Brand: Moog Model: SM23165D Motor Type: Brushless permanent magnet synchronous servo motor Feedback: Integrated incremental optical encoder Mounting Style: Flange mount Operating Temperature: -40°C to +85°C Protection Grade: IP54 Insulation Class: High temperature winding insulation
Functional Features High torque density compact rotor construction. Low rotor inertia supports ultra-fast acceleration and deceleration cycles. High resolution incremental encoder supplies real-time position and speed feedback. High bandwidth response for dynamic simulation and test loading applications. Robust sealed housing protects internal components from dust and moisture. Low torque ripple for stable motion control during precision positioning.
Application Scenarios Flight simulation motion platforms, structural fatigue test equipment, automotive component test benches, precision motion simulators, high dynamic industrial positioning systems.
Performance Parameters High peak torque capability for short-duration dynamic load requirements. Low mechanical backlash in internal bearing assembly. Consistent encoder signal output under continuous vibration. High thermal endurance under repeated cyclic loading. Fast tracking of rapidly changing motion command profiles.
Material Composition Motor Housing: Machined aluminum alloy. Rotor: Silicon steel laminations bonded with rare-earth permanent magnets. Stator: Copper magnet wire wound on silicon steel stator core. Output Shaft: Hardened alloy steel. Encoder Unit: Optical encoder chip inside reinforced sealed housing. Bearings: High precision sealed ball bearings.
Structural Features Flange-mounted cylindrical motor body. Front precision bearing assembly supports the output shaft. Rear housing encapsulates the optical incremental encoder. Two independent electrical connectors for motor power and encoder feedback wiring. Internal insulation isolates stator windings from metal motor housing.
Working Principle Three-phase variable frequency current from servo amplifier excites stator windings to produce rotating magnetic field. Magnetic field interacts with rotor permanent magnets to produce electromagnetic torque to rotate the motor shaft. The optical incremental encoder converts shaft mechanical rotation into digital pulse signals and feeds back to servo controller. The closed-loop control algorithm adjusts motor current continuously to eliminate position and speed error between command and actual measured motion.
Installation Requirements Mount motor flange onto rigid, vibration-damped base structure. Select suitable flexible coupling to connect shaft and mechanical load. Use shielded cables for motor power and encoder feedback wiring. Separate signal cables from high-current power cables. Secure cable strain relief to prevent connector damage under vibration. Check encoder wiring phase definition before power on.
Usage Notes Do not exceed rated peak torque and continuous operating torque. Avoid mechanical shock impact to encoder rear cover. Keep motor housing and encoder assembly away from liquid contamination. Monitor winding temperature during high dynamic cyclic test operation. Perform periodic inspection of bearing noise and encoder signal quality.