



Description
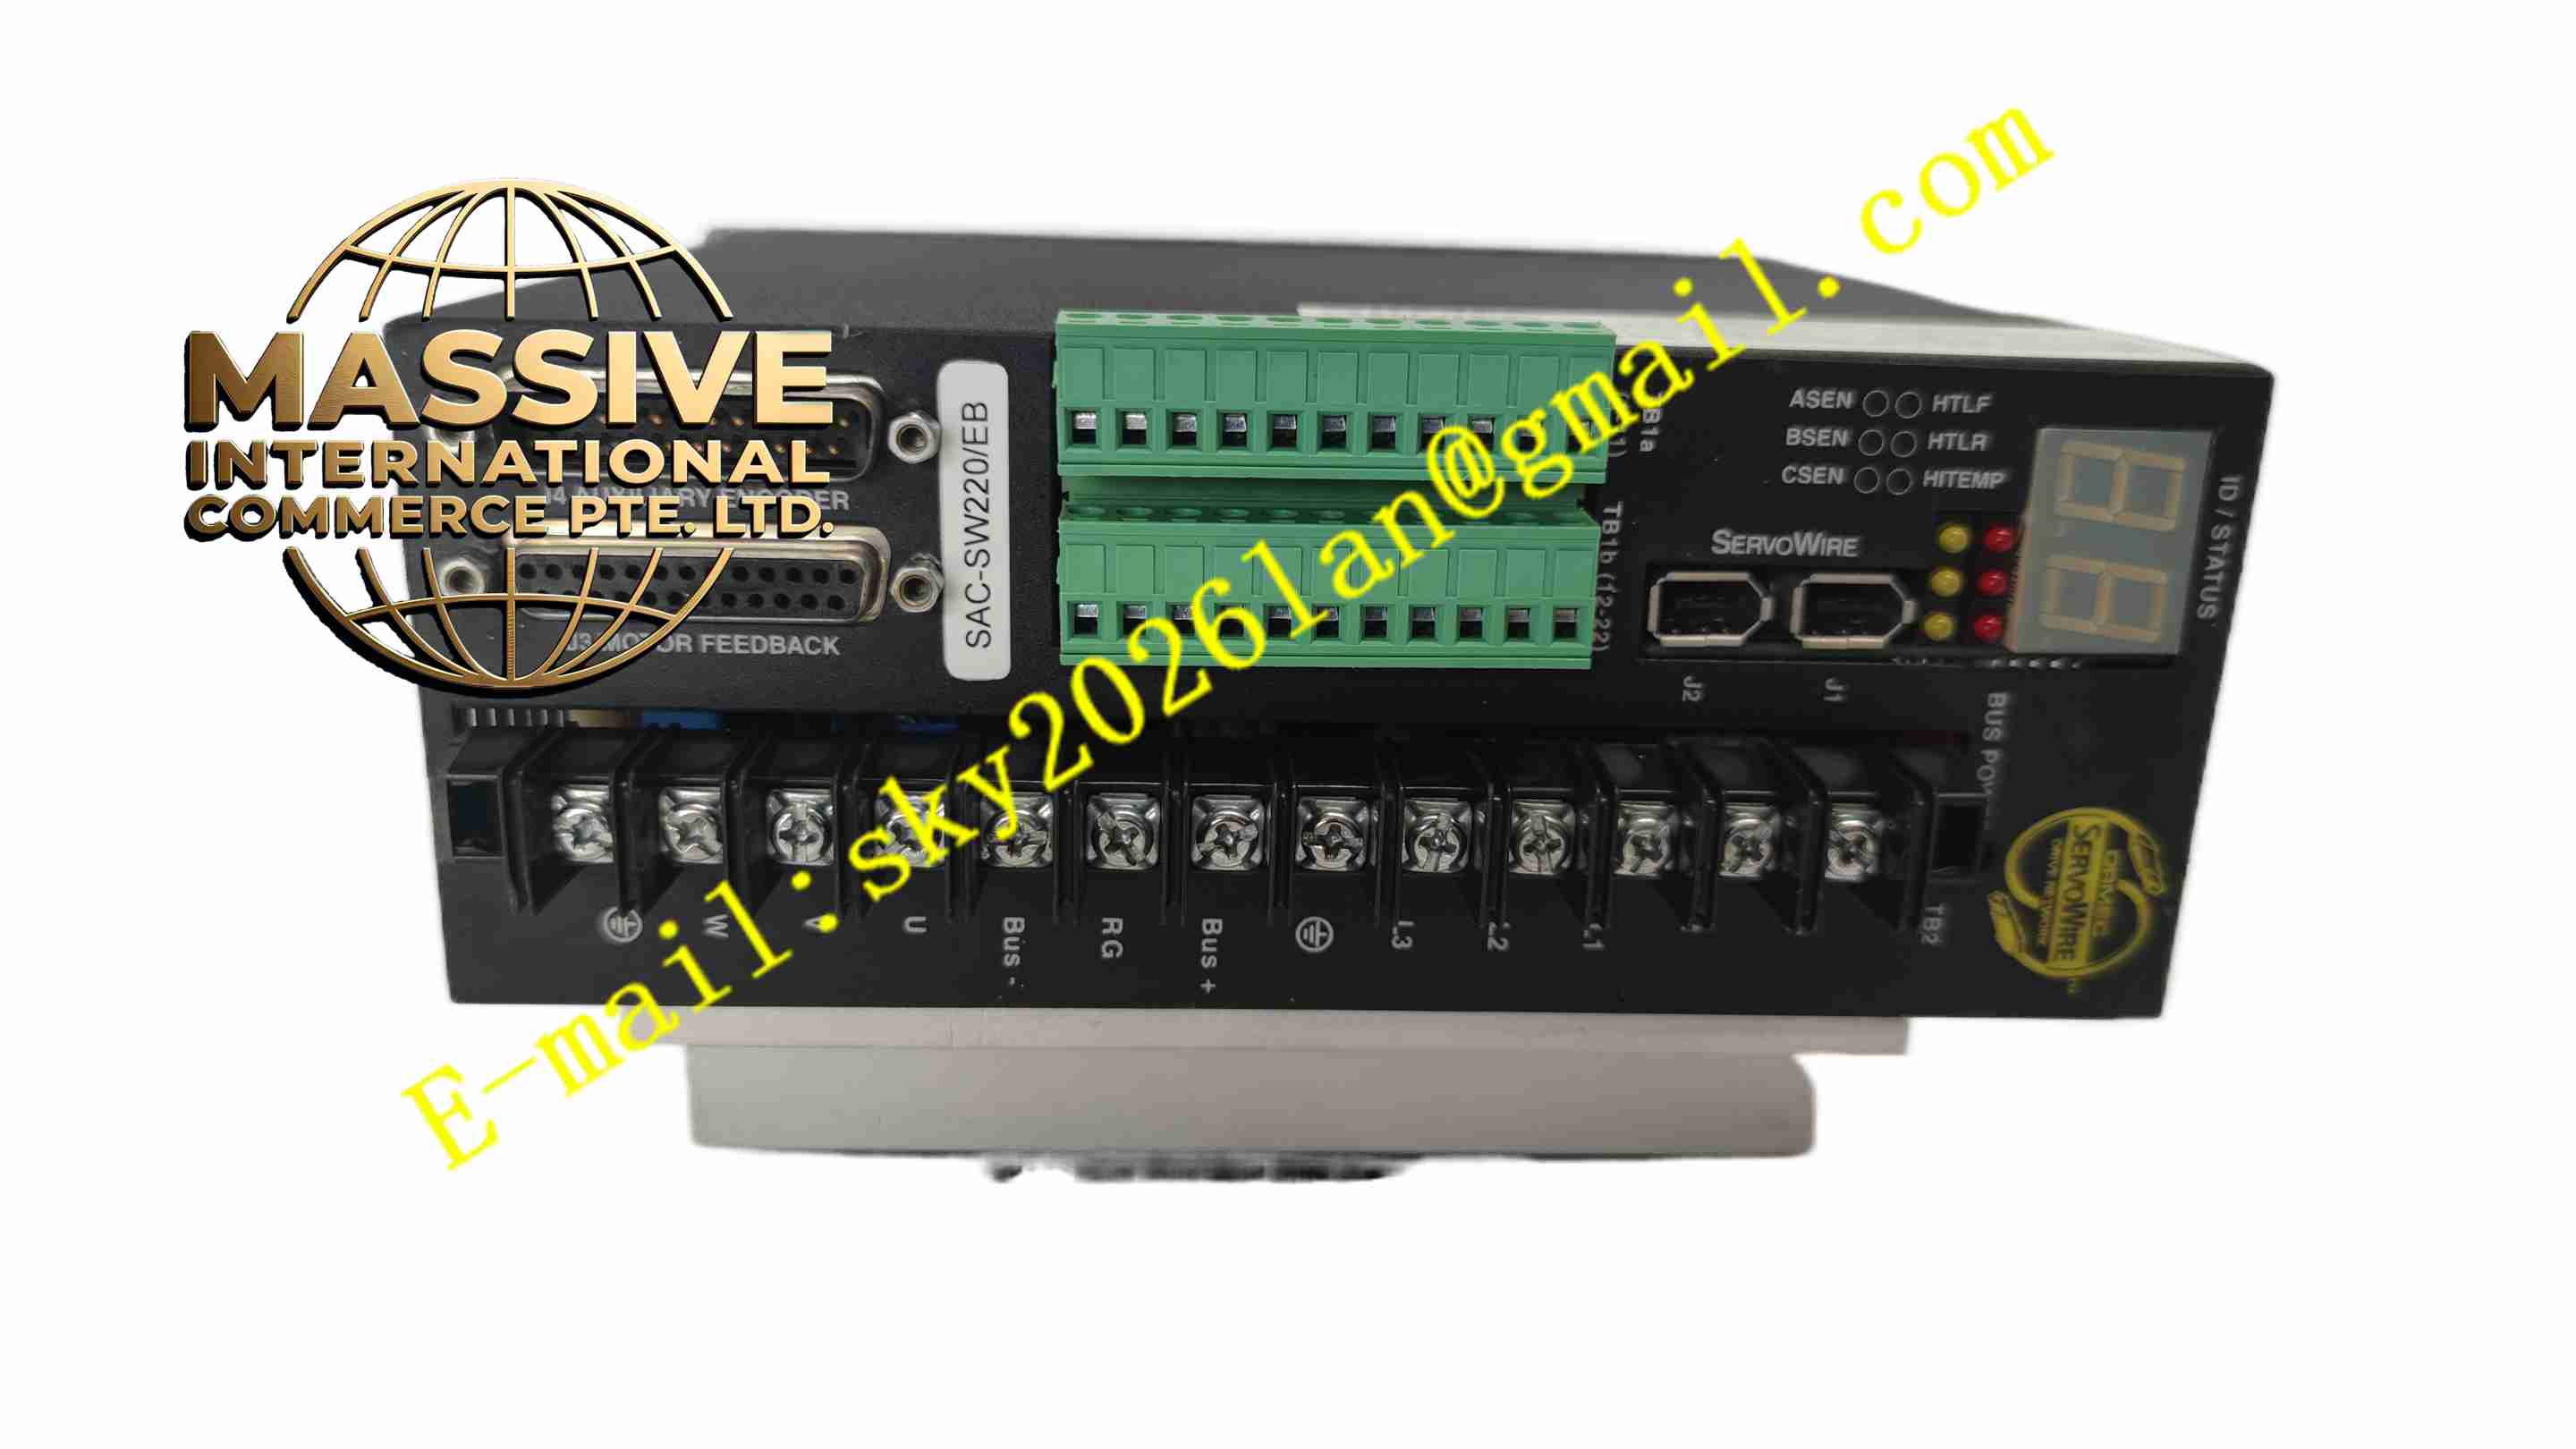
ORMEC SAC-SW220EB
Technical Specifications Brand: ORMEC Model: SAC-SW220EB Rated Output Power: 220 W Input Voltage: 200 VAC to 480 VAC Control Algorithm: Field oriented vector control Communication Interfaces: RS485, EtherCAT Operating Temperature: -10°C to +40°C Protection Grade: IP65 Weight: 1.5 kg Dimensions: 150 mm × 100 mm × 50 mm
Functional Features Three closed-loop control modes: torque, speed and position. Field oriented vector control provides smooth low speed torque output. EtherCAT real-time bus for high speed synchronized multi-axis motion. RS485 interface for parameter configuration and host communication. Built-in overvoltage, undervoltage, overcurrent, overtemperature and motor stall protection. Parameter setup via PC configuration software. Compact form factor saves machine installation space.
Application Scenarios Automated assembly equipment, packaging machinery, material handling mechanism, medical automation equipment, small pick and place robot axis, electronic component processing machine.
Performance Parameters Smooth torque output at low rotational speed. Fast response to position and speed command change. Built-in protection circuits activate immediately on fault conditions. EtherCAT bus supports high speed real-time synchronization. Stable continuous operation in workshop environment.
Material Composition Housing: Die cast aluminum alloy enclosure with anti-corrosion coating. PCB: FR4 multilayer control and power printed circuit board. Core Components: IGBT power module, motion control DSP, opto-isolation chips, EMC suppression components. Connector: Industrial circular connector for motor, encoder and power wiring.
Structural Features Sealed compact aluminum housing. External industrial connectors for all wiring, eliminating exposed terminal blocks. Internal metal shielding separates power circuit and low level signal circuit. Heat conductive structure transfers power device heat to aluminum housing.
Working Principle AC input power rectifies to DC bus voltage. DSP receives motion command over EtherCAT or RS485 interface. Vector control algorithm calculates three phase current reference. IGBT power stage outputs PWM modulated current to servo motor. Motor encoder feeds back rotor position and speed signal to close control loop. Internal monitoring circuit tracks voltage, current and temperature and triggers fault protection once parameters exceed rated range.
Installation Requirements Mount drive on rigid machine surface, maintain contact for heat conduction. Use shielded motor cable and shielded encoder cable. Route power cables separately from signal cables. Set motor parameters and perform servo tuning after wiring completion. Verify EtherCAT network topology and address configuration.
Usage Notes Do not operate drive outside 200-480 VAC input range. Keep connector sealing gasket intact to maintain IP65 rating. Check encoder wiring before power on. Prevent mechanical overload which triggers stall protection. Use ORMEC official software for parameter backup before modification.







