Description
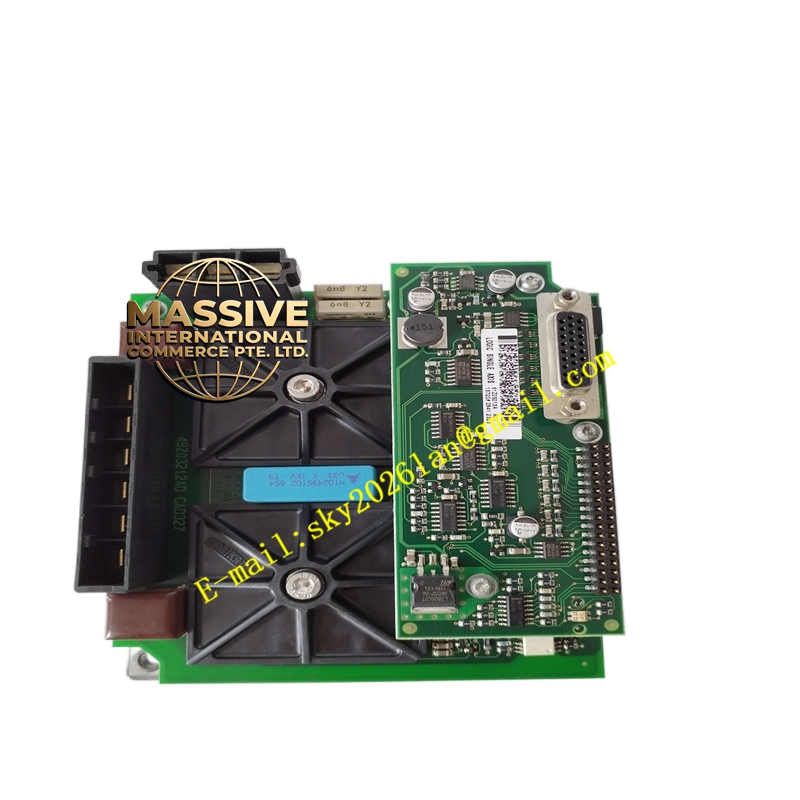
ABB 3HAC14550-408A
Technical Specifications:
- Rated Power: 400W
- Rated Torque: 1.8 Nm
- Rated Speed: 3000 rpm
- Input Voltage: AC 200–240V or DC 24V to 55V (depending on configuration)
- Continuous Current: 8A
- Peak Current: 16A
- Control Modes: Position control, speed control, torque control
- Communication Interfaces: RS-232, RS-485, Modbus, CANopen, EtherCAT
- Transmission Rate: 100 Mbps (EtherCAT)
- Interface Type: RJ45 (EtherCAT), standard serial connectors
- Dimensions: 150mm × 75mm × 40mm
- Weight: 1.2kg to 2kg
- Operating Temperature: -20°C to +60°C
- Protection Rating: IP20
- Material: Aluminum alloy housing
- Mounting: DIN rail or panel mounting
Functional Features:
- High-Precision Control: Advanced control algorithms deliver precise position, speed, and torque control for robot joint movements
- High Dynamic Performance: Fast dynamic response capability enables rapid command following and smooth motion control
- Multiple Control Modes: Supports position control, speed control, and torque control to meet diverse application requirements
- Rich Communication Interfaces: Supports RS-232, RS-485, Modbus, CANopen, and EtherCAT protocols for seamless system integration
- Compact Design: Space-efficient aluminum alloy housing suitable for DIN rail or panel installation
- High Reliability: Industrial-grade design with quality components for continuous operation in demanding environments
- Compatibility: Excellent compatibility with ABB robots and automation systems for easy integration
Application Scenarios:
- Industrial robot joint control
- Precision machining equipment in mechanical manufacturing
- Packaging machinery in food processing
- Automated assembly lines in electronics manufacturing
- Conveyor and sorting systems in logistics
- Surgical robots and precision medical equipment
- Textile machinery control
Working Principle: The servo drive unit receives command signals from the robot controller and converts them into precise electrical signals to drive servo motors. It employs closed-loop feedback control, continuously comparing actual position/speed with commanded values and adjusting output to minimize deviation. The drive manages power delivery, monitors motor status, and provides diagnostic feedback to ensure accurate and safe robot motion.
Material Composition:
- Aluminum alloy housing for excellent heat dissipation and durability
- High-grade electronic components for signal processing
- Power semiconductor devices for motor drive
- Optical isolation components for signal protection
Installation Requirements:
- Install in well-ventilated enclosure to ensure adequate heat dissipation
- Mount securely on DIN rail or panel with proper grounding
- Connect motor cables, encoder feedback, and communication lines according to specifications
- Verify voltage compatibility before power-on
Usage Precautions:
- Ensure proper grounding to prevent electrical interference
- Monitor operating temperature to prevent overheating
- Perform regular maintenance checks on connections and cooling
- Follow ABB robot system integration guidelines
- Do not exceed rated current or voltage specifications
- Allow adequate cooling time after continuous high-load operation