



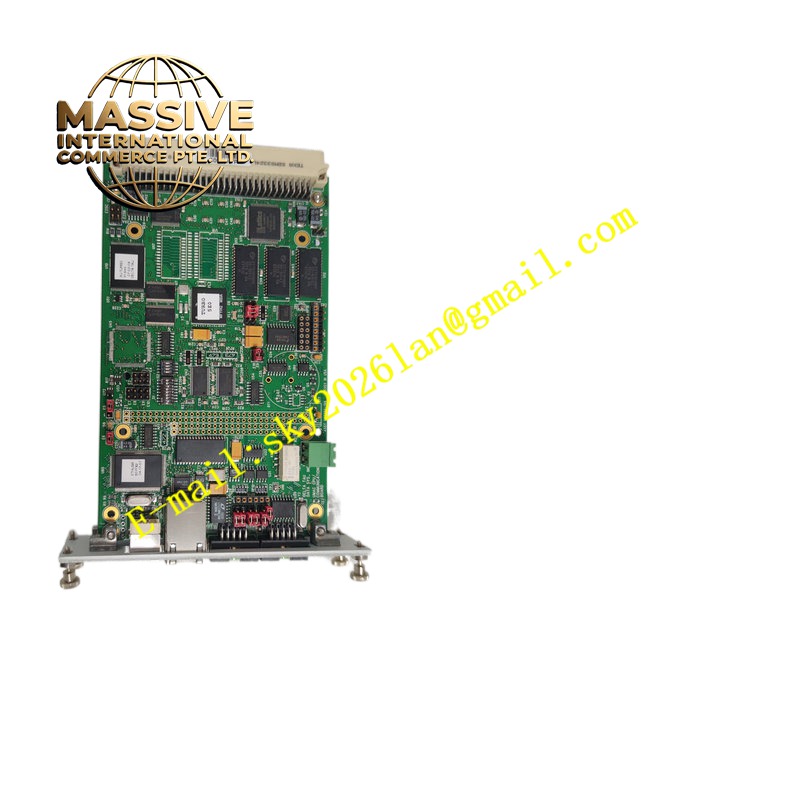
Description
Bosch Rexroth CML40.2-SP-330-NA-NNNN-NW
Technical Specifications 32-bit RISC main processor; program memory 64 MB RAM, 128 MB CompactFlash removable storage; supply voltage 19.2 VDC to 30 VDC, nominal 24 VDC; weight 1.004 kg; operating temperature range -20 ℃ to +60 ℃; communication interfaces include Sercos real-time bus, Ethernet, RS485; supported protocols contain Sercos, Modbus TCP, Modbus RTU, OPC UA; modular I/O expansion via Rexroth Inline terminal modules; protection rating IP20 for cabinet installation.
Functional Features Integrated sequential logic, safety logic and multi-axis motion functions such as electronic gearing, electronic cam and synchronization; real-time Sercos bus communication with IndraDrive servo drives; local parameter storage for axis tuning and machine recipes; diagnostic data recording for drive and controller fault analysis; program development compliant with IEC 61131-3 standard; optional SafeLogic safety expansion modules.
Application Scenarios CNC machine tool auxiliary axes control, printing press register synchronization, packaging machine multi-axis handling systems, material forming and cutting automation lines.
Material Composition Metal alloy shielding housing; high-speed multilayer control PCB; industrial-grade RISC processor and FPGA; gold-plated bus and I/O connectors; CompactFlash socket with mechanical retention latch.
Structural Characteristics DIN rail mount compact controller unit; front panel with status LEDs and service diagnostic port; side terminal blocks for 24V power and digital I/O; rear bus connector for Sercos and fieldbus connection; internal isolated power supply section.
Working Principle After power-up, the controller loads user IEC 61131-3 program from CompactFlash memory. It receives motion setpoints and logic commands, communicates position demand values to servo drives over Sercos bus, reads encoder feedback signals, executes position, speed and torque cascade loops, and drives digital outputs for machine actuators. Fault and diagnostic information is logged in internal memory.
Installation Requirements Mount on DIN rail inside protected electrical cabinet; separate servo power cables from control and communication cables; use shielded Sercos bus cables respecting minimum bending radius; configure safety circuit wiring before drive enable operation.
Operation Notes Back up machine project and axis parameter set before firmware update; download complete project after controller replacement; verify Sercos node address and bus topology after hardware swap.







