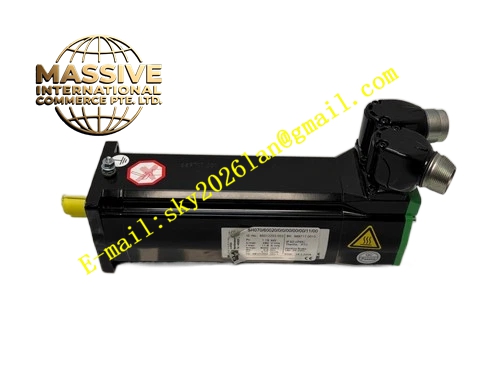
Description
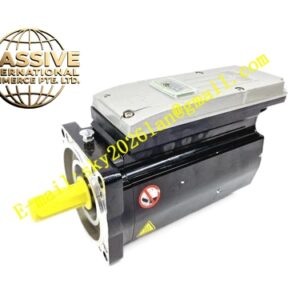
ELAU SH30703P02A2000
Technical Specifications: Rated supply‑voltage 400 VAC, flange dimension 70 mm, continuous stall torque 3.1 Nm, peak torque 9.3 Nm, rated speed 4500 rpm, multi‑turn Hiperface absolute encoder, shaft diameter 16 mm, insulation class F, IP65 protection rating for shaft‑end and housing.
Functional Features: Ultra‑low‑inertia rotor‑structure for high‑acceleration dynamic‑response, multi‑turn absolute encoder preserves full‑position data after power‑loss, rotatable circular power‑and‑feedback connectors, built‑in stator‑winding thermal‑protection sensor, high short‑time overload capacity, seamless compatibility with PacDrive3 servo‑drives.
Application Scenarios: High‑speed packaging auxiliary‑axes, electronic‑product‑assembly equipment, small‑sized robotic‑joint axes, printing‑converting auxiliary‑motion‑axes, textile‑machinery high‑speed positioning‑axes.
Performance Parameters: Rotor inertia 4.2 kg·cm², torque‑ripple less than 2.0 %, multi‑turn encoder measuring‑range 4096 revolutions, operating‑ambient‑temperature range ‑20 °C ~ +40 °C.
Material Composition: Die‑cast aluminum‑alloy motor housing, laminated silicon‑steel stator‑core, high‑energy neodymium‑iron‑boron permanent‑magnet rotor, alloy‑steel output‑shaft, glass‑fiber‑reinforced plastic‑connector housings.
Structural Characteristics: Fully‑enclosed fin‑cooled compact housing, flange‑mount installation‑structure, side‑mount rotatable M23‑type circular‑connectors, PT100 thermal‑sensor embedded inside stator‑windings, non‑holding‑brake variant, key‑way‑equipped output‑shaft.
Working Principle: Three‑phase sinusoidal‑current flows into stator‑windings to generate rotating‑magnetic‑field and drive permanent‑magnet rotor‑rotation. Multi‑turn Hiperface encoder collects absolute‑position and velocity‑data and transmits feedback‑signal to matched servo‑drive. Servo‑drive implements cascade closed‑loop control of current, speed and position to complete high‑precision motion‑output.
Installation Requirements: Fasten motor‑flange to machine‑mounting‑surface with specified‑torque bolts; keep coupling‑coaxial‑alignment tolerance ≤ 0.05 mm; reserve adequate surrounding‑space for natural‑convection heat‑dissipation; lock connector‑locking‑rings against vibration‑loosening; separate power‑cable and feedback‑cable routing‑paths.
Usage Notes: Avoid mechanical‑shock impact to motor‑output‑shaft; verify servo‑drive encoder‑type configuration matches motor hardware; forbid long‑duration continuous‑operation under peak‑torque condition; protect shaft‑lip‑seal from oil‑mist and chemical‑solvent erosion; apply ESD‑protection measures when handling encoder‑circuit‑related wiring.