



Description
Elmo G-TUB30480FEHSNA2 (1080-01355)
Technical Specifications:
- Rated Output Power: 30 kW
- Input Voltage: Three-phase 400 VAC to 480 VAC ±10%
- Continuous Output Current: 30 A
- Peak Output Current: 60 A
- Control Modes: Position control, velocity control, torque control
- Communication Interfaces: EtherCAT, CANopen, RS232
- STO Safety Function: Safe Torque Off, SIL3 capable
- Efficiency: ≥98%
- Operating Temperature: 0 °C to +40 °C
- Storage Temperature: -40 °C to +85 °C
- Protection Functions: Overvoltage, undervoltage, overcurrent, overtemperature, short circuit, motor overload
- Mounting: Cabinet wall mount
- Weight: 6.8 kg
- Certification: UL, CE, IEC 61800-5-2
Function Features:
- High power density design reduces cabinet space occupation for high-power motion axes
- Deterministic EtherCAT communication for multi-axis synchronous motion control
- Built-in STO safety channel cuts off motor torque immediately upon safety interlock trigger
- High bandwidth current loop for fast dynamic response during acceleration and deceleration
- Onboard motor feedback interfaces support multiple encoder types
- Internal current limiting prevents motor and drive damage during overload conditions
- Parameter configuration and motion tuning via Elmo Motion Studio software
- Comprehensive fault recording for failure diagnosis and maintenance
- Low EMI design simplifies EMC compliance for machine integration
Application Scenarios:
- Heavy-duty industrial robot joint motion control
- Metal forming and hydraulic press electric servo axes
- Large gantry CNC machine tool feed drives
- Material fatigue and durability test benches
- Automated packaging heavy load transfer systems
- Semiconductor large substrate handling equipment
Material Composition:
- Main Enclosure: Painted aluminum alloy housing
- Main Power PCB: Thick copper FR4 multilayer power circuit board
- Control PCB: FR4 fiberglass signal board with conformal coating
- Power Semiconductors: IGBT power modules, high-speed gate drivers
- Connectors: Gold-plated D-Sub connectors, high-current power terminals, RJ45 Ethernet ports
- Heat Sink: Aluminum extrusion heat sink with cooling fins
- Passive Components: High-voltage film capacitors, high-power resistors, surge suppression components
Structural Features:
- Rectangular metal cabinet-style housing with built-in fin heat sink
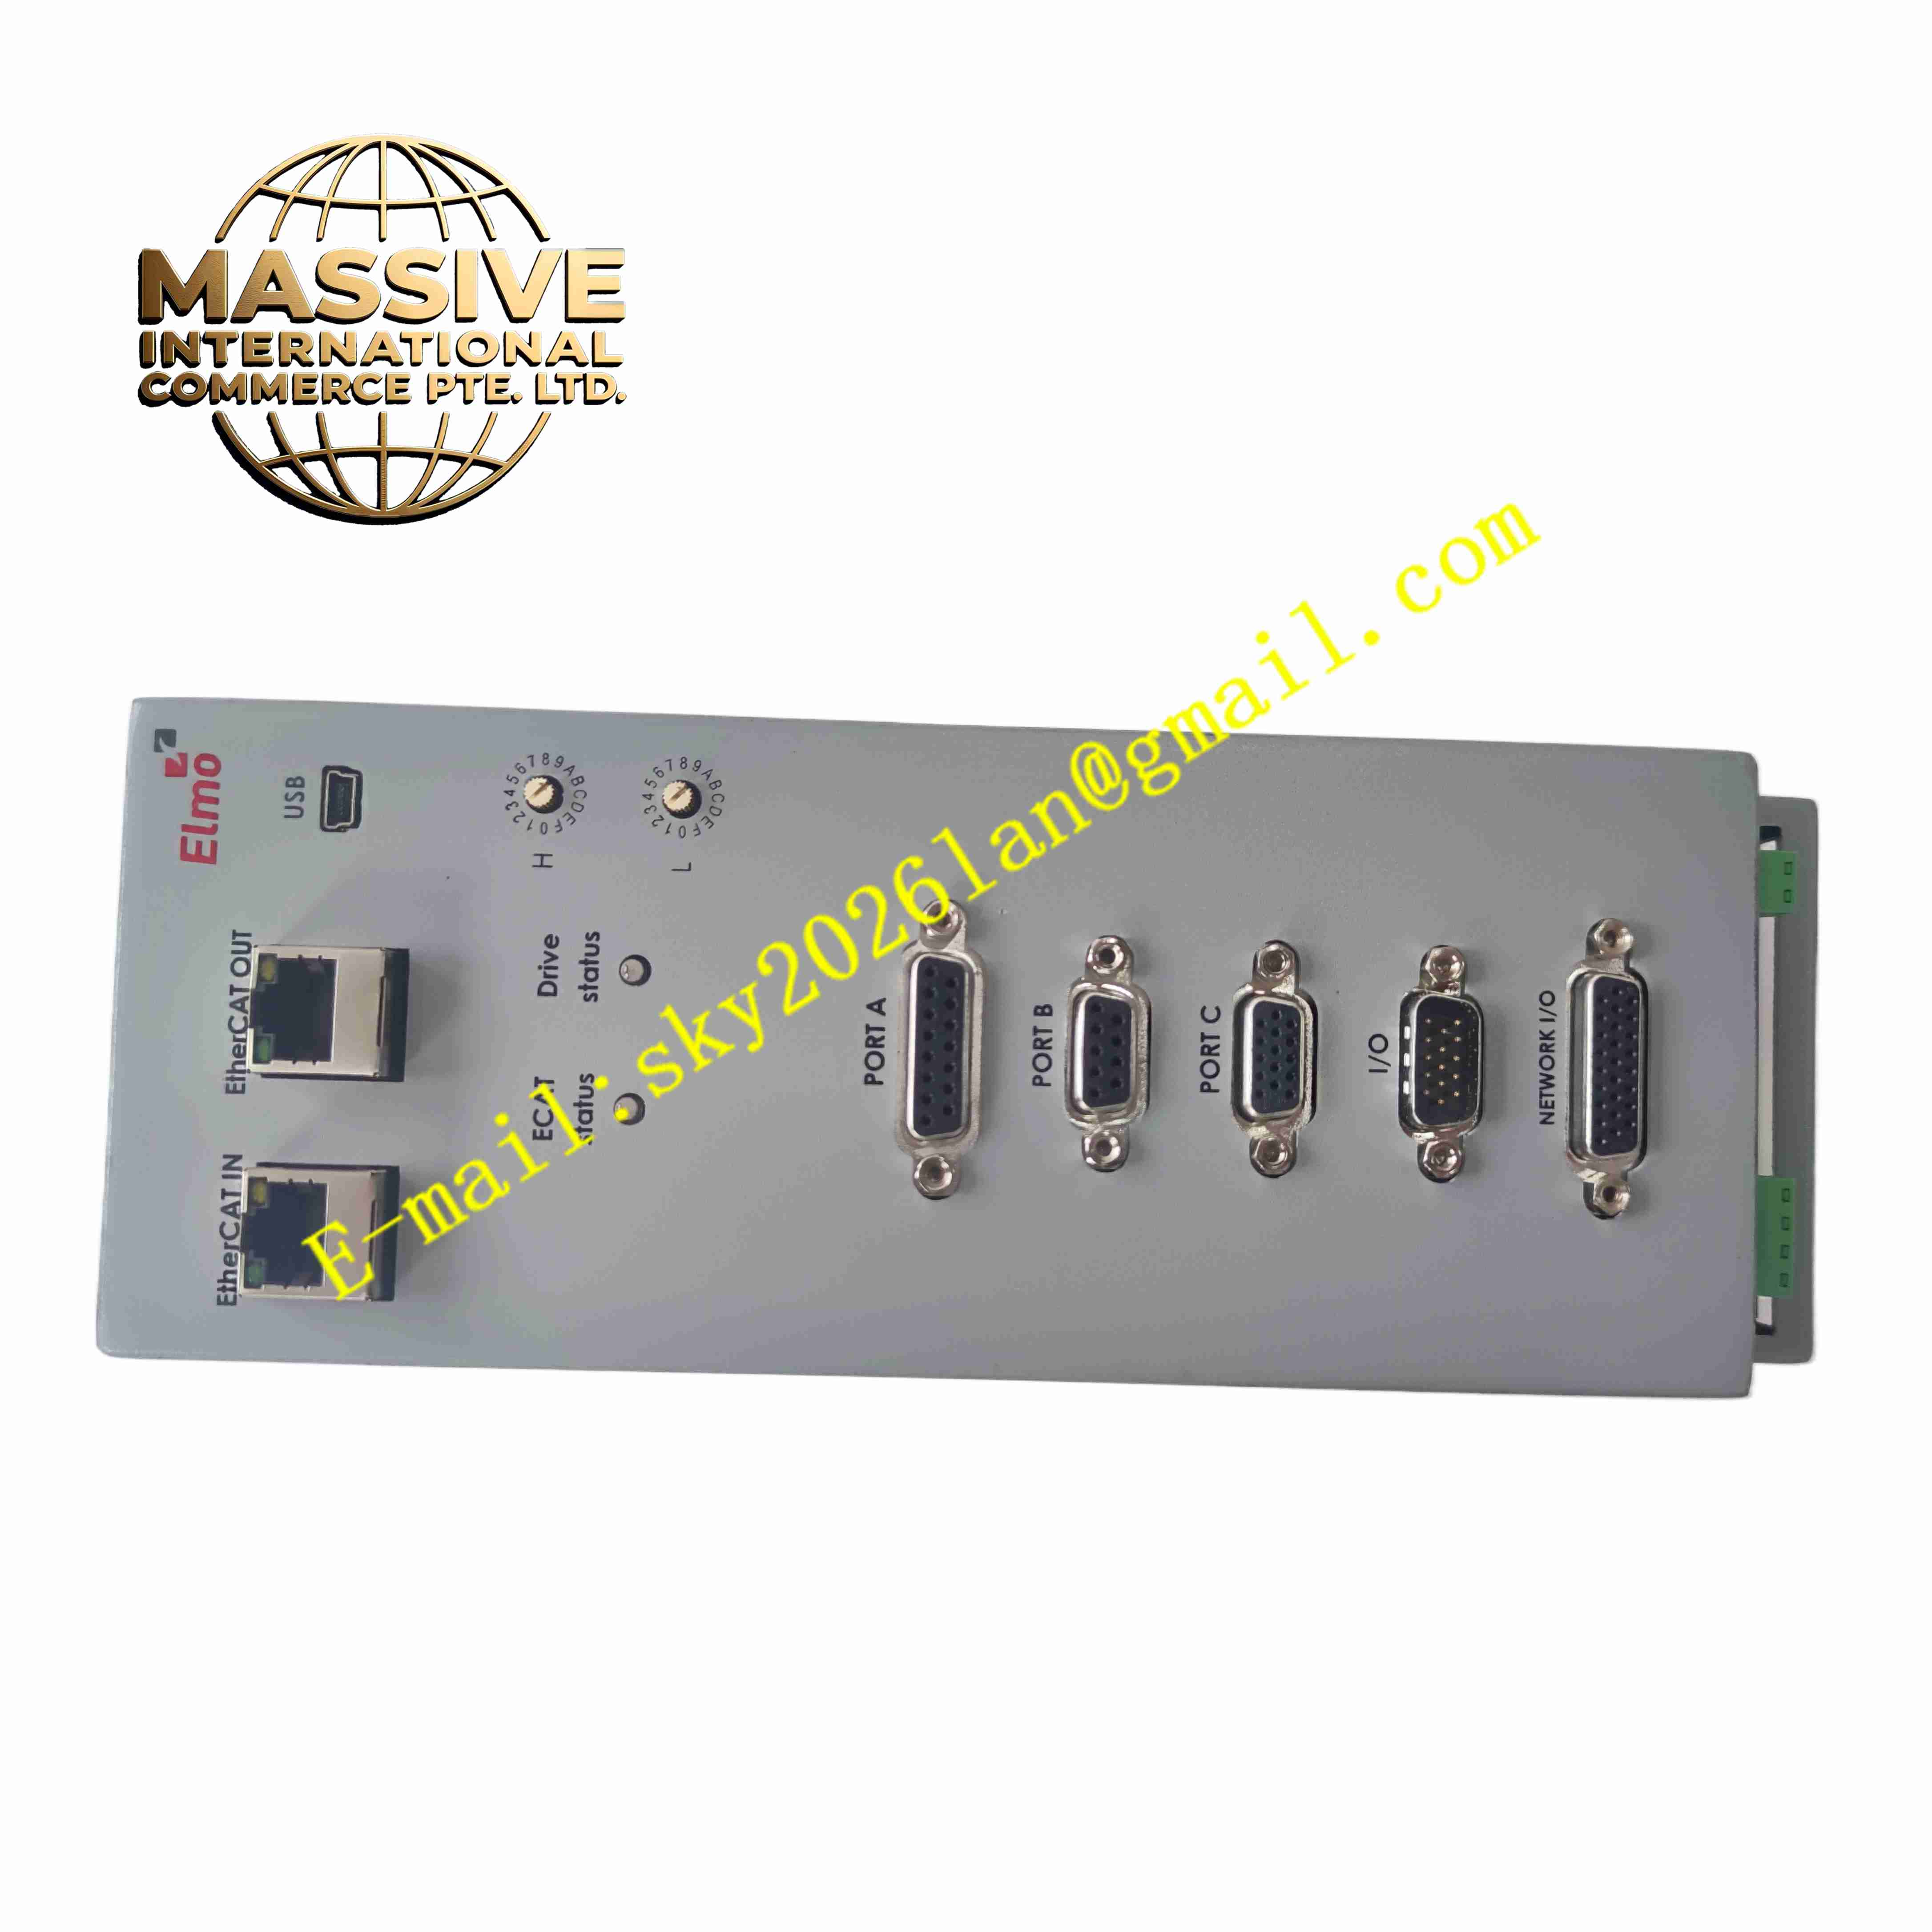
- Front panel equipped with EtherCAT ports, status LED indicators and USB debug port
- Multiple D-Sub connectors for encoder feedback, digital I/O and motor signal
- Separate wiring areas for high-power main circuit and low-level signal circuit
- Mounting holes on housing flange for secure wall mounting inside control cabinet
- Internal air convection channel for passive heat dissipation
Working Principle: Three-phase AC power enters the drive and converts to stable DC bus voltage via internal rectifier. The power IGBT bridge converts DC bus into variable frequency three-phase AC to drive servo motor. The drive samples motor encoder feedback signal continuously, compares feedback value with motion command. Internal control algorithm calculates error and adjusts output current to achieve closed-loop position, speed or torque regulation. STO safety circuit directly disables power stage gate drive signals to remove motor torque when safety signal triggers. EtherCAT bus receives motion commands from master controller and transmits axis status and fault data back in real time.
Installation Requirements:
- Mount drive vertically on cabinet internal metal backplate
- Maintain sufficient clearance around heat sink for natural convection cooling
- Use shielded high-current servo cable for motor wiring
- Use shielded twisted pair cable for encoder feedback and EtherCAT communication
- Separate power cables from low-level signal cables to reduce electromagnetic interference
- Connect protective earth terminal to cabinet earth bar
- Verify three-phase input voltage matches drive rated voltage before power-on
- Install input surge protection device for lightning-prone areas
Usage Notes:
- Complete motor parameter auto-tuning after wiring completion
- Configure STO safety circuit according to machine safety specification
- Do not exceed peak current and continuous power rating during operation
- Avoid operating drive with cooling fins blocked by dust or debris
- Disconnect three-phase mains power and wait for DC bus discharge before opening housing
- Check cable shielding and grounding to reduce encoder noise
- Backup drive parameter set before firmware upgrade







