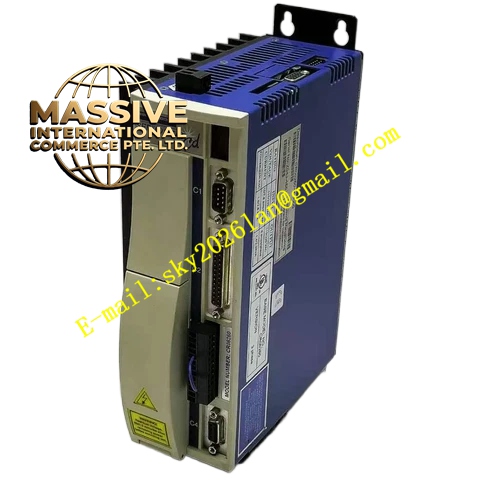
Description
Kollmorgen S60301-1YA
Technical Specifications
| Parameter Category | Specific Specification |
|---|---|
| Manufacturer | Kollmorgen (Danaher Motion) |
| Product Family | SERVOSTAR 600 Series |
| Power Supply | 3-Phase, 230 VAC nominal |
| Input Current | 4.5 Amps per phase |
| Input Power | 1.8 kVA |
| Output Voltage | 3 x 230 VAC (variable frequency) |
| Output Current | 3.0 Amps RMS continuous per phase |
| Peak Output Current | 9.0 Amps RMS (2 seconds) |
| Output Power | 1.1 kVA continuous |
| PWM Frequency | 10 kHz |
| Control Modes | Torque, velocity, position (via step/direction or analog) |
| Command Interface | ±10V analog, step/direction, encoder following |
| Feedback | Incremental encoder, resolver |
| I/O | 4 digital inputs, 2 digital outputs, 1 analog input |
| Protection | Overcurrent, overvoltage, undervoltage, overtemperature, regeneration fault |
| Operating Temperature | 0°C to +45°C |
| Storage Temperature | -25°C to +70°C |
| Protection Class | IP20 |
Key Features
- Proven Platform: The SERVOSTAR 600 series is a field-proven design with extensive installation base and long service history
- Analog Command Interface: Standard ±10V analog command input provides compatibility with legacy controllers and CNC systems
- Step/Direction Capability: Can accept step pulse and direction signals for position control mode, emulating a stepper drive
- Encoder Following: Master encoder input enables electronic gearing and synchronized motion between axes
- Compact Panel Mount Design: Book-style enclosure suitable for panel mounting in industrial control cabinets
- Comprehensive Diagnostic LEDs: Front panel LEDs indicate power, run, current limit, fault, and regeneration status
- Auto-Tuning: Built-in auto-tuning function simplifies commissioning by automatically measuring load inertia and setting loop gains
Application Scenarios
- Legacy CNC retrofits: Replaces older analog servo drives in CNC machine tool upgrades while maintaining existing controller interfaces
- Test equipment: Powers motion platforms in vibration testers, material testing machines, and durability test stands
- Packaging machinery: Controls filling, sealing, and cutting operations in form-fill-seal and flow-wrap machines
- Printing presses: Drives web tension control rollers, register control systems, and impression cylinders
- Semiconductor equipment: Powers wafer handling robots, probe stations, and inspection system stages
- Woodworking machinery: Controls saw feeds, router positioning, and edge banding equipment
- Converting machinery: Drives slitting, laminating, and coating line tension and speed controls
Performance Parameters The SERVOSTAR 600 series achieves a speed loop bandwidth of 500 Hz, providing good dynamic response for most industrial applications. The current loop bandwidth is 2 kHz, ensuring smooth torque delivery. The 10 kHz PWM frequency provides acceptable current waveform quality with moderate motor audible noise. Position loop update rate is 250 microseconds. The drive supports velocity feedforward and acceleration feedforward for improved tracking during contouring. Following error can be monitored via analog output for diagnostic purposes.
Material Composition The drive enclosure is constructed from steel with a baked enamel finish. Power semiconductors are discrete IGBT modules mounted on aluminum oxide ceramic insulators. The control board uses through-hole components on a double-sided PCB. DC bus capacitors are large-can electrolytic types with screw terminals. The heat sink is a cast aluminum extrusion with vertical fins. Front panel is molded plastic with LED lenses and connector cutouts. Internal wiring uses crimp terminal connections to terminal blocks.
Structural Characteristics The drive features a vertical book-mount design with power terminals at the top and control connectors at the bottom. The front panel is angled for easy viewing when mounted in a cabinet. A removable cover provides access to configuration jumpers and potentiometers. The heat sink forms the rear surface of the enclosure, designed for natural convection cooling. A thermostatically controlled cooling fan is included for high-duty-cycle operation. The base includes mounting slots for panel attachment.
Working Principle Three-phase 230 VAC input is rectified by a diode bridge to create a 325 VDC bus. The IGBT H-bridge inverter generates variable-frequency three-phase output. The control board uses a dedicated motion control DSP running the servo control algorithms. Analog command input is converted to digital by a 12-bit A/D converter. Motor current is sensed by Hall effect current sensors in each output phase. The velocity loop compares commanded velocity (from analog input or derived from step frequency) against actual velocity from encoder feedback. The torque loop controls motor current to achieve commanded torque. Protection circuits monitor bus voltage, output current, and heatsink temperature.