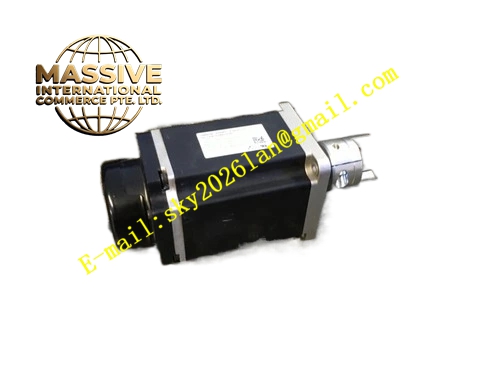
Description
OMRON R88M‑1M40030T‑S2
Technical Specifications: Rated output power 400 W; rated torque 1.27 N·m; peak torque 4.5 N·m; rated rotation speed 3000 r/min; maximum rotation speed 4500 r/min; encoder type: batteryless absolute encoder, resolution 23‑bit; power supply matching: single‑phase 230 VAC; flange dimension 60 mm square; shaft diameter 14 mm with shaft tap hole; rotor inertia 0.148 × 10‑4 kg·m²; allowable maximum radial load 245 N; allowable maximum thrust load 98 N; insulation class Class F; operating temperature ‑20‑40°C; storage temperature ‑25‑70°C; weight 1400 g; IP protection grade IP65 for shaft portion, IP20 for connector sectionOMRON Euro….
Functional Features: Batteryless absolute encoder saves regular battery replacement maintenance work; high‑resolution position feedback improves positioning accuracy; low‑cogging rotor design reduces torque ripple during low‑speed rotation; high peak‑torque output realizes fast acceleration and deceleration action; compact 60‑mm flange size saves mechanical installation space; compatible with EtherCAT 1S‑series servo drive system.
Application Scenarios: Automated assembly equipment; packaging machinery positioning axis; laser processing equipment feed axis; material handling mechanism; 400‑W‑grade servo system equipment upgrade and spare‑part replacement.
Performance Parameters: Insulation class F guarantees long‑term stable winding working temperature; vibration and shock resistance comply with IEC industrial motor standards; allowable load inertia reaches up to 30 times rotor inertia; supports frequent forward‑reverse acceleration‑deceleration cyclic operation.
Material Composition: Aluminum‑alloy motor front flange; cast‑aluminum motor housing; silicon‑steel‑sheet laminated stator core; high‑strength permanent‑magnet rotor assembly; high‑precision ball bearing groups; high‑resolution batteryless absolute encoder unit; metal shell power and encoder connectors; nickel‑plated output shaft.
Structural Features: Standard 60‑mm square flange mounting structure; single‑end output shaft with tap hole for coupling installation; rear‑side equipped with separate power connector and encoder connector; compact cylindrical housing structure; built‑in sealing rings for shaft‑end dust and splash‑water resistance.
Working Principle: After servo drive supplies three‑phase alternating current to motor stator winding, rotating magnetic field generates and interacts with rotor permanent magnet to produce torque and drive output‑shaft rotation. Rear‑mounted batteryless absolute encoder detects real‑time shaft angle and rotation position, transmits high‑resolution position feedback data back to matched servo drive. Servo drive forms closed‑loop position, speed and current control loop according to feedback signal to realize precise motion control.
Installation Requirements: Fix motor flange onto mechanical equipment mounting surface with specified‑torque bolts; select proper‑stiffness coupling matched with 14 mm shaft diameter; adopt shielded dedicated servo power cable and encoder cable; lay signal cables separately from high‑power inverter cables; ensure shaft‑end sealing ring keeps intact, avoid damage during installation process.
Usage Notes: Do not apply excessive radial or axial impact force onto output shaft during installation; do not exceed rated torque and peak‑torque operating limits; keep connector section away from liquid splash, connector part only satisfies IP20 protection; do not deploy in environments with corrosive gas; regular inspection of cable fastening condition is required.