



Description
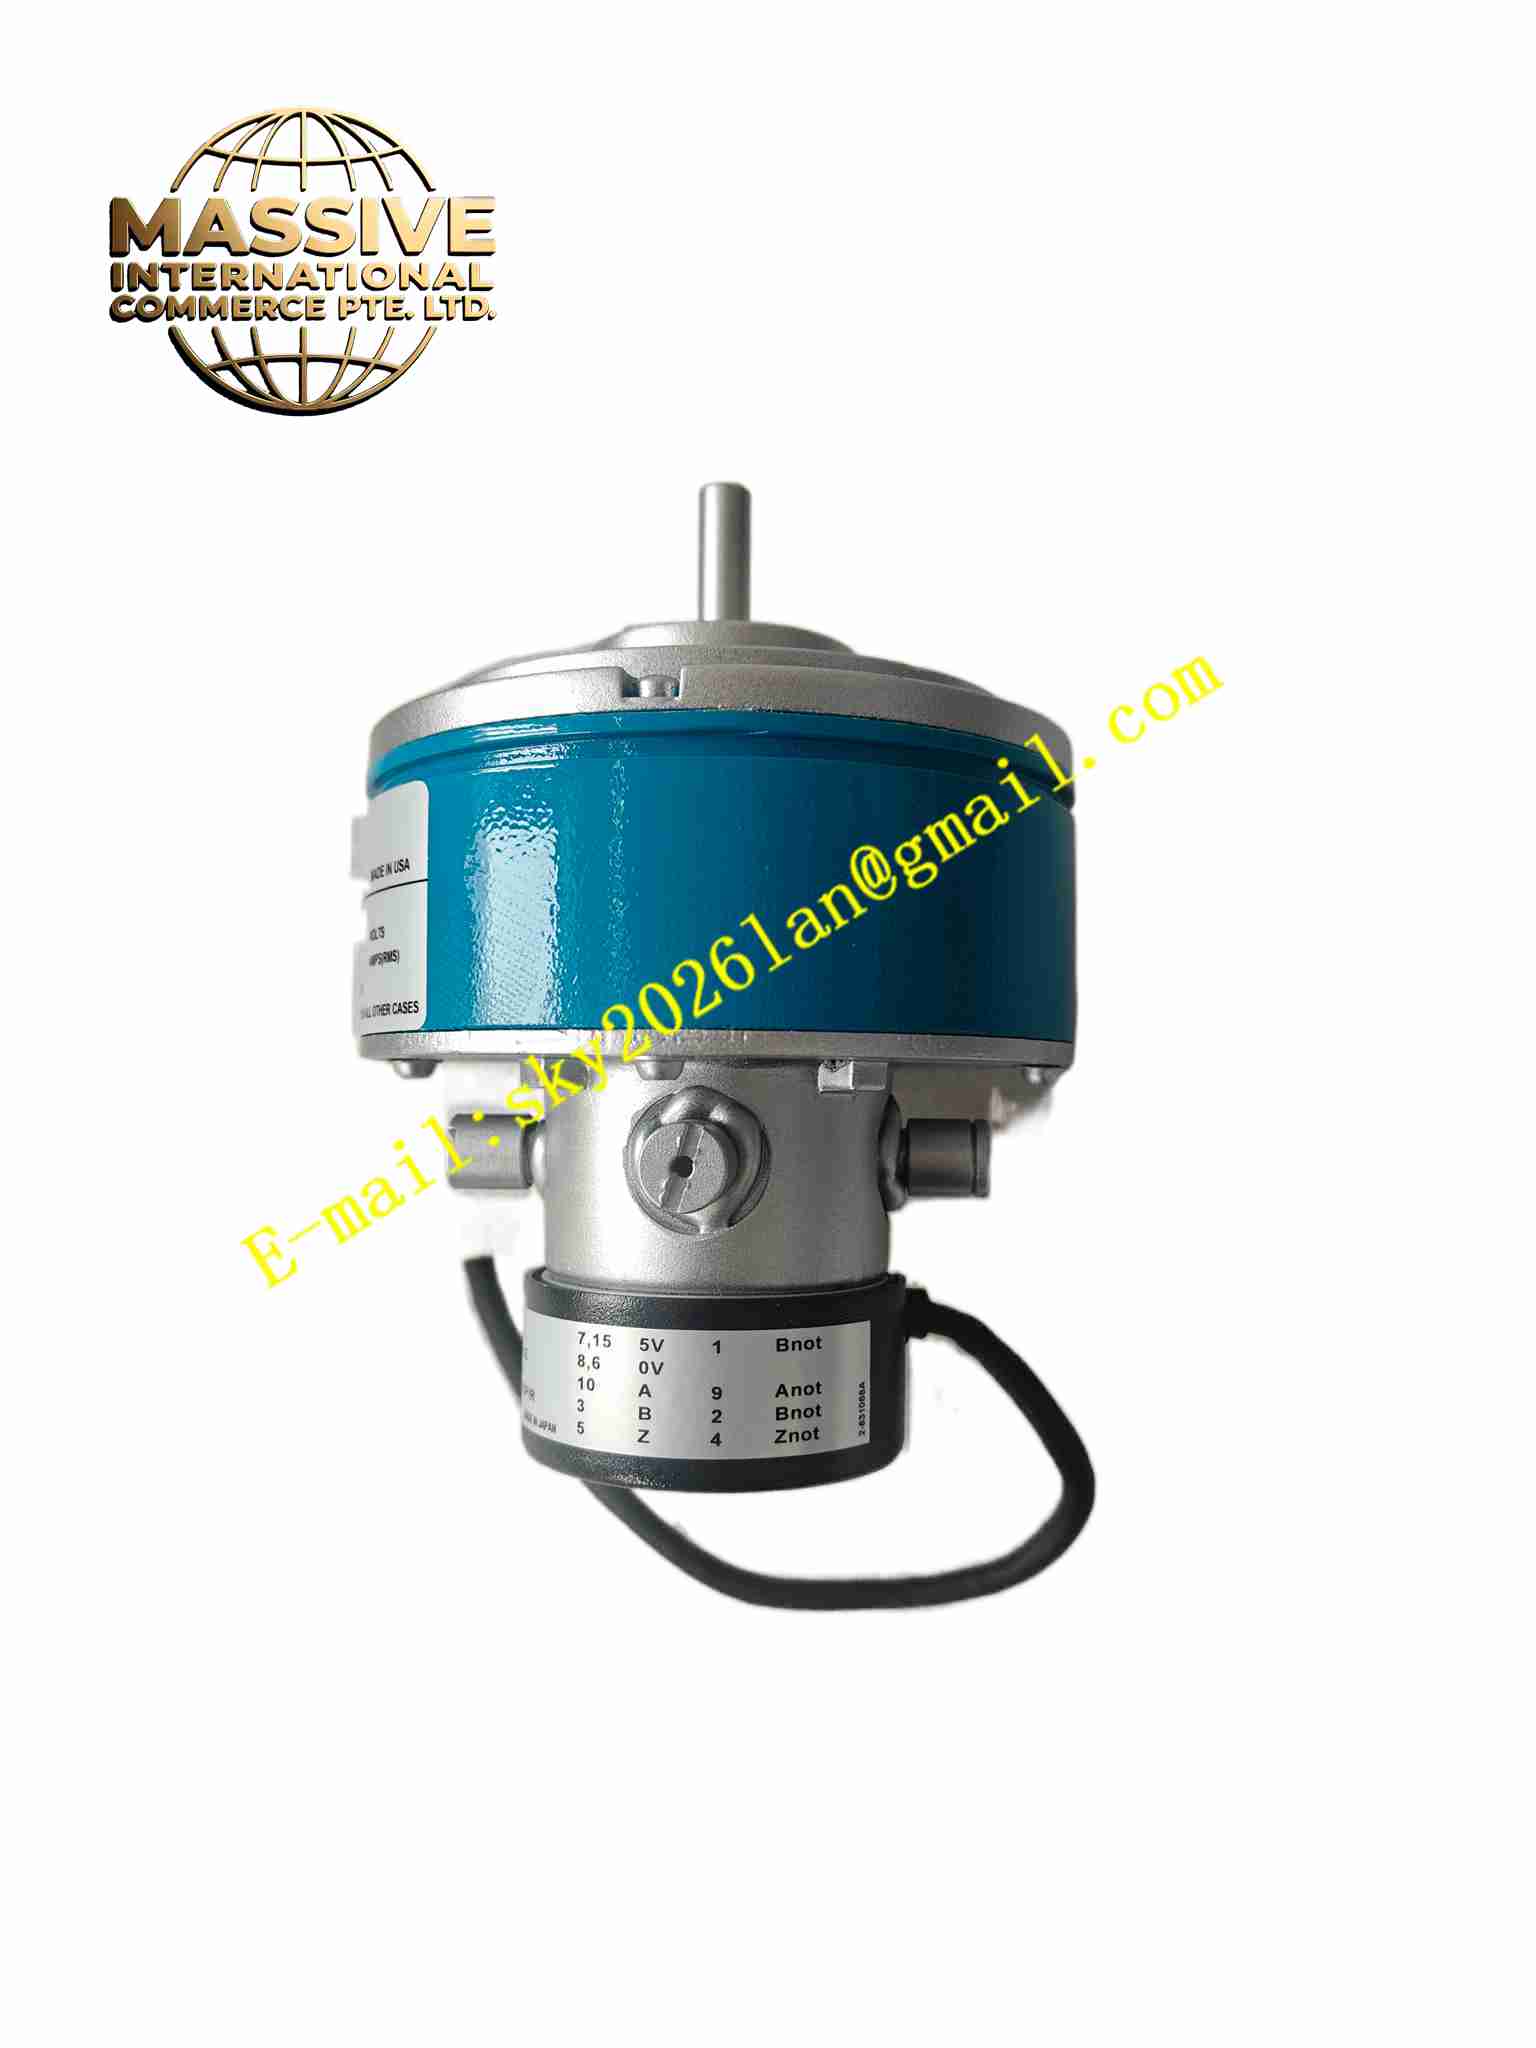
PACIFIC SCIENTIFIC 33VM52-000-29
Technical Specifications Brand: Pacific Scientific Model: 33VM52-000-29 Motor Type: 3-phase brushless permanent magnet servo motor Rated Voltage: 240 VAC Rated Speed: 5000 RPM Rated Torque: 1.2 Nm Feedback: Hall effect commutation sensors, incremental encoder mounting interface Shaft Diameter: 12.7 mm Winding Insulation Class: Class F Operating Temperature: -20°C to +40°C Protection Grade: IP64 Mounting: NEMA standard flange mounting
Functional Features High torque density compact rotor design provides continuous torque at high rotational speed. Built-in hall sensors supply rotor commutation position signal for servo drive. Standard flange mounting compatible with common machine mechanical interfaces. Sealed housing protects internal winding and sensor assembly from dust and splash. Low cogging torque ensures smooth rotation at low speed. High efficiency permanent magnet rotor reduces heat generation during continuous operation.
Application Scenarios Packaging machinery feed axis, small CNC equipment spindle and feed axis, automated pick and place mechanism, textile machine motion control, electronic assembly automation.
Performance Parameters Low cogging torque enables smooth low-speed operation. High efficiency reduces winding temperature rise under continuous load. Consistent torque output across full rated speed range. Mechanical structure withstands vibration from production machinery. Stable feedback signal output of hall sensors under temperature variation.
Material Composition Motor Housing: Die cast aluminum alloy. Rotor: High-energy rare earth permanent magnet, silicon steel lamination stack. Stator: Silicon steel lamination with copper magnet wire winding, Class F insulation. Output Shaft: Hardened alloy steel. Seals: Nitrile rubber shaft oil seal. Housing Fasteners: Zinc plated carbon steel screws.
Structural Features Standard NEMA flange body, cylindrical aluminum housing. Front output shaft supported by precision rolling bearings. Rear end cap accommodates hall sensor assembly and encoder mounting interface. Shaft seal prevents dust and liquid ingress from shaft opening. Internal stator winding fully encapsulated for vibration resistance.
Working Principle Servo drive supplies three-phase alternating current to stator winding. Stator generates rotating magnetic field, interacts with permanent magnet rotor field to produce continuous torque and rotate output shaft. Hall sensors detect rotor magnetic pole position and send commutation signal back to servo drive for phase switching. Encoder mounted on rear shaft provides high-resolution position and speed feedback for closed-loop position control.
Installation Requirements Mount motor flange rigidly onto machine bracket, fasten mounting bolts to specified torque. Align motor shaft with load shaft using flexible coupling, avoid radial and axial misalignment. Connect three-phase power cable and hall/encoder feedback cable to servo drive. Verify winding phase sequence and hall sensor wiring before powering system. Reserve clearance around motor housing for heat dissipation.
Usage Notes Do not apply excessive radial load on output shaft beyond bearing rating. Prevent impact damage to shaft and flange during installation. Check shaft seal periodically for oil leakage. Avoid continuous operation above rated speed and rated torque. Protect rear encoder assembly from mechanical impact.







