Description
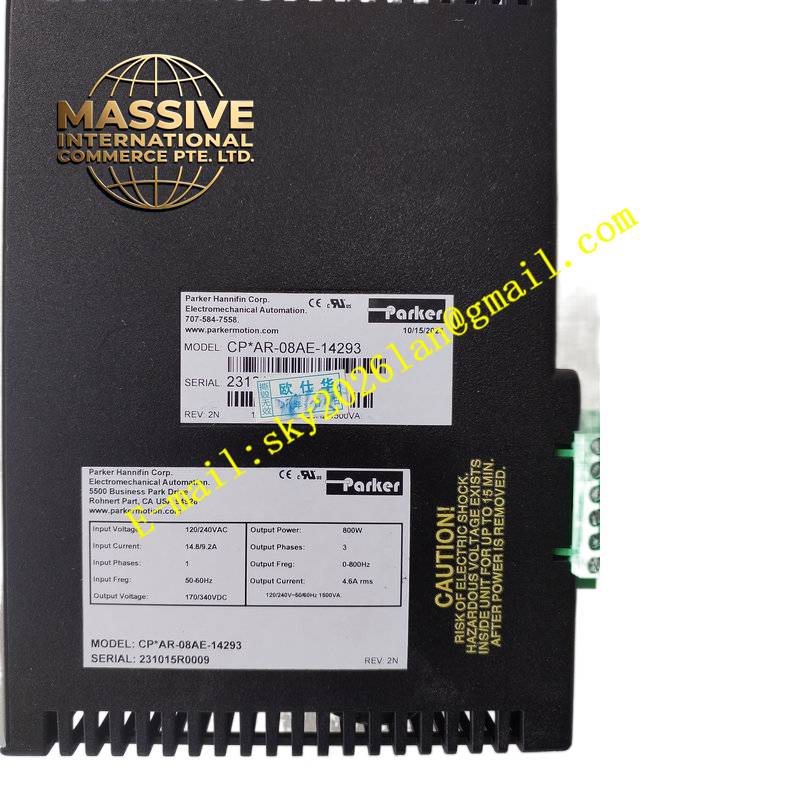
Parker CPAR-08AE-14293
Technical Specifications Single-phase AC input 200–240 VAC, tolerance +10% / -15%; continuous rated output current 8 A RMS; control modes include position, velocity, torque and cyclic synchronous EtherCAT mode; feedback interface supports EnDat 2.2 absolute encoder; integrated STO safe torque off function meeting SIL3 and PL e; operating temperature range 0 ℃ to 55 ℃, current derating required above 40 ℃; protection rating IP20; dimensions 70 mm width × 145 mm height × 165 mm depth.
Functional Features EtherCAT CoE protocol for high-speed synchronized motion; embedded electronic cam and motion profile generator; auto-tuning algorithm for inertia and friction compensation; comprehensive fault diagnosis including encoder loss, overcurrent, overvoltage and thermal overload; digital I/O configurable for enable, quick stop and status feedback; supports absolute encoder power retention for battery-backed position memory.
Application Scenarios CNC machine feed axes, laser cutting positioning systems, high-speed pick-and-place robots, printing register control, automated assembly lines and material forming machinery.
Material Composition Sheet metal casing and aluminum heat sink; power PCB with IGBT power modules; control PCB with FPGA and EtherCAT controller; isolated encoder signal circuit; plastic terminal hood for AC power, motor and feedback wiring.
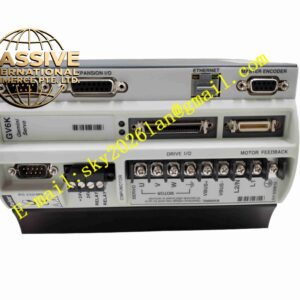
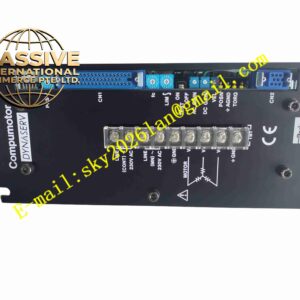
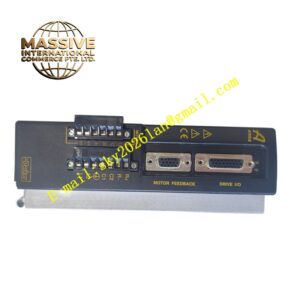
Structural Characteristics Vertical wall-mounted cabinet drive; upper section holds control signal terminals and encoder connector; lower section carries main AC power and motor output terminals; front panel has LED status indicators and service diagnostic connector.
Working Principle AC mains is rectified to DC bus voltage. The DSP receives EtherCAT cyclic setpoints from motion master, compares target position with absolute encoder reading, runs cascaded control loops and generates PWM signals for power stage. STO safety circuit cuts off gate drive signal independently when emergency stop activates.
Installation Requirements Mount vertically on rigid cabinet backplate; reserve vertical airflow clearance above and below drive; separate motor power cable from encoder and EtherCAT cables; install input AC fuse and EMC filter as specified in manual.
Operation Notes Wait for DC bus capacitors to fully discharge after power removal before opening cover; back up axis parameters before firmware upgrade; verify EnDat encoder wiring pin assignment after replacement.