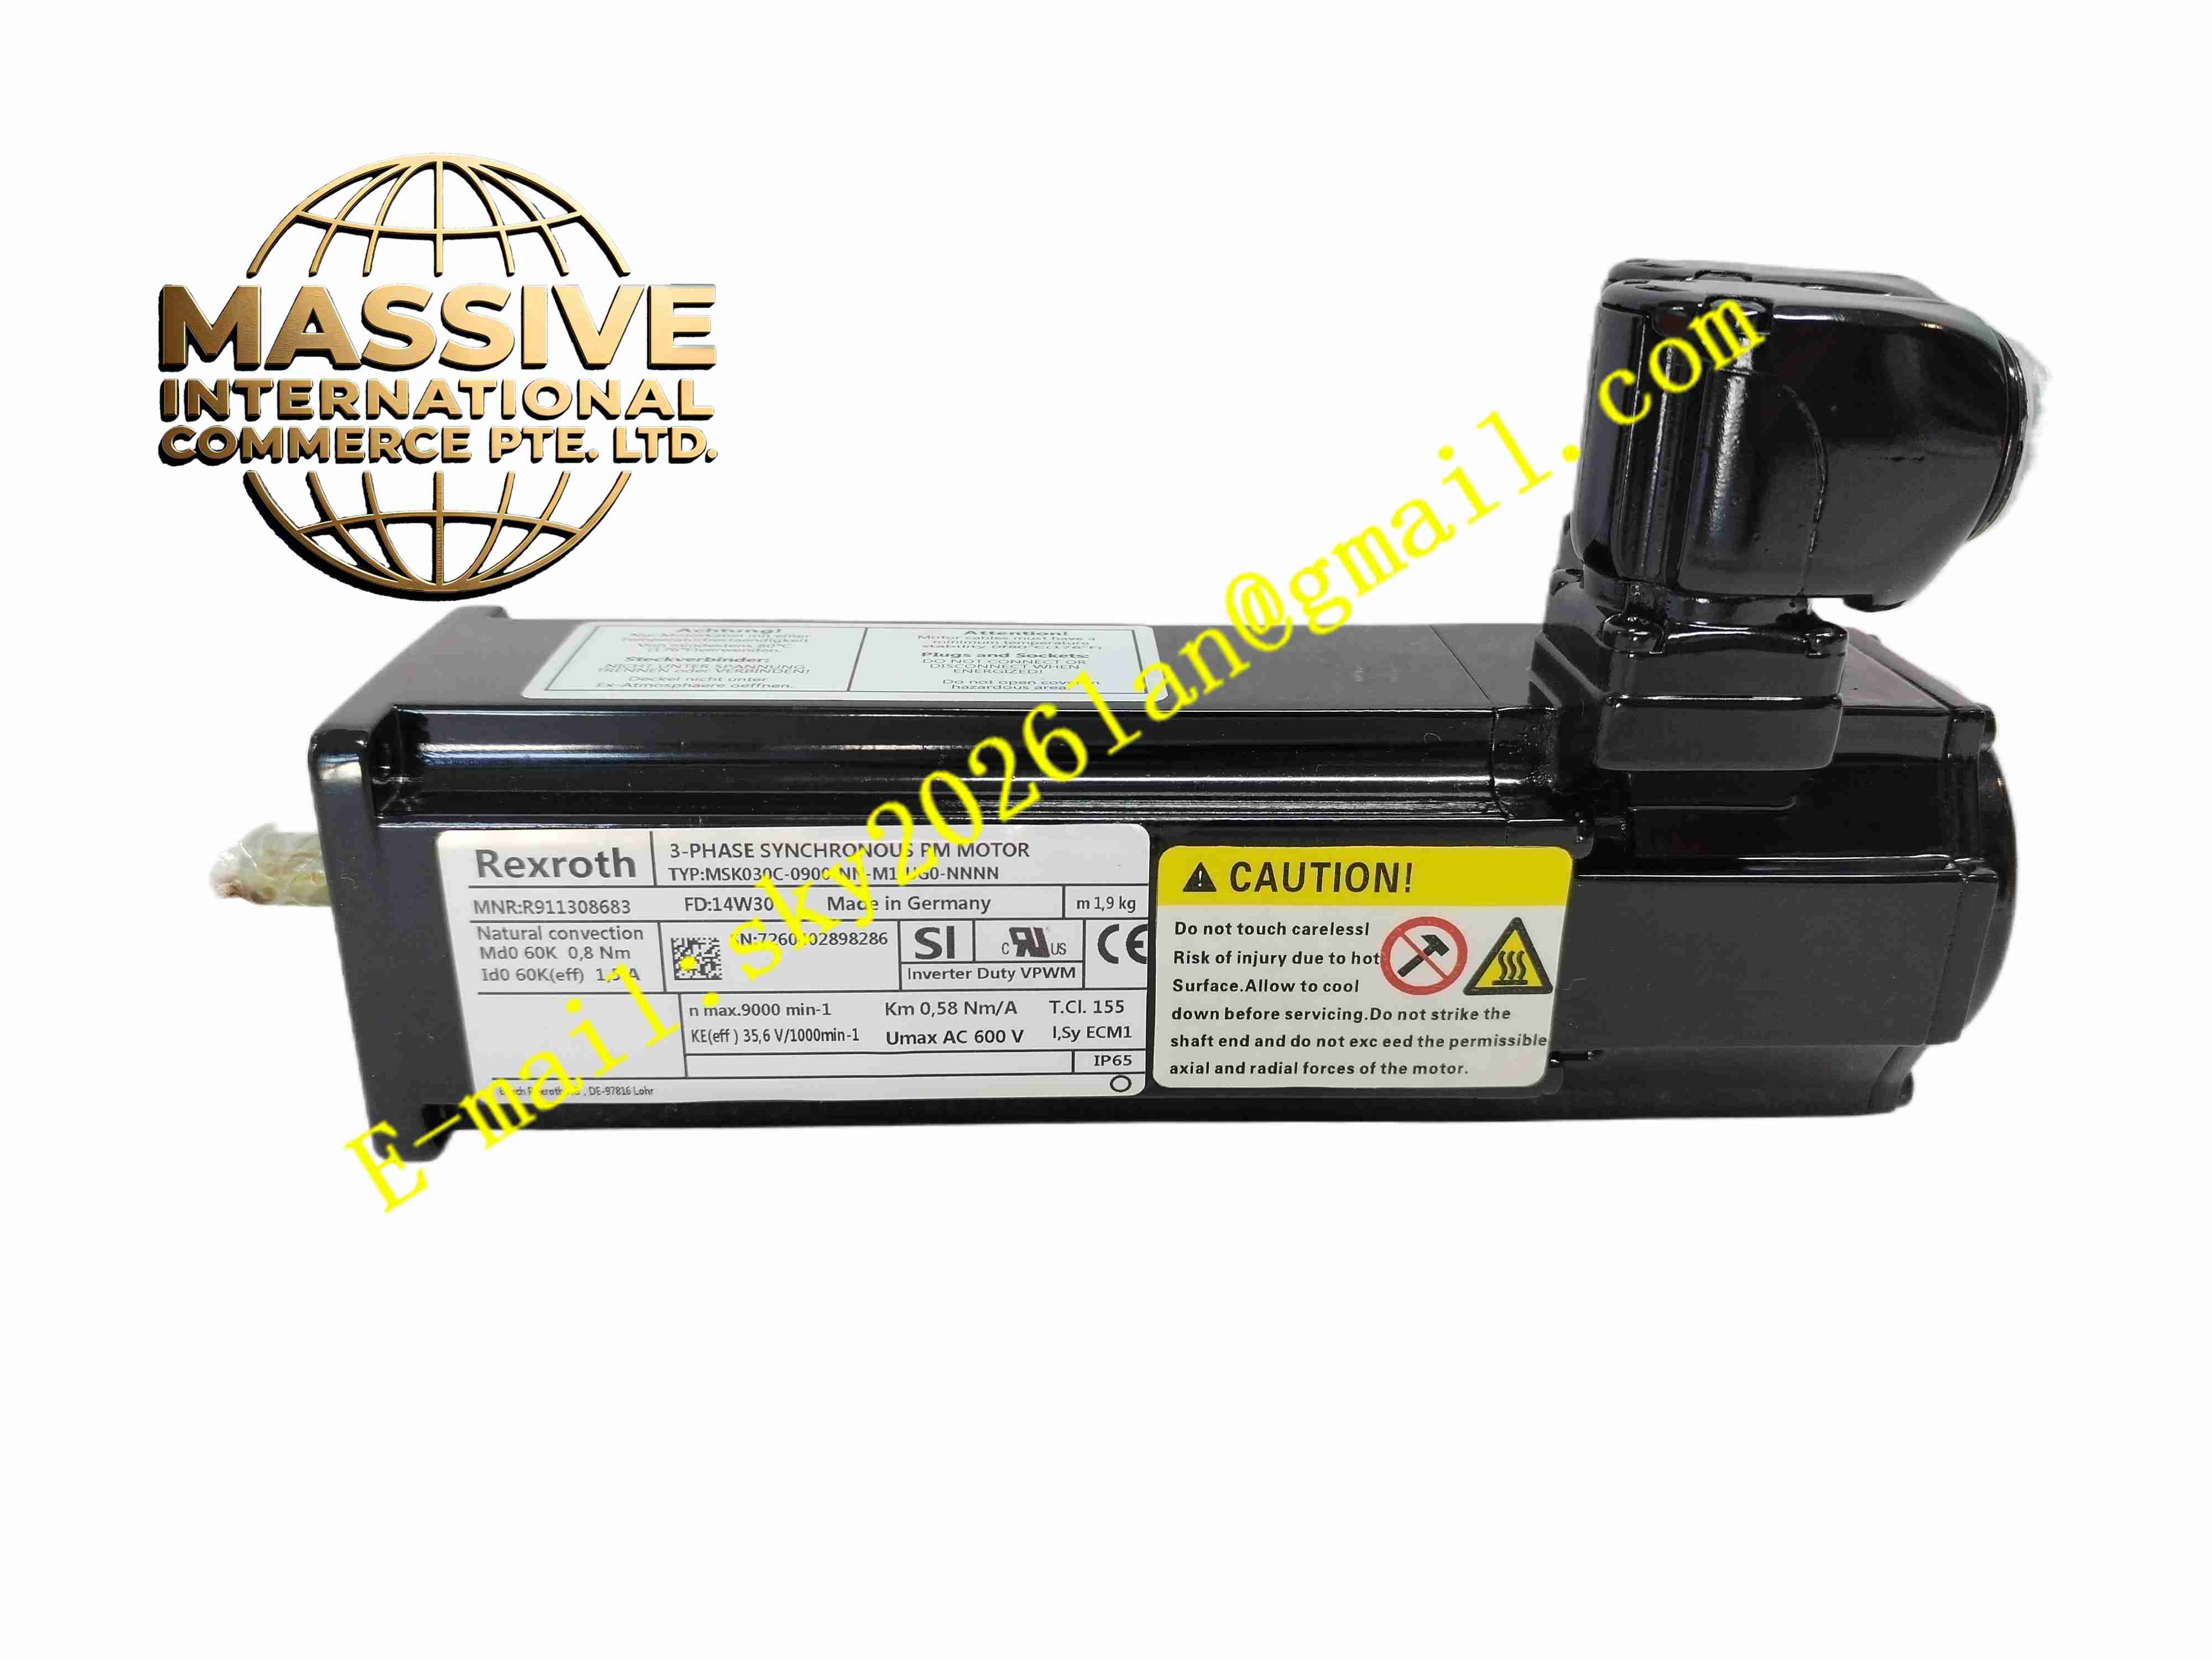
Description
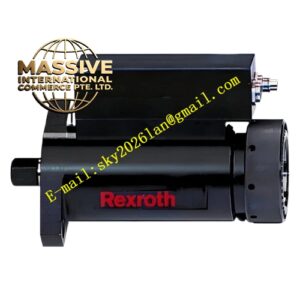
REXROTH MSK030C-0900-NN-M1-UG1-NNNN, R911308684
Technical Specifications Frame size MSK030, length class C; rated speed 9000 rpm; permanent magnet synchronous structure; multi-turn absolute encoder feedback; built-in electromagnetic holding brake; 400V three-phase winding; keyed output shaft; flange mounting; IP65 protection rating; natural convection cooling.
Functional Features Low rotor inertia enables ultra-fast acceleration and deceleration; integrated holding brake locks shaft when power supply cuts off; high resolution absolute encoder provides rotor position data without battery backup; low cogging torque ensures stable smooth rotation at low speed; compact housing reduces machine installation footprint; high peak overload torque supports short transient load spike.
Application Scenarios Electronic assembly machine positioning axis; small packaging machine servo drive; labelling and printing machine register axis; robot end effector joint; small CNC auxiliary feed axis.
Performance Parameters Operating ambient temperature -20℃ to +40℃; storage temperature -40℃ to +85℃; relative humidity 5% to 90%, no condensation; insulation class F; vibration resistance meets IEC 60068 industrial standard.
Material Composition Aluminum alloy motor housing; laminated silicon steel stator core; high-performance rare-earth permanent magnet rotor; insulated copper stator winding; stainless steel keyed output shaft; polyurethane shaft lip sealing ring; metal absolute encoder assembly; electromagnetic brake coil and friction disc.
Structural Characteristics Cylindrical compact motor body with standard front mounting flange; rear side integrated absolute encoder assembly; built-in brake module installed between stator and output shaft; side mounted connector terminal box for power and encoder cable; shaft outlet double lip seal for dust and moisture protection.
Working Principle Rexroth IndraDrive servo drive outputs three-phase variable frequency AC current into stator winding, generating rotating magnetic field. Permanent magnet rotor rotates and outputs mechanical torque. Absolute encoder continuously captures rotor angular position and speed, transmits feedback signal back to servo drive to realize closed-loop speed and position control. When power supply disconnects, brake coil de-energizes and friction disc locks motor shaft mechanically.
Installation Requirements Mount motor flange rigidly to machine mounting plate. Use shielded power cable and encoder feedback cable. Align coupling precisely to eliminate radial and axial misalignment. Complete protective earthing of motor housing. After power-on, perform motor parameter auto-identification in matched Rexroth servo drive and test brake release function.
Usage Notes Avoid radial overload force applied directly to output shaft. Keep motor housing surface clean to maintain natural heat dissipation. Inspect shaft sealing ring periodically. Do not disassemble encoder assembly without professional calibration equipment.