



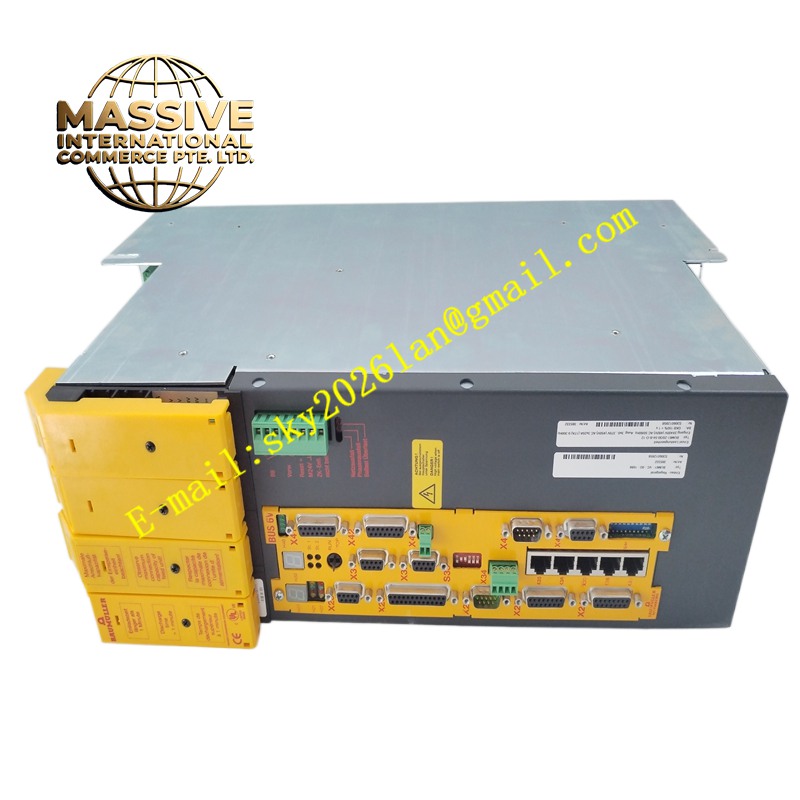
Description
Baumuller BUM61-2030-54-B
Technical Specifications Three-phase AC input; rated output current matched to medium-duty servo motors; supports resolver and encoder motor feedback interfaces; pulse direction and fieldbus command interfaces; built-in safety torque off function; operating ambient temperature 0°C to +45°C; IP20 protection rating; integrated braking resistor connection terminal.
Functional Features Receive motion setpoint commands from PLC or motion controller via digital pulse signals or fieldbus. Implement closed-loop control of motor torque, speed and position using motor encoder or resolver feedback. Generate PWM variable-frequency AC power to drive permanent magnet servo motors. Execute safety torque-off function to remove motor drive power upon safety circuit activation. Record fault codes and operating state data in internal memory. Support parameter configuration, auto-tuning and status monitoring through dedicated PC software.
Application Scenarios Printing machine axis control, metal forming automation, textile machinery motion axes, packaging machine servo positioning, robotic auxiliary axis driving systems.
Performance Parameters High dynamic response for rapid position setpoint changes; low speed ripple at low motor rotational speed; high bandwidth current control loop; reliable protection against overcurrent, overvoltage, undervoltage and overtemperature.
Material Composition Main power board uses heavy copper FR-4 substrate; power switching components are IGBT modules; control PCB uses FR-4 flame-retardant multilayer board; internal current and voltage sensors are high-precision shunts and transformers; chassis is coated sheet metal; heat dissipation assembly includes aluminum extruded heat sink and cooling fan.
Structural Characteristics Vertical book-style chassis designed for cabinet side-by-side mounting. Front panel equipped with status LED indicators and operation keypad. Top and bottom air ducts provide forced convection cooling. Terminal area separates high-power main circuit terminals and low-voltage control signal terminals. Internal layout isolates power semiconductor heat sink zone and low-voltage control board.
Working Principle Three-phase AC input is rectified into DC bus voltage. The IGBT inverter stage converts DC bus voltage into PWM modulated AC power for the servo motor. Feedback signals from the motor encoder or resolver feed rotor position back to the control processor. The processor compares actual position and speed with command values and adjusts PWM output to realize closed-loop motion control. Internal monitoring circuits continuously sample current, bus voltage and heat sink temperature and trigger protective shutdown when limits are exceeded.
Installation Requirements Mount the servo drive vertically on DIN rail or cabinet mounting plates. Connect three-phase AC supply to main input terminals and servo motor power cable to output terminals. Wire encoder feedback cable and safety circuit wiring to low-voltage signal terminals. Complete motor parameter entry and servo auto-tuning via keypad or PC software. Perform no-load motion test before connecting mechanical load to the servo axis.
Precautions for Use Reserve sufficient vertical airflow clearance above and below the heat sink. Use shielded motor and encoder cables and follow EMC grounding specifications. Wait for DC bus capacitor discharge after power removal before touching power terminals. Clean fan and heat sink dust during periodic machine maintenance.







