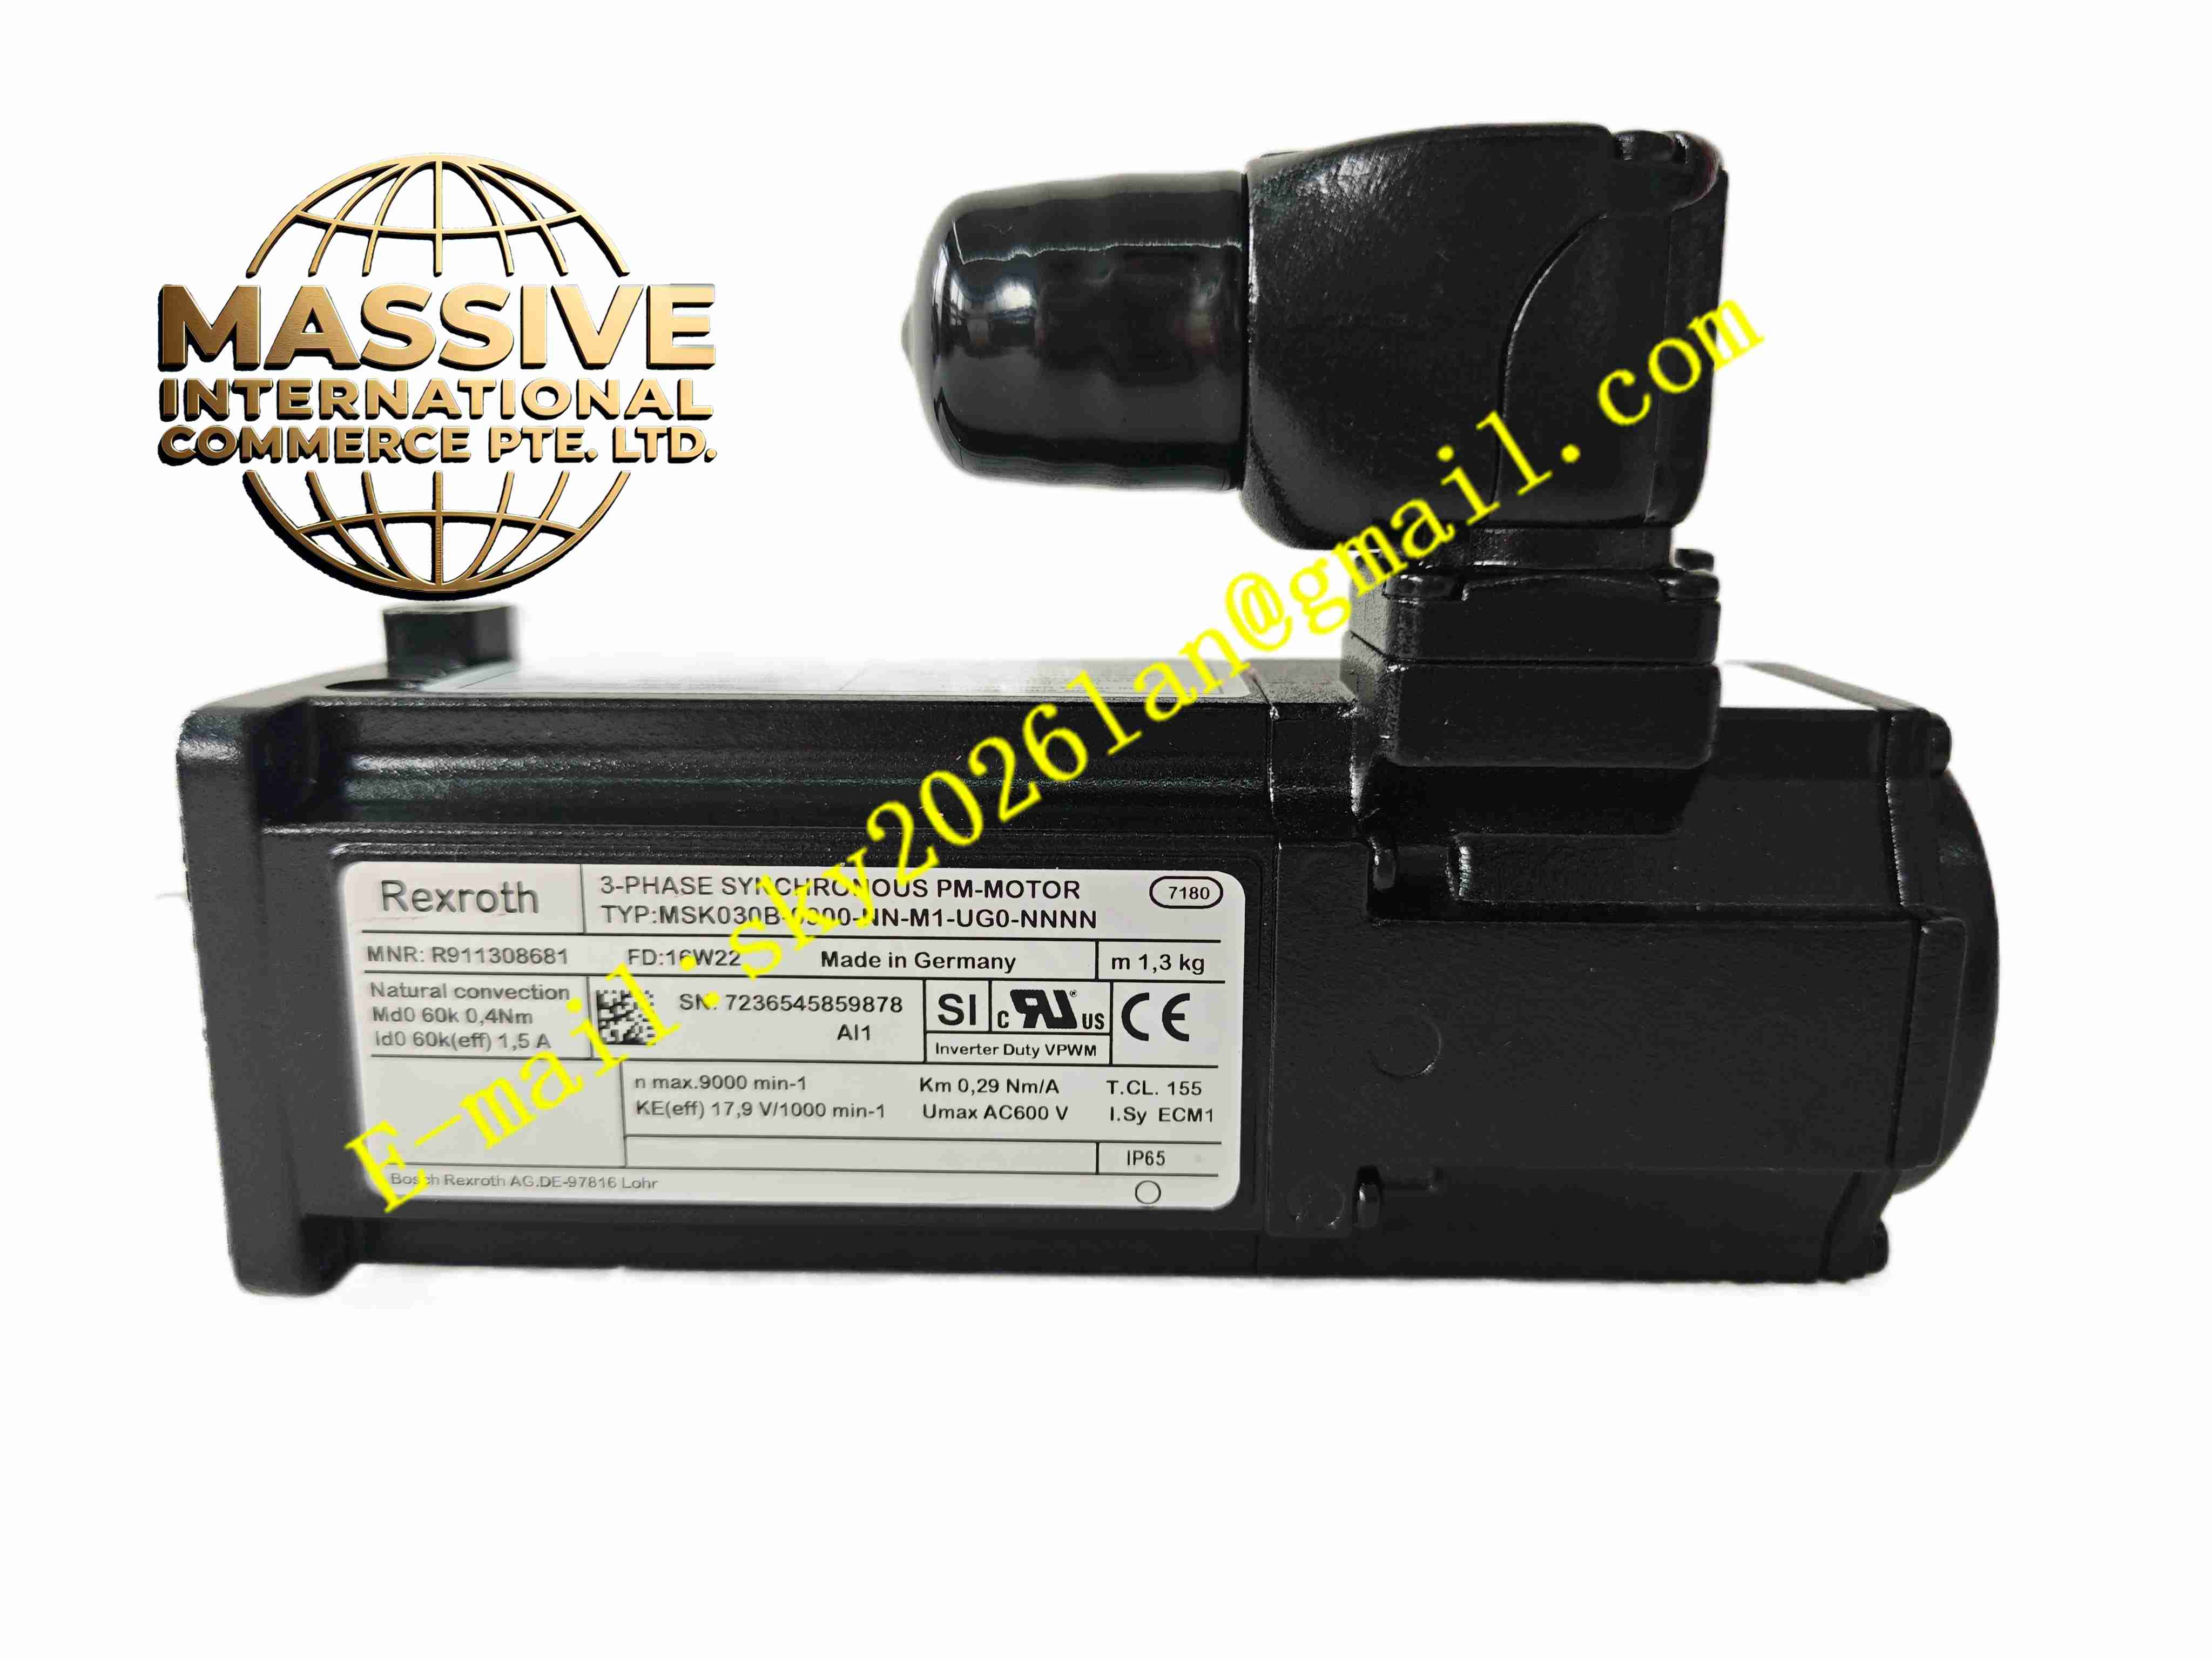
Description
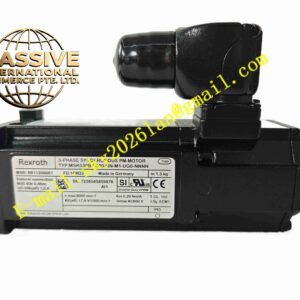
Bosch Rexroth MSK040C-0600-NN-M1-UG1-NNNN
Technical Specifications
- Product type: Permanent magnet synchronous servo motor
- Rated voltage: 400V AC
- Rated speed: 6000 rpm
- Rated torque: 1.2 Nm
- Peak torque: 3.6 Nm
- Shaft type: Smooth shaft
- Encoder type: Multi-turn absolute encoder
- Protection grade: IP64
- Temperature class: F
- Operating temperature: -20 °C to +40 °C
- Storage temperature: -30 °C to +80 °C
- Humidity: 5% to 85%, non-condensing
- Connector: Separate power and feedback circular connectors
- Bearing: Sealed lifelong lubrication bearing
Functional Features
- High continuous torque output
- Multi-turn absolute position feedback without battery backup
- Low cogging torque for stable low-speed operation
- IP64 housing protection
- Class F winding insulation
- Maintenance-free sealed bearing
- High rigidity flange structure
- Low vibration operation
- Compatible with Rexroth IndraDrive series drives
- Support high-speed positioning and synchronizing motion
Application Scenarios
- CNC machine tool auxiliary feed axis
- Packaging machine main drive axis
- Material handling robotic arm joint
- Printing machine register control axis
- Automated cutting equipment motion control
Materials and Construction
- Motor housing: Die-cast aluminum alloy
- Rotor: Silicon steel stack with high energy permanent magnet
- Stator: Enameled copper winding with Class F insulation
- Output shaft: Alloy steel heat treated
- Encoder unit: Metal shielding housing
- Connector: Nickel plated metal circular connector
Structural Features
- Cylindrical aluminum housing with flange mounting
- Rear multi-turn absolute encoder assembly
- Side mounted power and feedback connectors
- Front smooth output shaft
- Internal air gap between stator and rotor
- Front and rear bearing supporting structure
Working Principle Three-phase variable frequency current from servo drive generates rotating magnetic field inside stator. Permanent magnet rotor rotates following magnetic field. Multi-turn absolute encoder captures rotor angle and total rotation turns, sends digital position feedback to servo drive. Drive executes closed-loop control algorithm to adjust motor current for precise positioning, speed and torque control.
Installation Requirements
- Rigid flange mounting surface with flatness tolerance
- Control coupling misalignment within specification range
- Use double shielded servo power and encoder cables
- Reserve air convection space around motor housing
- Ambient temperature kept between -20 °C and +40 °C
- Complete motor identification and auto-tuning in drive software after power on
- Solid PE ground connection
Precautions
- Prevent radial and axial overload on motor shaft
- Shielded cable ground termination strictly follow Rexroth wiring guide
- Avoid metal powder accumulation on motor surface
- Do not disassemble encoder assembly
- Stop operation immediately if abnormal noise or overheating occurs
- Store spare motors in dry shockproof packaging