



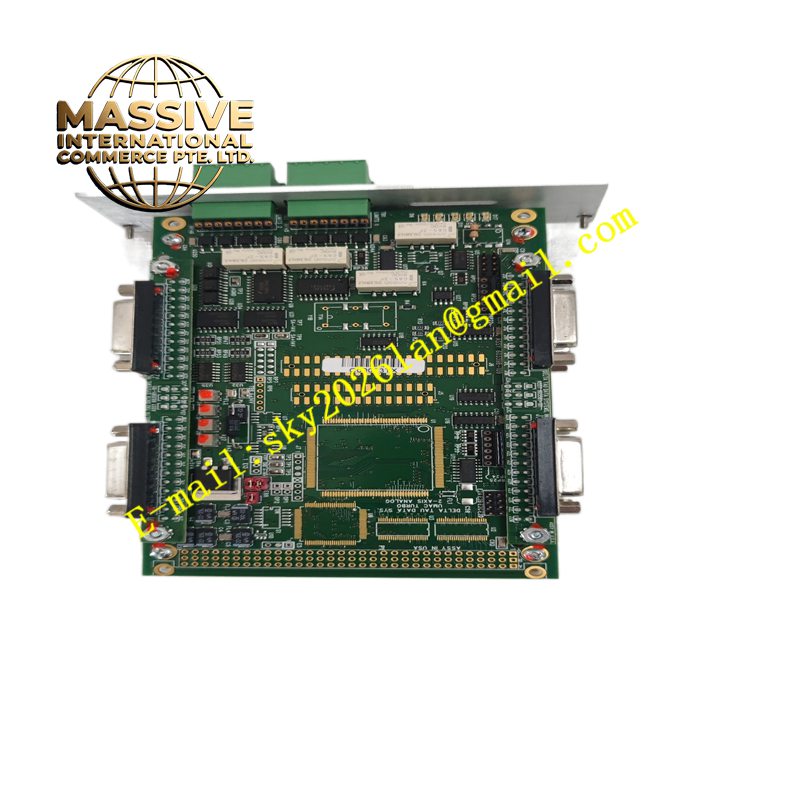
Description
Delta Tau ACC-24E2
Technical Specifications 2 independent control axes; analog servo output range ±10V DC with 16-bit digital-to-analog resolution; maximum output update rate 32kHz synchronous with PMAC servo loop; differential RS-422 quadrature encoder input with A/B/Z channels, maximum line frequency 40MHz; optically isolated dedicated home and index capture inputs per axis; two HD50 SCSI-II connectors, one for analog servo outputs and one for encoder feedback; power sourced from PMAC backplane +5V DC, typical consumption 1.2A.
Functional Features Converts digital position and torque setpoints calculated by the PMAC motion controller into ±10V analog command signals for analog servo amplifiers. Receives differential quadrature encoder signals from servo motors and converts pulse signals into digital position values for the PMAC processor. Captures high-speed home and index pulse events with hardware latching independent of the main processor loop. Supports encoder index mark capture for axis homing routines. Provides electrical isolation for home and index input circuits to reduce ground loop noise between the controller and servo machine.
Application Scenarios Retrofitting analog servo drives to Delta Tau PMAC motion systems, precision grinding machines, coordinate measuring machines, custom multi-axis positioning stages, automated optical inspection equipment.
Performance Parameters High resolution analog command output; low phase delay between PMAC servo loop and analog output; high bandwidth encoder input capture; accurate hardware latching of home and index pulses.
Material Composition Interface PCB is FR-4 multilayer flame-retardant printed circuit board; digital-to-analog conversion chips are high-precision industrial semiconductors; RS-422 differential receivers and optocoupler isolation devices are high-speed communication components; HD50 SCSI connectors use gold-plated copper alloy contacts.
Structural Characteristics Compact rectangular daughter board designed to plug into the PMAC main controller carrier or backplane. Two HD50 connectors mounted on the board edge for external servo and encoder cabling. Onboard status LEDs indicate power and encoder signal activity. Locating holes and edge connector ensure precise mating with the PMAC host board.
Working Principle The PMAC main controller calculates digital servo setpoints and transmits values to the ACC-24E2 board over the backplane bus. Onboard 16-bit DAC chips convert digital values into conditioned ±10V analog output signals sent to analog servo drives. Differential encoder signals from the motor pass to RS-422 receiver circuits and are decoded into quadrature position counts. Home and index pulses are captured by isolated hardware latch circuits and timestamped for the PMAC controller.
Installation Requirements Power off the PMAC chassis before installing the ACC-24E2 board. Insert the board into the designated expansion slot of the PMAC carrier board and secure fasteners. Connect analog servo drive command cables and differential encoder cables to the two HD50 connectors. Configure axis type, encoder resolution and DAC output scaling in PMAC software. Perform encoder direction test and servo loop tuning after wiring completion.
Precautions for Use Use shielded differential encoder cables and maintain proper differential line termination. Keep analog command cables separated from high-current servo power cables. Do not exceed the ±10V analog input rating of the connected servo amplifier.







