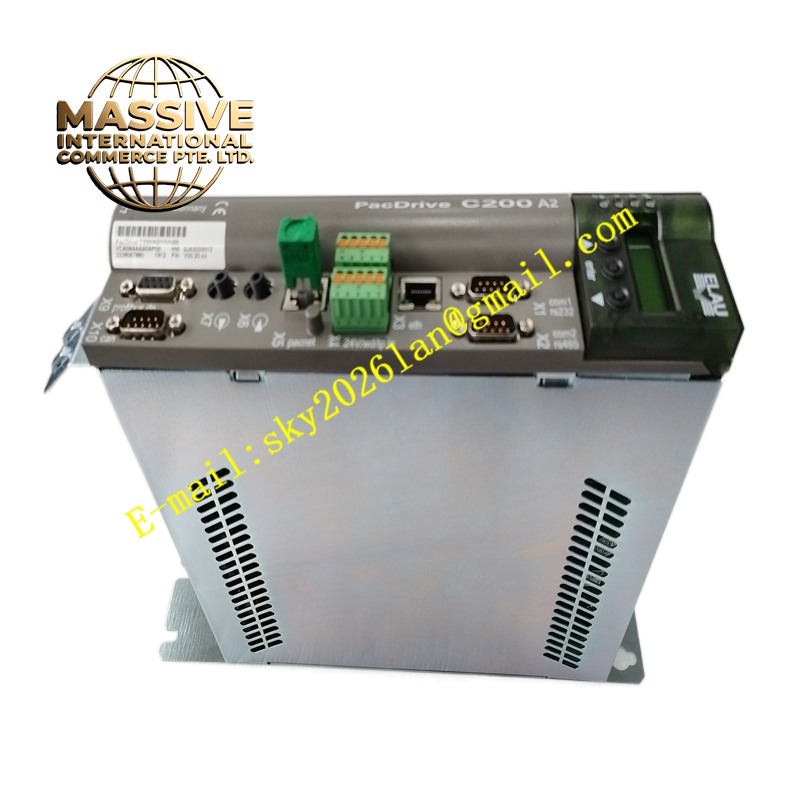
Description
ELAU C200A211100
Technical Specifications Integrated motion controller and servo amplifier; supports real-time Ethernet motion bus; multiple encoder feedback interface types; configurable axis control modes including position, speed and torque; built-in safe torque off safety function; 24V DC control supply; three-phase main power input; operating temperature 0°C to +45°C; IP20 protection rating.
Functional Features Execute centralized multi-axis motion synchronization for packaging machine transfer, cutting and forming axes. Run electronic cam profiles and electronic gear ratio functions without external PLC interpolation. Receive machine logic commands and process status signals from I/O modules. Output PWM power to matched ELAU servo motors and process motor encoder feedback. Store motion profiles, machine parameters and fault event logs in non-volatile memory. Support programming, trace and parameter download through engineering software.
Application Scenarios High-speed packaging machinery, carton forming and sealing equipment, web converting machines, pharmaceutical blister packaging lines, multi-axis material handling automation.
Performance Parameters Deterministic real-time axis synchronization; fast cam profile switching; high control loop bandwidth; precise registration control for printed web materials.
Material Composition Power circuit PCB uses high-current FR-4 substrate; control board is FR-4 flame-retardant multilayer board; main processing unit is industrial motion microprocessor; power semiconductors are IGBT power modules; chassis is powder-coated sheet metal; heat sink is extruded aluminum alloy.
Structural Characteristics Compact vertical cabinet-mount unit. Front panel carries status LEDs and service interface connector. Rear section includes main power terminals, motor output terminals, fieldbus port and encoder connectors. Internal structure partitions high-power drive section and low-voltage motion control section.
Working Principle The internal motion processor executes user programmed motion sequences and cam profiles. Motion command values are sent to the servo control loop. The inverter stage converts DC bus voltage to variable-frequency AC power to drive servo motors. Encoder signals feed actual axis position back to the processor to close the position loop. Multiple controllers synchronize axis motion through real-time industrial Ethernet bus to maintain coordinated machine operation.
Installation Requirements Install the controller vertically in a ventilated electrical cabinet. Wire three-phase main power, servo motor cables, encoder cables and 24V control power to corresponding rear terminals. Connect real-time motion bus cable between controllers. Download machine motion program and axis parameters using supporting engineering software. Test single-axis jog movement and multi-axis synchronization before machine production startup.
Precautions for Use Separate power cables and encoder signal cables in different cable ducts. Implement proper equipotential bonding for the cabinet ground system. Back up application programs and parameters before firmware update. Disconnect main power and control supply before modifying wiring.