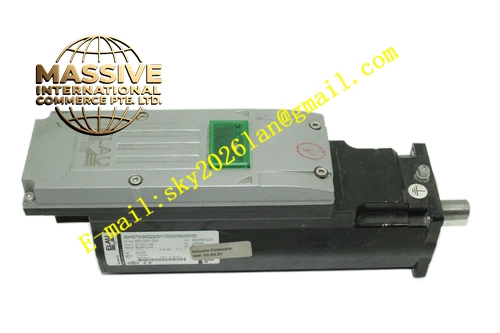
Description
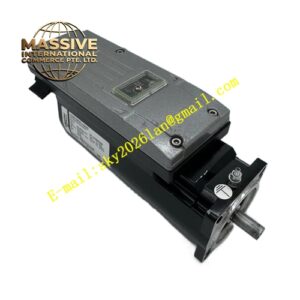
ELAU ISH070‑60017‑0‑0‑00‑0‑00‑00‑00
Technical Specifications Flange Dimension: 70 mm square mounting flange Rated Speed: 6000 rpm Rated Torque: 1.7 Nm Rated Voltage: 400 V AC class Encoder Type: Hiperface multi‑turn absolute encoder Built‑in Brake: None Shaft Configuration: Flat‑key output shaft Connector Type: 90‑degree rotatable circular power and feedback connectors Protection Class: IP65 Operating Ambient Temperature: ‑20℃ to +40℃ Storage Temperature: ‑25℃ to +70℃ Cooling Method: Natural convection cooling Mounting Type: Flange face mounting
Functional Features Multi‑turn Hiperface absolute encoder delivers complete absolute rotor position value immediately after power‑on, eliminating homing operation at machine startup. Embedded electronic motor nameplate enables servo drive to read full motor parameter dataset automatically. 90‑degree rotatable circular connectors support flexible cable outlet direction adjustment for compact machine internal wiring layout. Stator winding reaches F‑grade insulation class to maintain stable thermal performance under frequent high‑cycle start‑stop operations. IP65 housing structure blocks oil mist, dust and fine particle contamination inside mechanical equipment. Brake‑free mechanical layout shortens overall axial dimension of motor unit. Motor internal temperature sensor continuously feeds winding temperature data back to upper‑level drive for thermal protection.
Application Scenarios High‑speed light‑duty horizontal positioning axes of packaging machinery; label feeding and registration mechanisms; rotary indexing stations; auxiliary motion axes of printing and converting equipment.
Performance Parameters Steady‑state speed control accuracy reaches ±0.01%. Short‑term overload capability achieves 250% of rated torque. Multi‑turn absolute position data keeps retention status without external auxiliary power supply. Rotor assembly maintains low moment of inertia for fast acceleration and deceleration response. No mechanical shaft locking occurs when equipment power supply cuts off.
Material Composition Die‑cast aluminum alloy motor housing, silicon‑steel laminated stator core, neodymium‑iron‑boron high‑energy permanent magnet rotor assembly, Hiperface multi‑turn absolute encoder module, fluorine rubber sealing gaskets, alloy‑steel flat‑key output shaft, metal rotatable circular connector assemblies, internal NTC temperature sensing components.
Structural Characteristics 70‑mm square mounting flange with flat‑key machined output shaft. Rear end installs two independent rotatable circular connectors for power circuit and encoder feedback circuit separately. No built‑in brake assembly, overall axial length keeps compact dimension. Metal nameplate permanently prints complete part number ISH070‑60017‑0‑0‑00‑0‑00‑00‑00. Internal cavity reserves fixed installation space for encoder and temperature sensing circuit components.
Working Principle Upper‑level servo drive outputs three‑phase variable‑frequency alternating current to motor stator windings, generating rotating magnetic field to drive permanent‑magnet rotor rotation. Rear‑mounted Hiperface absolute encoder continuously collects rotor angular position and rotational speed signals, transmits feedback signals to servo controller for current‑speed‑position three‑loop closed‑loop calculation. Built‑in NTC sensor samples real‑time winding temperature value and sends data to drive unit. Without internal brake parts, motor output shaft keeps free rotation status after power disconnection.
Installation Requirements Tighten flange mounting screws strictly follow torque parameters printed on motor nameplate. Apply high‑precision coaxial alignment between motor output shaft and load transmission shaft through coupling parts. Deploy fully shielded motor power cables and shielded encoder feedback cables, lock circular connectors completely after insertion. Separate low‑signal encoder wiring physically from high‑voltage power cables. Ensure reliable ground connection for motor housing. Avoid vertical‑load mechanical application without external mechanical brake assembly.
Usage Notes Forbid striking or hammering motor output shaft surface during installation and maintenance operations. Wear anti‑static wrist strap when conducting maintenance work on encoder related components. Prevent circular connectors from oil contamination and moisture penetration. Do not block motor housing natural convection heat dissipation area. Operate within defined ambient temperature scope.