Description
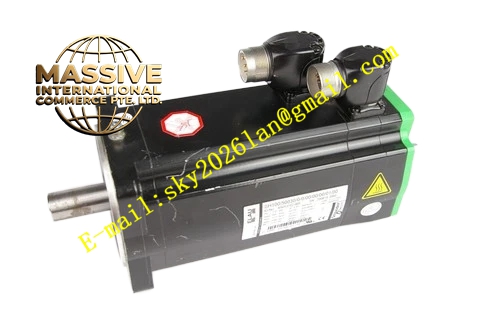
ELAU SH100‑30044‑0‑0‑00‑0‑00‑01‑00
Technical Specifications: Rated supply voltage 400 VAC, flange dimension 100 mm, rated speed 3000 rpm, maximum mechanical speed 4500 rpm, continuous stall torque 44 Nm, peak torque 132 Nm, continuous current 29.5 A, peak current 58.8 A, multi‑turn Hiperface absolute encoder, shaft diameter 24 mm, insulation class F, IP65 protection rating for housing and shaft sealing surface, side mounted rotatable M23 power and feedback connectors, no built‑in holding brake, net weight 15.7 kg.
Functional Features: Salient pole magnetic circuit achieves high torque density within medium frame size, high overload multiple supports short duration large torque output, multi‑turn absolute encoder preserves full range position information after power loss, embedded PT100 thermal sensor monitors winding temperature in real time, low cogging torque guarantees smooth low speed heavy load operation, rotatable circular connectors simplify wiring layout, full compatibility with high current PacDrive VDM servo amplifiers.
Application Scenarios: Packaging machinery main heavy duty drive axes, large format printing converting main drive shafts, textile heavy load processing axes, medium duty automated handling mechanisms, special purpose industrial machine tool servo axes.
Performance Parameters: Rotor inertia 62 kg·cm², torque ripple less than 2.4 %, multi‑turn encoder measuring range 4096 revolutions, thermal time constant 38 minutes, operating ambient temperature range ‑20 °C to +40 °C, all spatial mounting orientations are permitted.
Material Composition: Thickened die cast aluminum alloy fin cooled housing, thick stacked silicon steel sheet stator core, large size high energy neodymium iron boron permanent magnet rotor, high strength quenched alloy steel output shaft, glass fiber reinforced flame retardant PA plastic large current connector shell.
Structural Characteristics: Fully enclosed heavy duty fin cooled housing, IM B5 flange mounting design, keyway equipped large diameter output shaft, side mounted rotatable dual M23 connectors for power and feedback signal, PT100 thermal sensing element embedded inside stator winding, non‑brake mechanical structure, multi‑layer heavy duty dust and oil proof sealing design.
Working Principle: Three phase sinusoidal alternating current enters stator windings and generates rotating magnetic field, which drives large permanent magnet rotor to rotate synchronously. Multi‑turn Hiperface absolute encoder collects rotor absolute angle and speed data and transmits feedback signal to matched high current servo drive. Servo drive executes cascade closed loop control of current, speed and position to deliver precise heavy load motion output. Embedded thermal sensor continuously uploads winding temperature data for overheat protection.
Installation Requirements: Use high strength metric bolts with specified torque to fasten motor flange to mechanical mounting surface; coupling coaxial alignment tolerance must stay under 0.05 mm; maintain minimum 70 mm surrounding clearance for housing heat dissipation; install within cabinet or enclosed mechanical frame; fully lock large current connector locking ring to prevent loosening under heavy load vibration; strictly separate high power motor cable and feedback signal cable routing paths.
Usage Notes: Prohibit heavy mechanical impact on motor shaft during hoisting and installation; encoder type and motor parameter dataset must match supporting high current servo drive; avoid continuous long time operation under peak torque working state; prevent oil mist, conductive dust and liquid from breaking IP65 sealing surface; implement full ESD anti‑static protection when maintaining encoder wiring terminals; regularly check large current connector tightening torque under high vibration heavy load working environment.