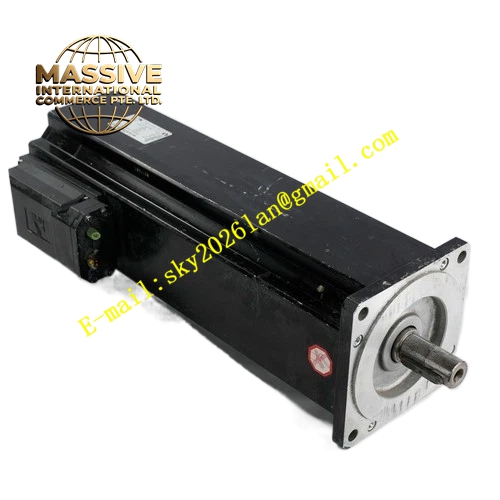
Description
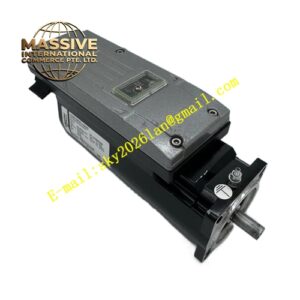
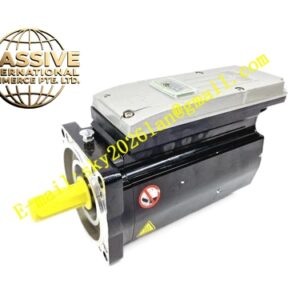
ELAU SM‑140‑30‑120‑P1‑45‑S1‑B0
Technical Specifications: Rated power 4.2 kW, rated speed 3000 rpm, maximum speed 3500 rpm, continuous stall torque 13 Nm, peak torque 27 Nm, rotor inertia 6.54 kg·cm², insulation class F, IP65 protection level, 140 mm B5 mounting flange, 24 mm flat‑key shaft, Sin‑Cos encoder S1, power connector P1, no holding brake B0, natural air cooling, weight 12.4 kg, ambient working temperature 0 °C‑40 °C.
Functional Features: Sin‑Cos encoder with embedded electronic nameplate supports automatic motor‑parameter identification by PacDrive controller. High‑torque‑density rotor meets heavy‑load acceleration requirements. Internal PTC thermal sensor implements over‑temperature cutoff protection. High sine‑wave back‑EMF characteristic reduces system power loss. Maintenance‑free bearing unit, high short‑time overload capacity.
Application Scenarios: Heavy‑duty packaging machinery, large‑format printing equipment, extrusion auxiliary drives, gantry‑type processing machines, automated palletizing robots, material‑forming automation equipment.
Performance Parameters: Thermal time constant 65 min, CE and UL certified, three‑phase 400 V AC input.
Material Composition: Thick‑wall die‑cast aluminum alloy housing, high‑grade silicon‑steel‑laminated stator core, high‑energy‑density rare‑earth permanent‑magnet rotor, oxygen‑free‑copper stator windings, quenched alloy steel output shaft, reinforced thermoplastic connector shell parts.
Structural Features: 140 mm standard B5 flange layout, separate power‑supply and encoder signal connectors mounted on top housing, labyrinth‑type shaft‑end sealing structure, stator‑embedded PTC temperature sensor, compact heavy‑duty frame structure.
Working Principle: Servo drive outputs three‑phase sinusoidal current to generate stator rotating magnetic field, interacts with rotor permanent‑magnet field to generate driving torque. Sin‑Cos encoder captures real‑time rotor angle and velocity data and feeds signals back to servo drive to complete high‑precision closed‑loop motion control.
Installation Requirements: Secure motor onto sufficiently rigid metal base to suppress mechanical vibration. Control coupling concentricity error below 0.06 mm. Reserve adequate ventilation clearance around motor housing. Separate power cables and encoder signal cables. Connect protective‑earth terminal reliably to ground busbar. Verify connector full locking after wiring completion.
Usage Notes: Operating ambient must stay non‑condensing, humidity 5‑85 %. Do not subject motor shaft to radial or axial overload beyond specification. Set controller feedback parameter to Sin‑Cos encoder mode. Avoid continuous operation under peak‑torque condition. Prevent welding‑current passing through motor housing.