Description
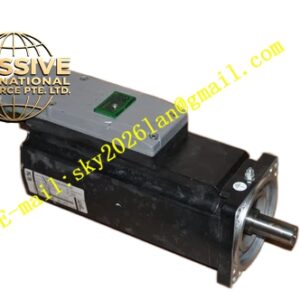
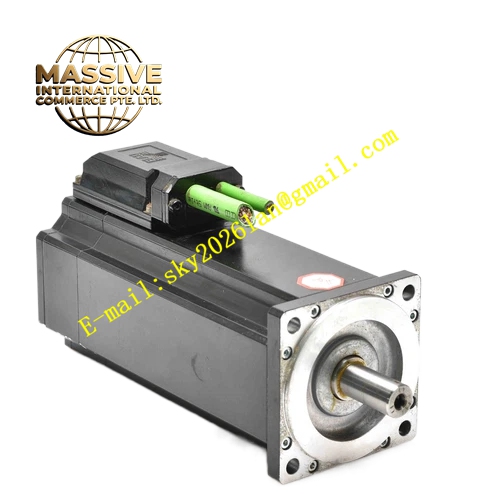
ELAU SM100-40-050-P1-45-S1-B1
Technical Specifications:
- Brand: ELAU (Schneider Electric)
- Model: SM100-40-050-P1-45-S1-B1
- Series: SM-100
- Flange Size: 100 mm
- Rated Speed: 4000 RPM
- Encoder: P1 (High-precision encoder)
- Feedback Type: S1 (High-resolution incremental encoder)
- Brake: B1 (Integrated electromagnetic holding brake)
- Protection Class: IP65/IP67
- Origin: Germany
Functional Features:
- High Power Density: Delivers substantial torque output within a compact 100mm frame
- Integrated Holding Brake: The B1 brake engages automatically when power is removed, securing the load in position
- Precision Feedback: P1/S1 encoder configuration provides high-resolution position feedback for accurate closed-loop control
- Robust Construction: IP65/IP67 protection rating suitable for harsh industrial environments including wet and dusty conditions
- Single Cable Technology: Simplifies wiring with combined power and feedback connections
- Auto-Parameterization: Supports automatic motor identification when connected to ELAU PacDrive controllers
Application Scenarios:
- Vertical lifting axes in robotics and material handling systems
- High-speed packaging machinery (cartoning, wrapping, palletizing)
- Servo capping and labeling machines on rotary tables
- CNC machine tool feed drives
- Industrial robot joint drives requiring load holding
Performance Parameters:
- Stall Torque: High continuous torque output suitable for medium to heavy loads
- Overload Capacity: Up to 4× rated torque for short-duration peak demands
- Control Modes: Position, velocity, and torque control
- Dynamic Response: High dynamic response with fast acceleration and deceleration capability
- Positioning Accuracy: Micron-level positioning precision with closed-loop feedback
Material Composition:
- Industrial-grade aluminum housing for efficient heat dissipation
- Neodymium Iron Boron (NdFeB) permanent magnets in the rotor
- High-quality copper windings with Class F insulation (155°C)
- Precision-machined steel shaft
Structural Features:
- 100mm standard flange mounting interface
- Integrated electromagnetic brake unit at the rear of the motor
- Smooth cylindrical housing surface for easy cleaning in hygienic environments
- IP67-rated sealed connectors for dust and water resistance
- Reinforced bearing design to handle high radial loads
Working Principle:
The motor operates as a three-phase AC synchronous servo. The drive supplies precisely controlled current to the stator windings, creating a rotating magnetic field that interacts with the permanent magnet rotor. The integrated encoder continuously feeds position data back to the drive, enabling closed-loop control of position, speed, and torque. The holding brake is spring-applied and electrically released — when the drive is enabled, the brake disengages to allow free rotation; when power is lost, the spring mechanism clamps the brake disc to hold the shaft stationary.
Installation Requirements:
- Mount on a rigid, flat surface using the standard flange interface to ensure proper alignment
- Connect the single cable system securely, ensuring proper shielding for EMC compliance
- Wire the brake control circuit to the designated drive outputs with correct voltage
- Ensure adequate ventilation around the motor housing for thermal management
- Verify the drive is configured for the P1/S1 encoder type
Usage Notes:
- The holding brake (B1) is designed for static load retention only — do not use it for dynamic braking or deceleration
- Verify the brake release voltage matches the drive output specification before commissioning
- Monitor motor temperature during continuous heavy-load operation
- Check brake gap and wear periodically if the brake is engaged frequently
- Do not exceed the permissible radial and axial shaft loads specified in the technical manual
- Handle with care to avoid electrostatic discharge damage to the encoder electronics