



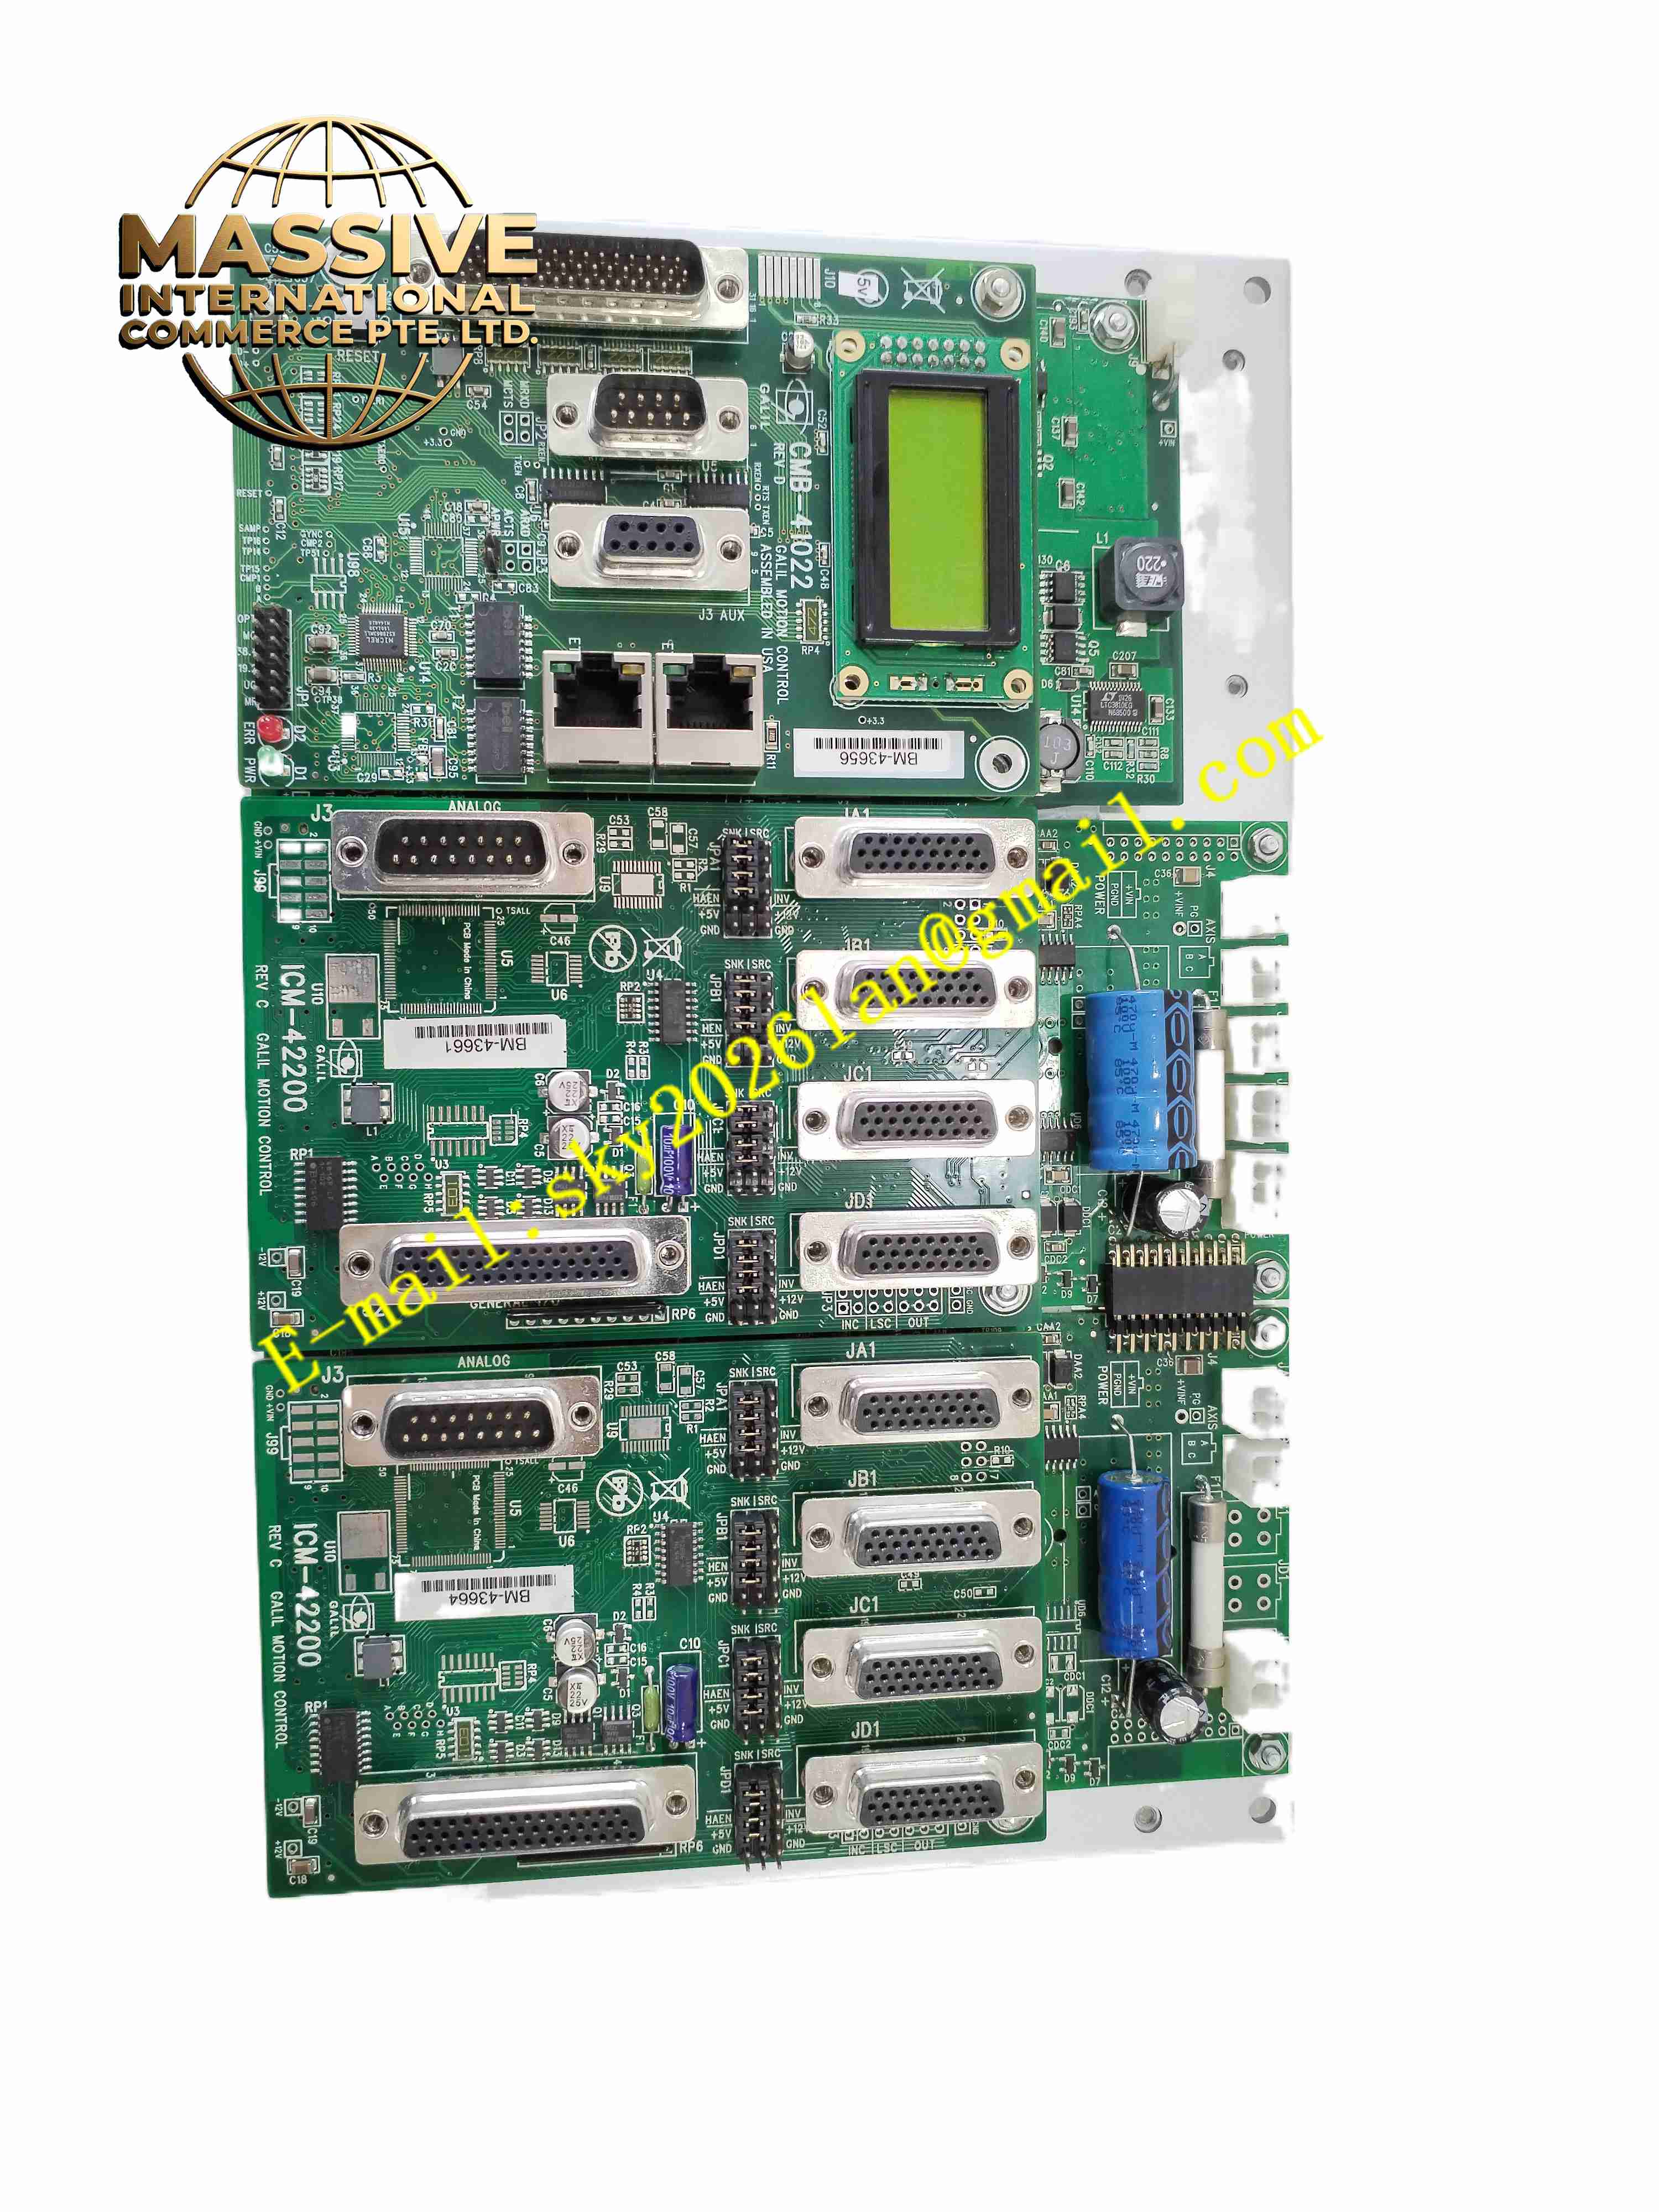
Description
Galil DMC-4080
Technical Specifications:
- Axis Quantity: 8 axes
- Servo Loop Update Time: 187.5μs for 8 axes
- Supported Motor: Brush servo, brushless servo, stepper motors
- Encoder: Quadrature encoder input for each axis
- Digital Input: 16 opto-isolated digital inputs
- Digital Output: 16 opto-isolated digital outputs, 500mA sourcing
- Extended I/O: 32 TTL digital I/O expandable
- Power Supply: 20V to 80V DC
- Communication: Ethernet and RS232
- Operating Temperature: -20°C ~ +65°C
- Storage Temperature: -40°C ~ +85°C
- Protection Grade: IP20
Function Features:
- Point-to-point positioning, linear and circular interpolation for multi-axis contouring
- Electronic cam, gantry synchronization, flying shear and master-slave following
- PID servo algorithm with velocity and acceleration feedforward
- Hardware limit, home and emergency stop input processing
- Onboard non-volatile memory for motion program storage
- High speed digital I/O for event triggered motion
- Oscillography function to capture motion waveform for tuning
- GDK software for axis configuration, auto-tuning and programming
Application Scenarios:
- Multi-axis gantry automation systems
- Large laser cutting and plasma cutting machines
- Packaging multi-station rotary equipment
- Semiconductor handling and inspection machines
- Multi-axis test rigs for industrial product testing
Material Composition:
- Housing: Cold rolled steel metal enclosure with black powder coating
- PCB: Multilayer FR4 fiberglass circuit board
- Control Core: High performance DSP motion processor
- Interface Components: Optocoupler isolation chips, differential line receivers
- Terminals: Screw copper alloy terminals
Structural Features:
- Panel mount metal casing
- Front panel LED indicators for power, communication and axis status
- Multiple separated terminal blocks for power, axis command, encoder and digital I/O
- Standard cabinet mounting dimensions
Working Principle: Motion program stored in onboard memory runs independently after power up. Controller generates motion profile for each axis and sends command signals to external servo amplifiers. Encoders return real-time position feedback. DSP executes closed-loop PID calculation for every axis to minimize position error. Digital I/O captures sensor signals and triggers motion actions. All motion data can be uploaded to PC via Ethernet for analysis.
Installation Requirements:
- Mount inside ventilated electrical cabinet
- Reserve clearance for heat dissipation
- Use shielded differential cables for encoder and command signals
- Route signal cables separately from high power motor cables
- Implement reliable protective grounding
Usage Notes:
- Configure axis mapping and encoder parameters before commissioning
- Perform PID auto-tuning for each axis to optimize dynamic performance
- Save complete program and parameter backup
- Do not exceed maximum 80V DC supply voltage
- Cut off power supply before opening enclosure







