



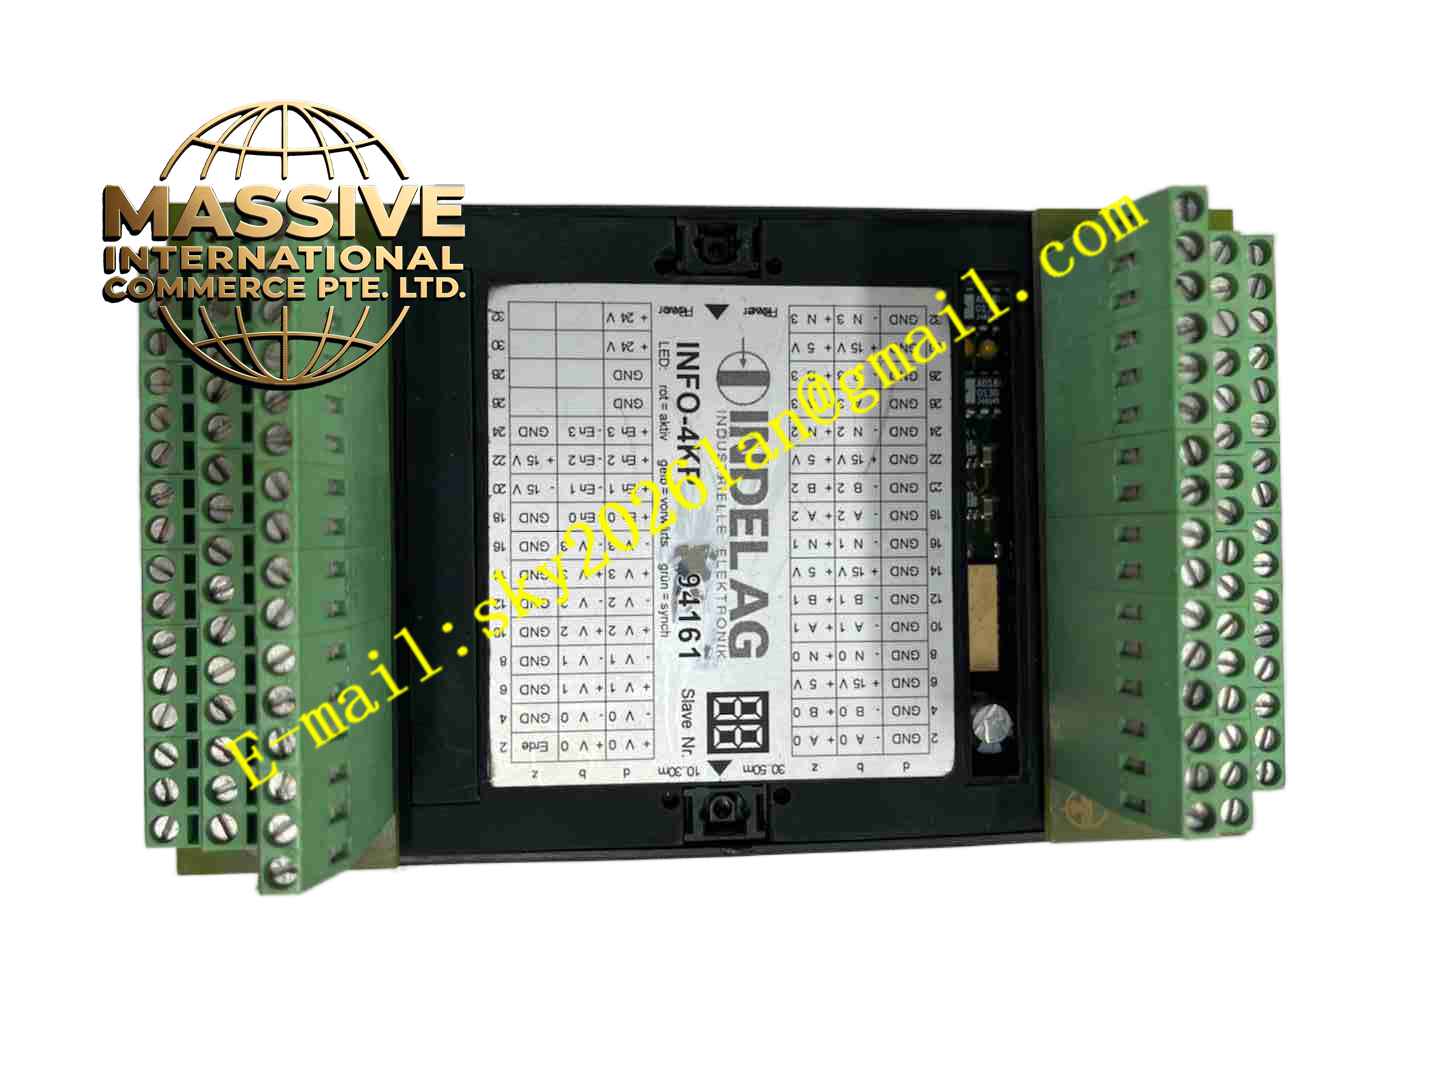
Description
INDEL INFO-4KP-94161
Technical Specifications
- Product Type: Multi-axis motion control processor board
- Fieldbus Interface: INDEL GinLink high speed real-time bus
- Bus Clock: 25 MHz, burst mode support, minimum latency 40 ns
- Axis Control Capacity: Multi-axis synchronous motion control
- Feedback Interface: Digital encoder input, analog sensor input
- Control Modes: Point to point positioning, linear interpolation, circular interpolation, electronic cam
- Mounting: Plug-in board for industrial PC or INDEL control rack
- Protection Rating: IP00 for bare board, IP20 when installed in cabinet
- Operating Temperature: 0 °C to +55 °C
- Humidity: 5 % to 90 %, non-condensing
- Weight: 0.45 kg
Functional Features
- High speed real-time calculation of multi-axis motion trajectory and interpolation.
- GinLink high speed fieldbus connects distributed COP I/O and servo drive modules.
- Electronic cam function realizes synchronous motion between multiple axes.
- Support linear and circular interpolation for continuous contour machining.
- Fast digital input capture for position latch and home reference detection.
- Built-in motion sequence interpreter executes machine program.
- Hardware watchdog monitors processor operation and triggers safety stop on failure.
- Parameter memory stores axis mechanical configuration and control loop gains.
- Host PC communication interface transfers machine program and status data.
- Conformal coating protects PCB for industrial vibration environment.
Application Scenarios
- Laser cutting and laser micromachining equipment motion control
- High speed packaging machine multi-axis synchronization
- CNC grinding and milling machine contour control
- Semiconductor handling pick and place automation
- High precision test bench multi-axis motion system
Material Composition
- Main PCB: FR4 high reliability printed circuit board with conformal coating
- Main processor: High speed floating point motion control DSP
- Bus transceiver: GinLink high speed differential bus chips
- Memory: Industrial RAM and non-volatile flash memory
- Connector: Gold plated edge connectors and signal terminals
- Signal conditioning: High speed differential line receiver chips
Structural Characteristics
- Flat rectangular plug-in printed circuit board.
- Edge connector for rack or industrial PC backplane connection.
- Onboard GinLink bus connector for distributed I/O modules.
- Internal circuit layout isolates high speed differential bus from low speed logic circuit.
- No built-in fan, passive convection cooling.
Working Principle Host computer downloads machine motion program to INFO-4KP-94161 board. The DSP parses program and calculates target position for each axis in real-time interpolation cycle. Motion commands transmit to servo drives via GinLink bus. Encoder feedback signals return to the board for closed-loop position comparison. The controller adjusts command value according to position error. Digital input signals capture limit switch and home signal, and trigger safety stop when interlock condition activates. Watchdog continuously monitors processor operation state.
Installation Requirements
- Insert the board into designated slot of industrial PC or INDEL control rack.
- Use shielded differential cable for GinLink bus connection.
- Separate motion bus cable from high power motor cables.
- Complete protective earth connection for rack.
- Execute axis mechanical parameter setup and servo loop tuning.
- Test home, limit switch and emergency stop interlock circuit.
- Verify multi-axis synchronous interpolation performance before full operation.
Usage Notes
- Do not operate board outside specified operating temperature range.
- Keep cabinet free of conductive dust and corrosive gas.
- Backup motion program and axis parameters before firmware upgrade.
- Disconnect rack power before installing or removing board.
- Use anti-static wristband when handling the board.
- Replace board immediately when permanent bus communication or motion calculation fault occurs.







