Description
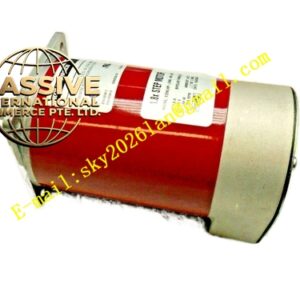
Kollmorgen H32NCHA‑LNN‑NS‑00
Technical Specifications: NEMA34 standard frame size; continuous stall torque 3.2 N·m; peak torque 6.4 N·m; rated speed 3000 rpm; maximum mechanical speed 4500 rpm; phase current 5.0 A per phase; 230 VAC winding rating; integrated incremental‑encoder feedback; insulation‑class B; protection‑rating IP40; non‑brake version; shaft with keyway; working ambient‑temperature‑range‑20 °C‑40 °C; storage‑temperature‑range‑30 °C‑85 °C; weight 3.3 kg.
Functional Features: High‑torque‑density hybrid‑brushless design; low‑cogging‑torque for smooth‑low‑speed‑operation; NEMA34 standard‑mounting‑dimensions for direct stepper‑motor replacement; incremental‑encoder closed‑loop‑feedback eliminates step‑loss phenomenon; high‑strength bearing‑assembly for long‑term continuous‑operation; mechanical‑structure adapted for industrial‑vibration‑environment.
Application Scenarios: Retrofit‑upgrade of original NEMA34 stepper‑motor‑based equipment; packaging‑automation‑machinery; material‑processing positioning‑axes; laboratory‑automation‑positioning‑platforms; small‑size automated‑production‑equipment.
Performance Parameters: Torque‑ripple below 4 %; encoder‑position‑resolution 2000 counts per revolution; insulation‑resistance greater than 100 MΩ; withstand‑voltage 1500 VAC for one‑minute test.
Material Composition: Aluminum‑alloy motor‑housing; silicon‑steel stator‑rotor‑laminations; rare‑earth‑permanent‑magnet rotor; high‑strength‑alloy‑steel output‑shaft; fluorine‑rubber shaft‑sealing‑ring; high‑temperature‑resistant magnet‑wire‑winding; rear‑end incremental‑encoder‑assembly.
Structural Features: Cylindrical NEMA34‑flange‑motor‑structure; rear‑end incremental‑encoder‑feedback‑housing; side‑mount terminal‑box for power‑and‑feedback‑wiring; front‑end keyed‑output‑shaft; sealed‑bearing‑chamber; no built‑in electromagnetic‑brake‑assembly.
Working Principle: Three‑phase alternating‑current from servo‑drive generates rotating‑magnetic‑field inside motor‑stator. Permanent‑magnet‑rotor follows rotating‑magnetic‑field rotation and outputs mechanical‑torque. Rear‑end incremental‑encoder detects real‑time rotor‑angle and rotational‑speed, and transmits feedback‑signal back to servo‑drive for closed‑loop commutation and position‑velocity‑control. Closed‑loop‑control eliminates open‑loop stepper‑motor step‑loss risk.
Installation Requirements: Mount rigidly via NEMA34 flange‑surface; maintain strict coaxiality between motor‑shaft and load‑coupling; motor‑housing protective‑earth must connect to cabinet grounding‑bar; keep ventilation‑space around motor‑housing; avoid installing adjacent to high‑heat‑heat‑sources.
Usage Notes: Do not operate beyond maximum‑mechanical‑rotational‑speed; avoid hammer‑impact on motor‑output‑shaft; shielded‑cables must be adopted for power‑and‑encoder‑feedback‑wiring; prevent metal‑dust‑accumulation on motor‑housing; spare‑part‑replacement must verify encoder‑wiring‑definition and motor‑winding‑parameter‑consistency.