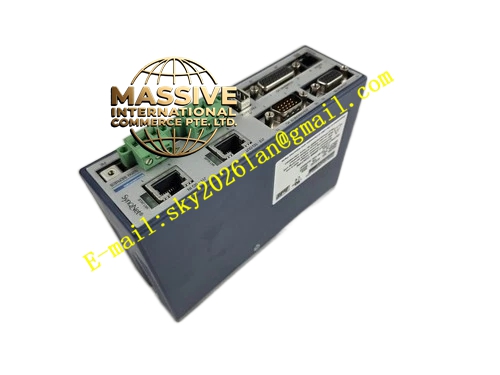
Description
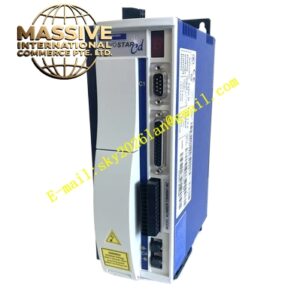
Kollmorgen S20330-CNS
Technical Specifications
- Input Voltage: 90 VDC nominal (20-90 VDC range)
- Continuous Output Current: 3 Amps RMS
- Peak Output Current: 9 Amps RMS
- Communication Interface: CANopen fieldbus with DS301 and DSP402 profiles
- Node Type: Profile Node with CANopen protocol
- Control Logic Supply: 10 to 26 VDC
- Feedback Support: Resolver, incremental encoder, SFD
Functional Features
- Full CANopen communication with SDO, PDO, and NMT services
- CiA DSP402 device profile for drives and motion control
- Synchronized motion via CANopen SYNC objects
- Electronic gearing via CANopen command objects
- 256 motion tasks storable in drive memory
- 16 homing methods configurable over CANopen
- Velocity, position, and torque mode operation selectable via object dictionary
- Emergency object generation for fault reporting
- Heartbeat and node guarding for network supervision
Application Scenarios
- CANopen-based machine control systems
- Distributed automation architectures
- Packaging machinery with centralized PLC control
- Material handling conveyors with networked drives
- Agricultural and mobile equipment with CAN bus systems
- Renewable energy tracking systems
Performance Parameters
- CANopen communication cycle time compatible with motion control requirements
- Real-time position and velocity command execution over fieldbus
- High-speed PDO mapping for rapid data exchange
- Deterministic motion performance within CANopen network constraints
Structural Characteristics
- Standard S200 series mechanical package with CANopen connector
- Dual RJ45 or 9-pin D-sub CAN bus connector
- Termination resistor switch for network termination
- Same compact form factor as other S200 variants
Working Principle The drive operates as a CANopen slave node on an industrial control network. The host controller (PLC or motion controller) sends motion commands, parameters, and control words via CANopen service data objects and process data objects. The internal processor interprets these commands and executes the corresponding motion profiles while reporting status, actual position, and velocity back to the network. Current, velocity, and position loops are closed locally within the drive for optimal performance.
Installation Requirements
- Connect to CANopen network with proper cable shielding and termination
- Configure node address via rotary switches or software
- Ensure CAN bus baud rate matches network configuration
- Provide isolated 24VDC logic power if required by network topology
Operating Precautions
- Verify CANopen node ID does not conflict with other network devices
- Monitor CAN bus error counters for communication integrity
- Configure emergency stop behavior via CANopen fault reaction parameters
- Maintain network cable integrity to prevent communication dropouts