Description
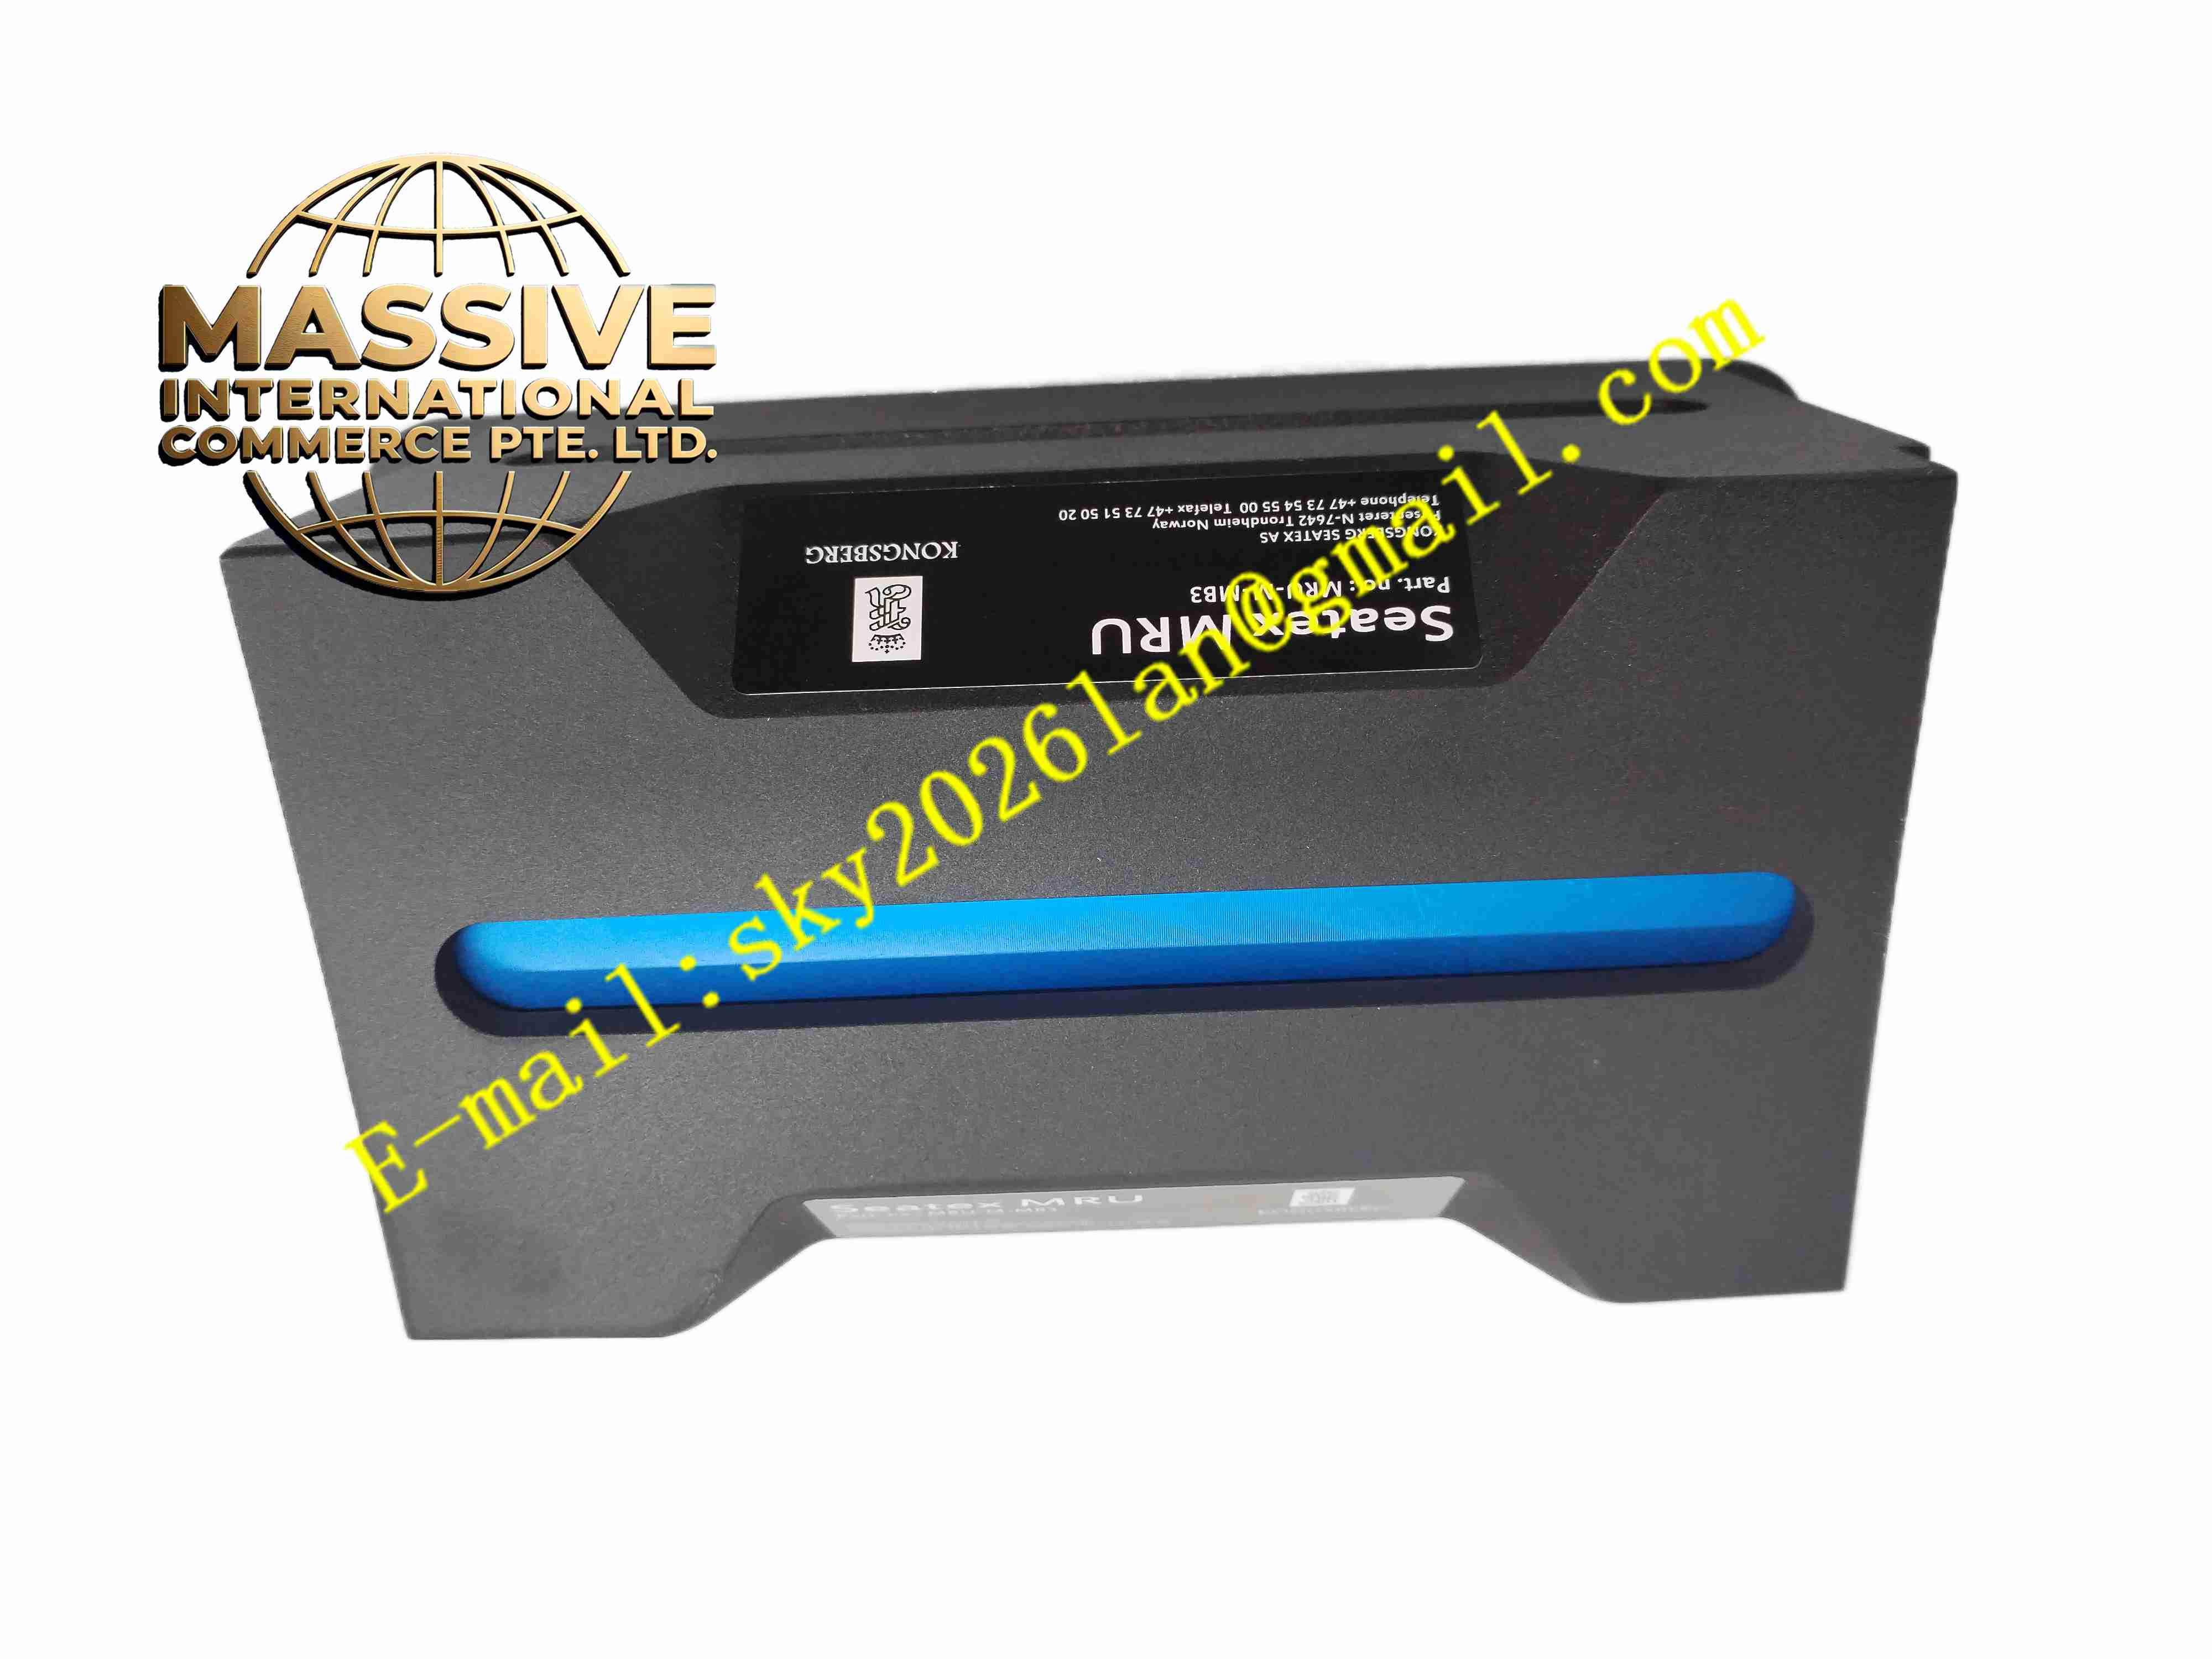
KONGSBERG MRU-M-MB3
Technical Specifications
Manufacturer: Kongsberg
Product type: motion reference unit
Measured axes: heave, pitch, roll, heading, and acceleration
Sensor technology: inertial measurement with gyroscopes and accelerometers
Output data: heave, pitch, roll, heading, accelerations, and motion parameters
Interface type: marine industrial communication interface
Mounting: fixed marine installation
Power supply: marine DC power supply as defined by the product manual
Environmental rating: marine-grade sealed enclosure
Operating environment: offshore vessels, platforms, and subsea support systems
Detailed electrical and mechanical data: to be confirmed from the official Kongsberg MRU-M-MB3 datasheet
Functional Features
Three-axis motion measurement
Heave, pitch, and roll output
Heading reference support
Acceleration measurement
Motion compensation data provision
High-update-rate motion output
Marine-grade environmental protection
Continuous online operation
Integration with DP and crane control systems
Suitable for subsea and offshore applications
Application Scenarios
Dynamic positioning systems
Offshore crane motion compensation
Subsea ROV and AOV operations
Marine survey and positioning
Remotely operated vehicle support
Offshore installation vessels
Pipe and cable laying systems
Marine automation and control
Helideck motion monitoring
Vessel motion reference for navigation and control systems
Performance Parameters
Measurement outputs: heave, pitch, roll, heading, acceleration
Motion update rate: high-rate real-time output
Accuracy: marine-grade inertial measurement performance
Stability: continuous operation in dynamic marine conditions
Environmental robustness: designed for offshore and marine use
Integration: compatible with Kongsberg and third-party marine control systems
Material Composition
Marine-grade sealed enclosure
Inertial sensor assembly with gyroscopes and accelerometers
Internal processing electronics
Marine communication interface circuitry
Power input conditioning circuit
Connector interface for marine cabling
Grounding and shielding hardware
Corrosion-resistant mounting hardware
Protective sealing and gasketing
Structural Features
Compact marine enclosure
Fixed mounting interface
Marine cable connectors
Status indicator LEDs
Sealed housing for moisture and salt environment protection
Robust mechanical construction
Label plate with model and serial number
Designed for permanent vessel or platform installation
Working Principle
The MRU-M-MB3 measures angular rate and linear acceleration using internal inertial sensors. The measured motion data is processed to calculate vessel heave, pitch, roll, heading, and acceleration. The unit outputs motion reference data in real time to connected systems such as dynamic positioning controllers, crane controllers, subsea positioning systems, or motion compensation units. Because it relies on inertial sensing, it can provide motion data even when external positioning signals are degraded.
Installation Requirements
Install in a rigid and stable location on the vessel or platform
Align the unit according to the vessel reference axes
Secure mounting to minimize local vibration and shock
Connect power according to the Kongsberg wiring diagram
Connect communication interfaces to the host control system
Perform alignment and calibration after installation
Ensure cable glands and connectors are properly sealed
Maintain clear access for status indicators and maintenance
Usage Precautions
Verify the exact MRU-M-MB3 datasheet before integration
Do not install in locations with excessive local vibration
Ensure correct mechanical alignment for heading and motion reference
Keep connectors sealed against moisture and salt spray
Perform calibration after mechanical installation or realignment
Check status indicators and diagnostic outputs regularly
Use only approved Kongsberg cables and accessories