Description
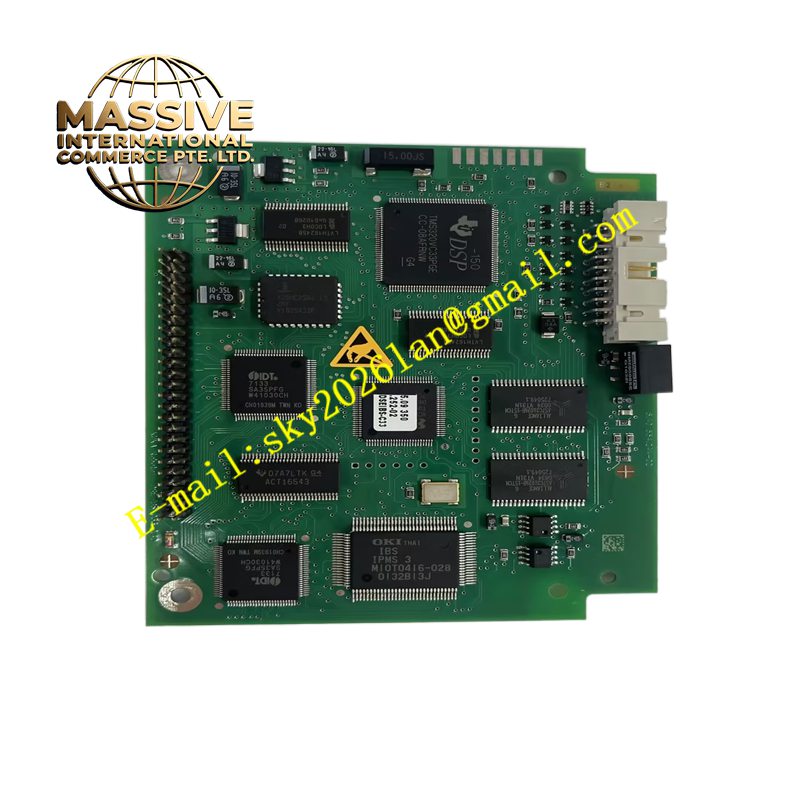
KUKA 00-117-336 0018
Technical Specifications Rated voltage matches KUKA robot drive bus voltage; built-in high-resolution encoder for commutation and position feedback; integrated holding brake; IP protection grade for robot joint installation; wide operating temperature range for workshop conditions; designed to withstand frequent acceleration and deceleration cycles.
Functional Features Provides dynamic torque output for robot joint rotation. The built-in brake locks the shaft when power is removed to prevent axis sagging. The encoder sends real-time position and speed data back to the robot controller for closed-loop motion control. The compact form factor fits inside robot joint housings. It supports high acceleration profiles required for material handling, welding and assembly tasks.
Application Scenarios KUKA six-axis industrial robots used in automotive welding, component assembly, material handling, palletizing and machine tending.
Performance Parameters High torque density; low torque ripple during rotation; stable encoder signal output under vibration; long rated service life under cyclic loading.
Material Composition Housing made of high-strength aluminum alloy; stator core uses silicon steel laminations; rotor contains high-performance permanent magnets; output shaft is alloy steel with surface quenching; internal winding uses high-temperature magnet wire; encoder assembly enclosed in plastic and metal shielding shell.
Structural Characteristics Compact cylindrical structure with flange mounting interface; rear section accommodates encoder and brake assembly; output shaft equipped with precision sealing rings; dedicated power and feedback connectors fixed on the motor body.
Working Principle The servo drive outputs three-phase alternating current to the motor stator windings, generating a rotating magnetic field. The magnetic field interacts with permanent magnets on the rotor to produce torque and drive shaft rotation. The integrated encoder captures angular position and velocity signals and transmits them to the robot controller for closed-loop adjustment. When power cuts off, the spring-actuated holding brake engages and locks the rotor shaft.
Installation Requirements Install inside the corresponding robot joint housing. Align the mounting flange precisely and tighten fasteners to specified torque. Connect power cable and encoder feedback cable to designated terminals. Verify encoder offset parameters in the KUKA robot controller after installation.
Precautions for Use Do not apply excessive impact force to the shaft and encoder end during handling. Ensure cable connectors are fully seated and locked. Avoid operating the motor beyond rated speed and torque limits. The holding brake is only for static locking and cannot serve as a dynamic stopping brake. Do not disassemble the encoder module without professional tools.