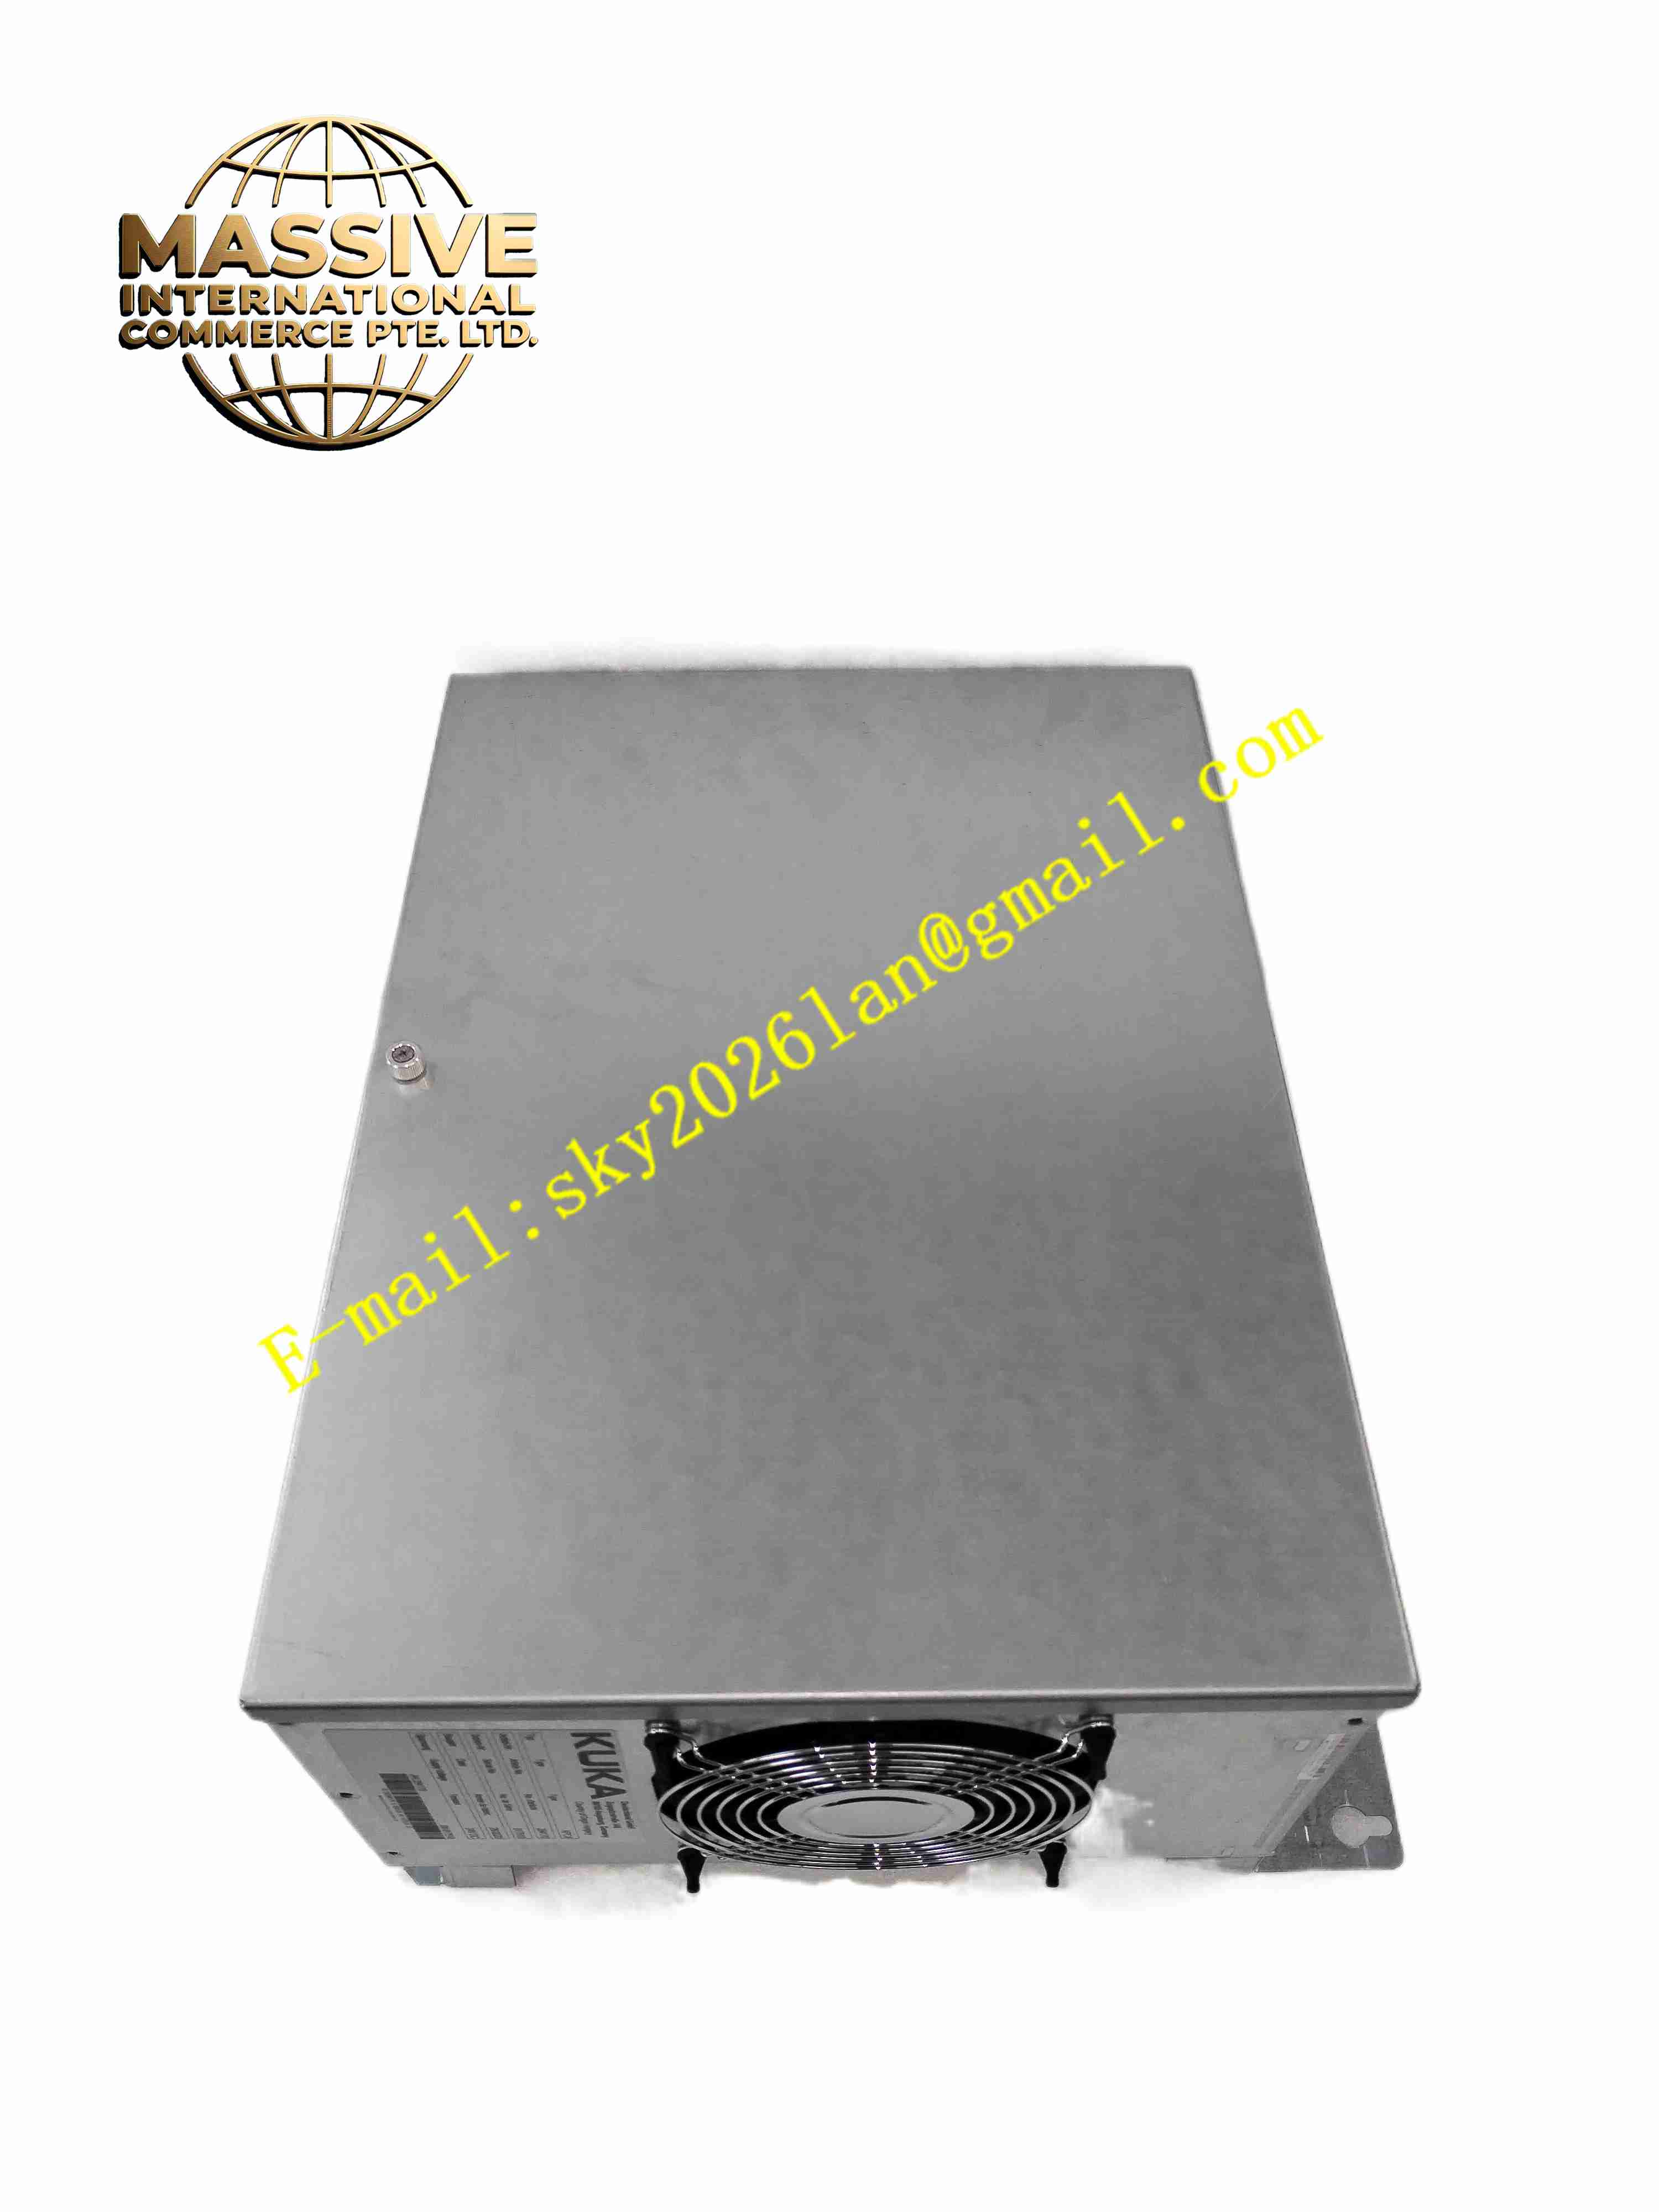
Description
KUKA KPC4 00-284-170
Technical Specifications Industrial embedded PC hardware; Intel multi-core processor; Onboard SSD for system and robot program storage; Multiple Gigabit Ethernet interfaces; USB and serial peripheral ports; Internal real-time robot bus interface; Powered by cabinet internal DC power supply.
Functional Features Robot trajectory planning and inverse kinematics calculation; KUKA robot program parsing and cyclic execution; Integrated soft PLC function for peripheral equipment logic control; Real-time communication with KUKA servo drive group; Historical alarm and robot production data storage; Support robot safety logic coordination; Ethernet connection to upper production MES system; Hardware watchdog for system fault reset.
Application Scenarios Automotive welding and handling robot; Industrial robot assembly cell; Robot polishing and grinding workstation; Logistics robotic palletizing system; KUKA KR C4 robot control cabinet.
Performance Parameters Operating ambient temperature 5℃ to +55℃; Storage temperature -40℃ to +85℃; Relative humidity 10% to 90%, no condensation; Industrial vibration resistance meets robot control cabinet specification.
Material Composition Metal alloy sealed housing; Multi-layer industrial motherboard; High-performance processor chip; Solid-state storage module; Aluminum alloy heat sink; Ethernet isolation transformers; Gold-plated internal bus connectors; Status LED indicators.
Structural Characteristics Compact box type unit installed inside KR C4 control cabinet; Internal partition layout for high-speed computing circuit and peripheral interface circuit; Front panel equipped with LED status indicators and service maintenance interface; Fixed mounting holes for cabinet installation.
Working Principle DC power supply supplies power to KPC4 unit. Industrial processor loads KUKA robot operating system and user robot program. It completes trajectory planning and generates motion command, transmits command to KSD series servo drives via real-time bus. It reads servo feedback position data to realize closed-loop robot motion control. It runs PLC logic and uploads robot running data to HMI and upper MES system simultaneously. Hardware watchdog monitors system running state.
Installation Requirements Cut off robot cabinet main power before replacement. Wear anti-static wristband to install KPC4 unit into cabinet mounting position, tighten fixing screws. Connect internal bus, Ethernet and power wiring. Restore robot system image and robot program after power-on, execute robot axis reference calibration and safety circuit verification. Keep cabinet cooling fan operating normally.
Usage Notes Backup robot program and system configuration before hardware replacement. Do not open sealed metal housing arbitrarily. Prevent scratch on SSD storage module. Keep cabinet internal ventilation to avoid overheating. Do not hot swap the KPC4 unit during robot running.