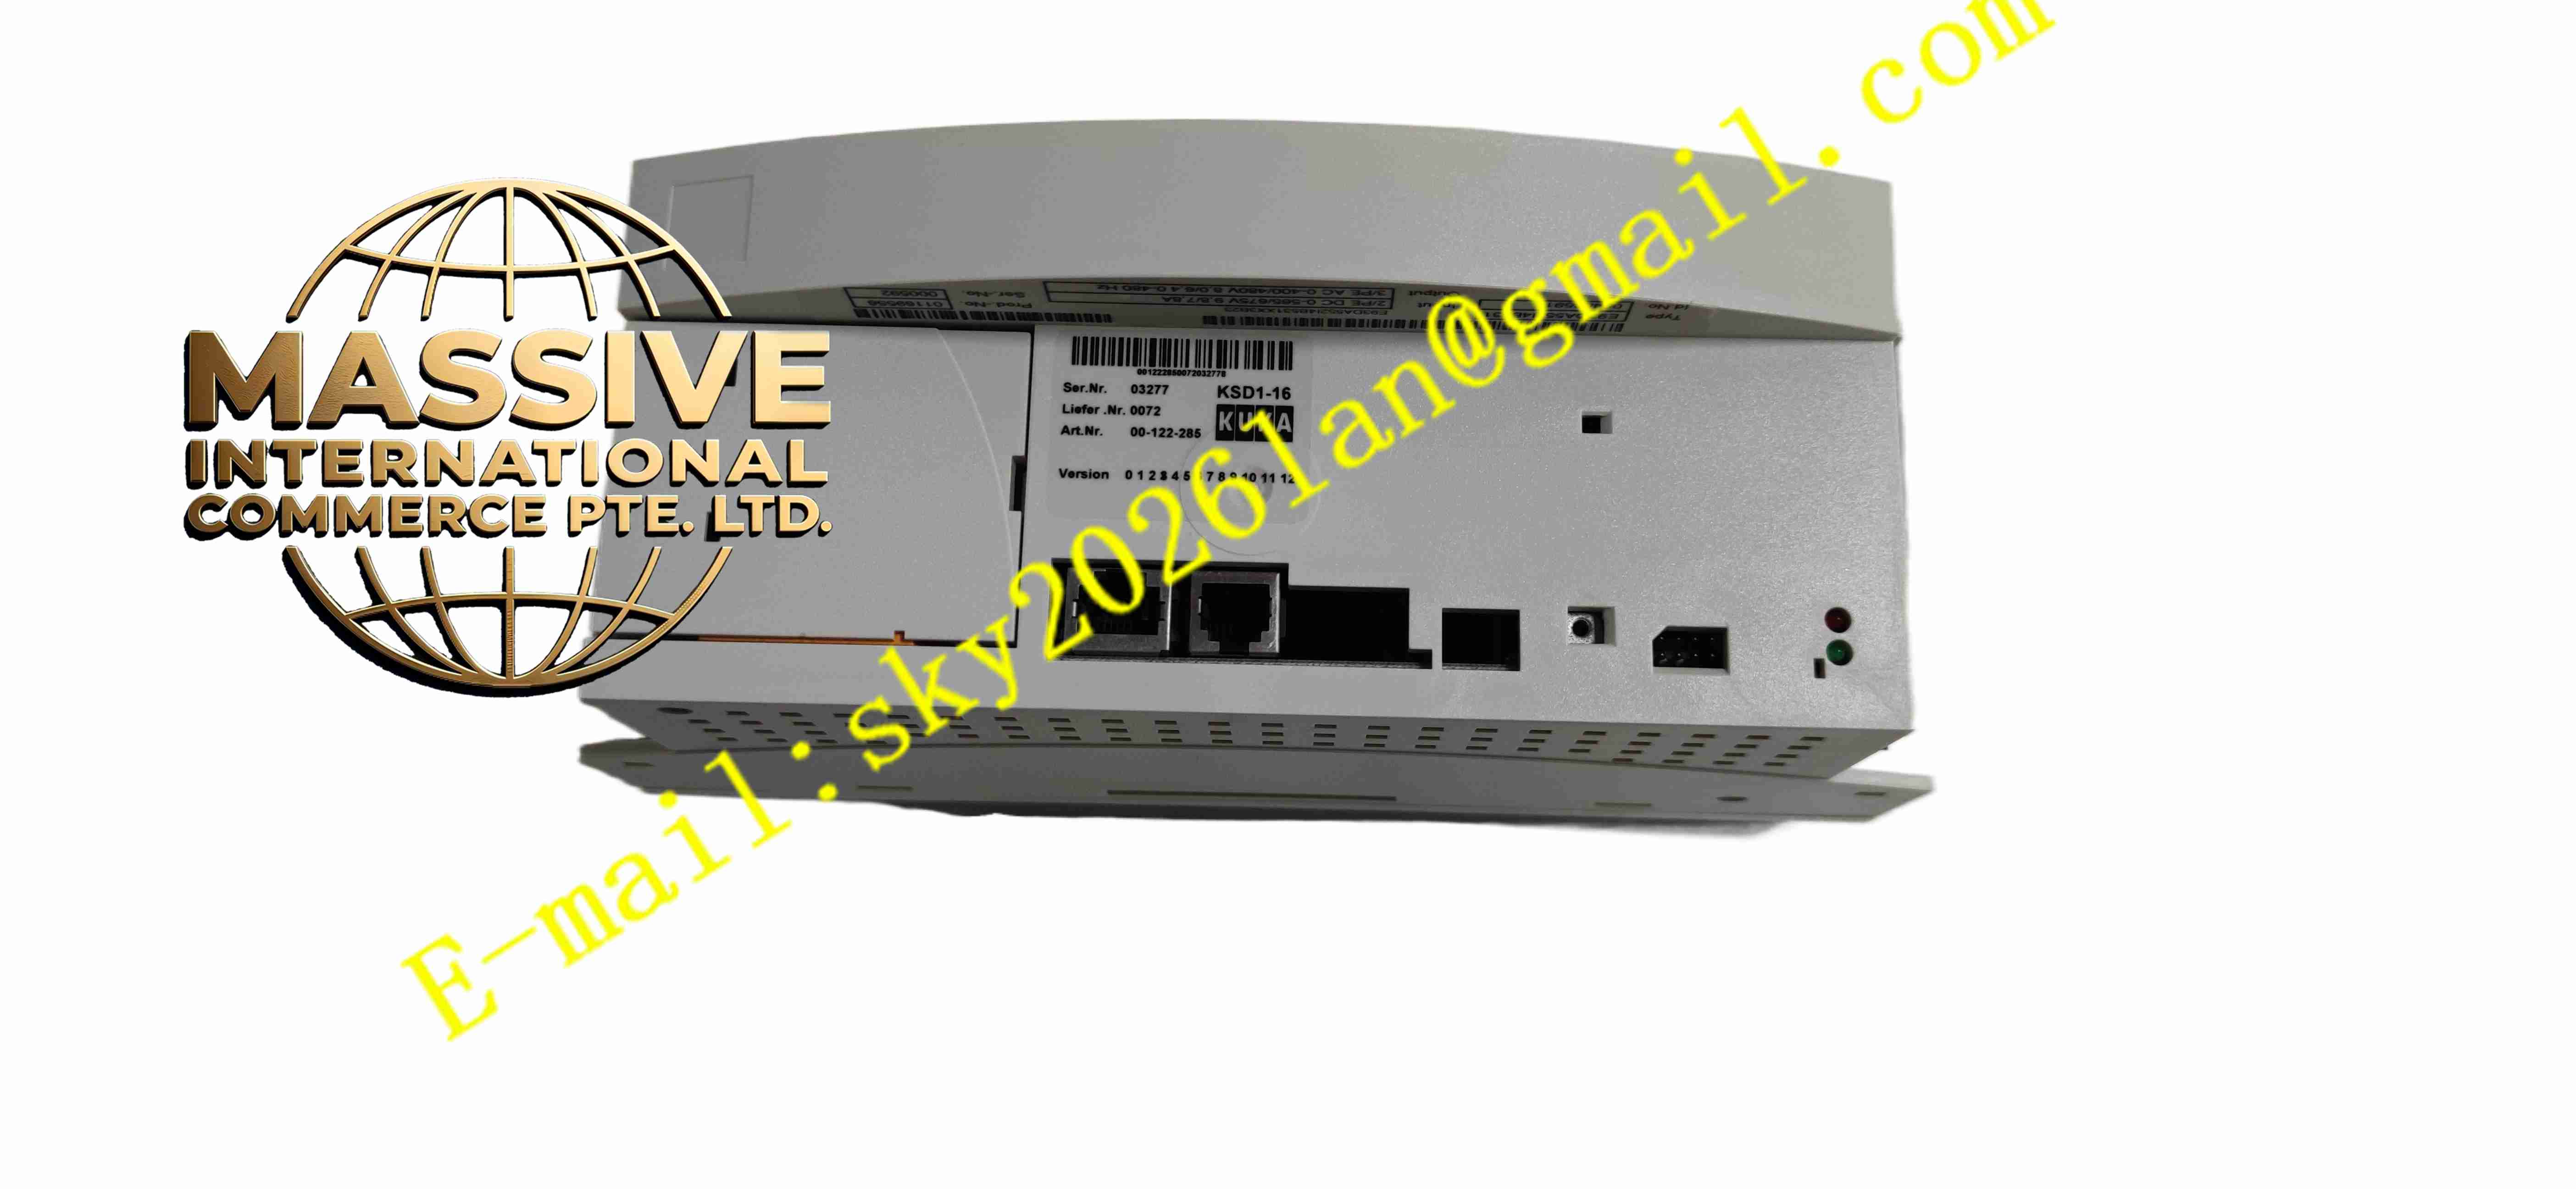
Description
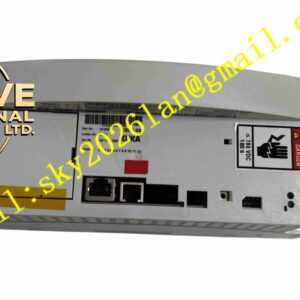
KUKA KSD1-16
Technical Specifications Single axis drive; Input DC bus voltage; Rated continuous output current 16A; Support resolver or incremental encoder feedback; KUKA internal real-time servo bus; Integrated STO safe torque off safety function; Protection class IP20.
Functional Features Closed-loop position, speed and torque control for robot servo axis; STO safe torque off safety function for robot safety circuit; Built-in over-current, over-voltage, under-voltage, over-temperature, motor stall protection; Encoder/resolver signal acquisition and feedback; Real-time bus communication with KPC4 controller; Internal fault code storage; Parameter non-volatile storage.
Application Scenarios KUKA KR C4 medium payload robot single axis drive; Automotive welding robot joint control; Robot handling and palletizing axis control; Robot auxiliary servo axis in automated production line.
Performance Parameters Operating ambient temperature 0℃ to +55℃; Storage temperature -40℃ to +85℃; Relative humidity 5% to 90%, no condensation; Meet robot functional safety requirements.
Material Composition Metal alloy housing with integrated heat sink; Multi-layer power PCB; IGBT power module; DSP motion control chip; Current sampling sensors; Filter electrolytic capacitors; Screw power and signal terminals.
Structural Characteristics Vertical compact rack-mounted module; Power terminals on lower side, encoder and bus signal terminals on upper side; Internal physical separation of high-power circuit and weak signal control circuit; Rear side integrated heat sink for forced air cooling.
Working Principle DC bus power enters the servo drive. DSP chip receives real-time motion command from KPC4 controller via internal bus, generates PWM signal to drive IGBT power module, outputs variable frequency three-phase AC to robot servo motor. Encoder or resolver feeds back motor position signal back to drive, forming closed-loop motion control. Protection circuit continuously monitors voltage, current and temperature, cuts off power output immediately when fault occurs. STO circuit safely interrupts torque output in safety interlock event.
Installation Requirements Mount the drive on KR C4 cabinet rack and lock module buckle. Keep enough air flow through heat sink. Use shielded cable for motor power wire and encoder wire, separate signal cable and power cable. Complete protective earthing of metal housing. Power on, execute motor parameter identification and test STO safety function.
Usage Notes Wait for DC bus capacitor full discharge before opening housing or disconnecting wiring. Do not run the drive without motor connected. Clean heat sink dust periodically. Backup drive axis parameters before replacement. Never modify internal power components.