



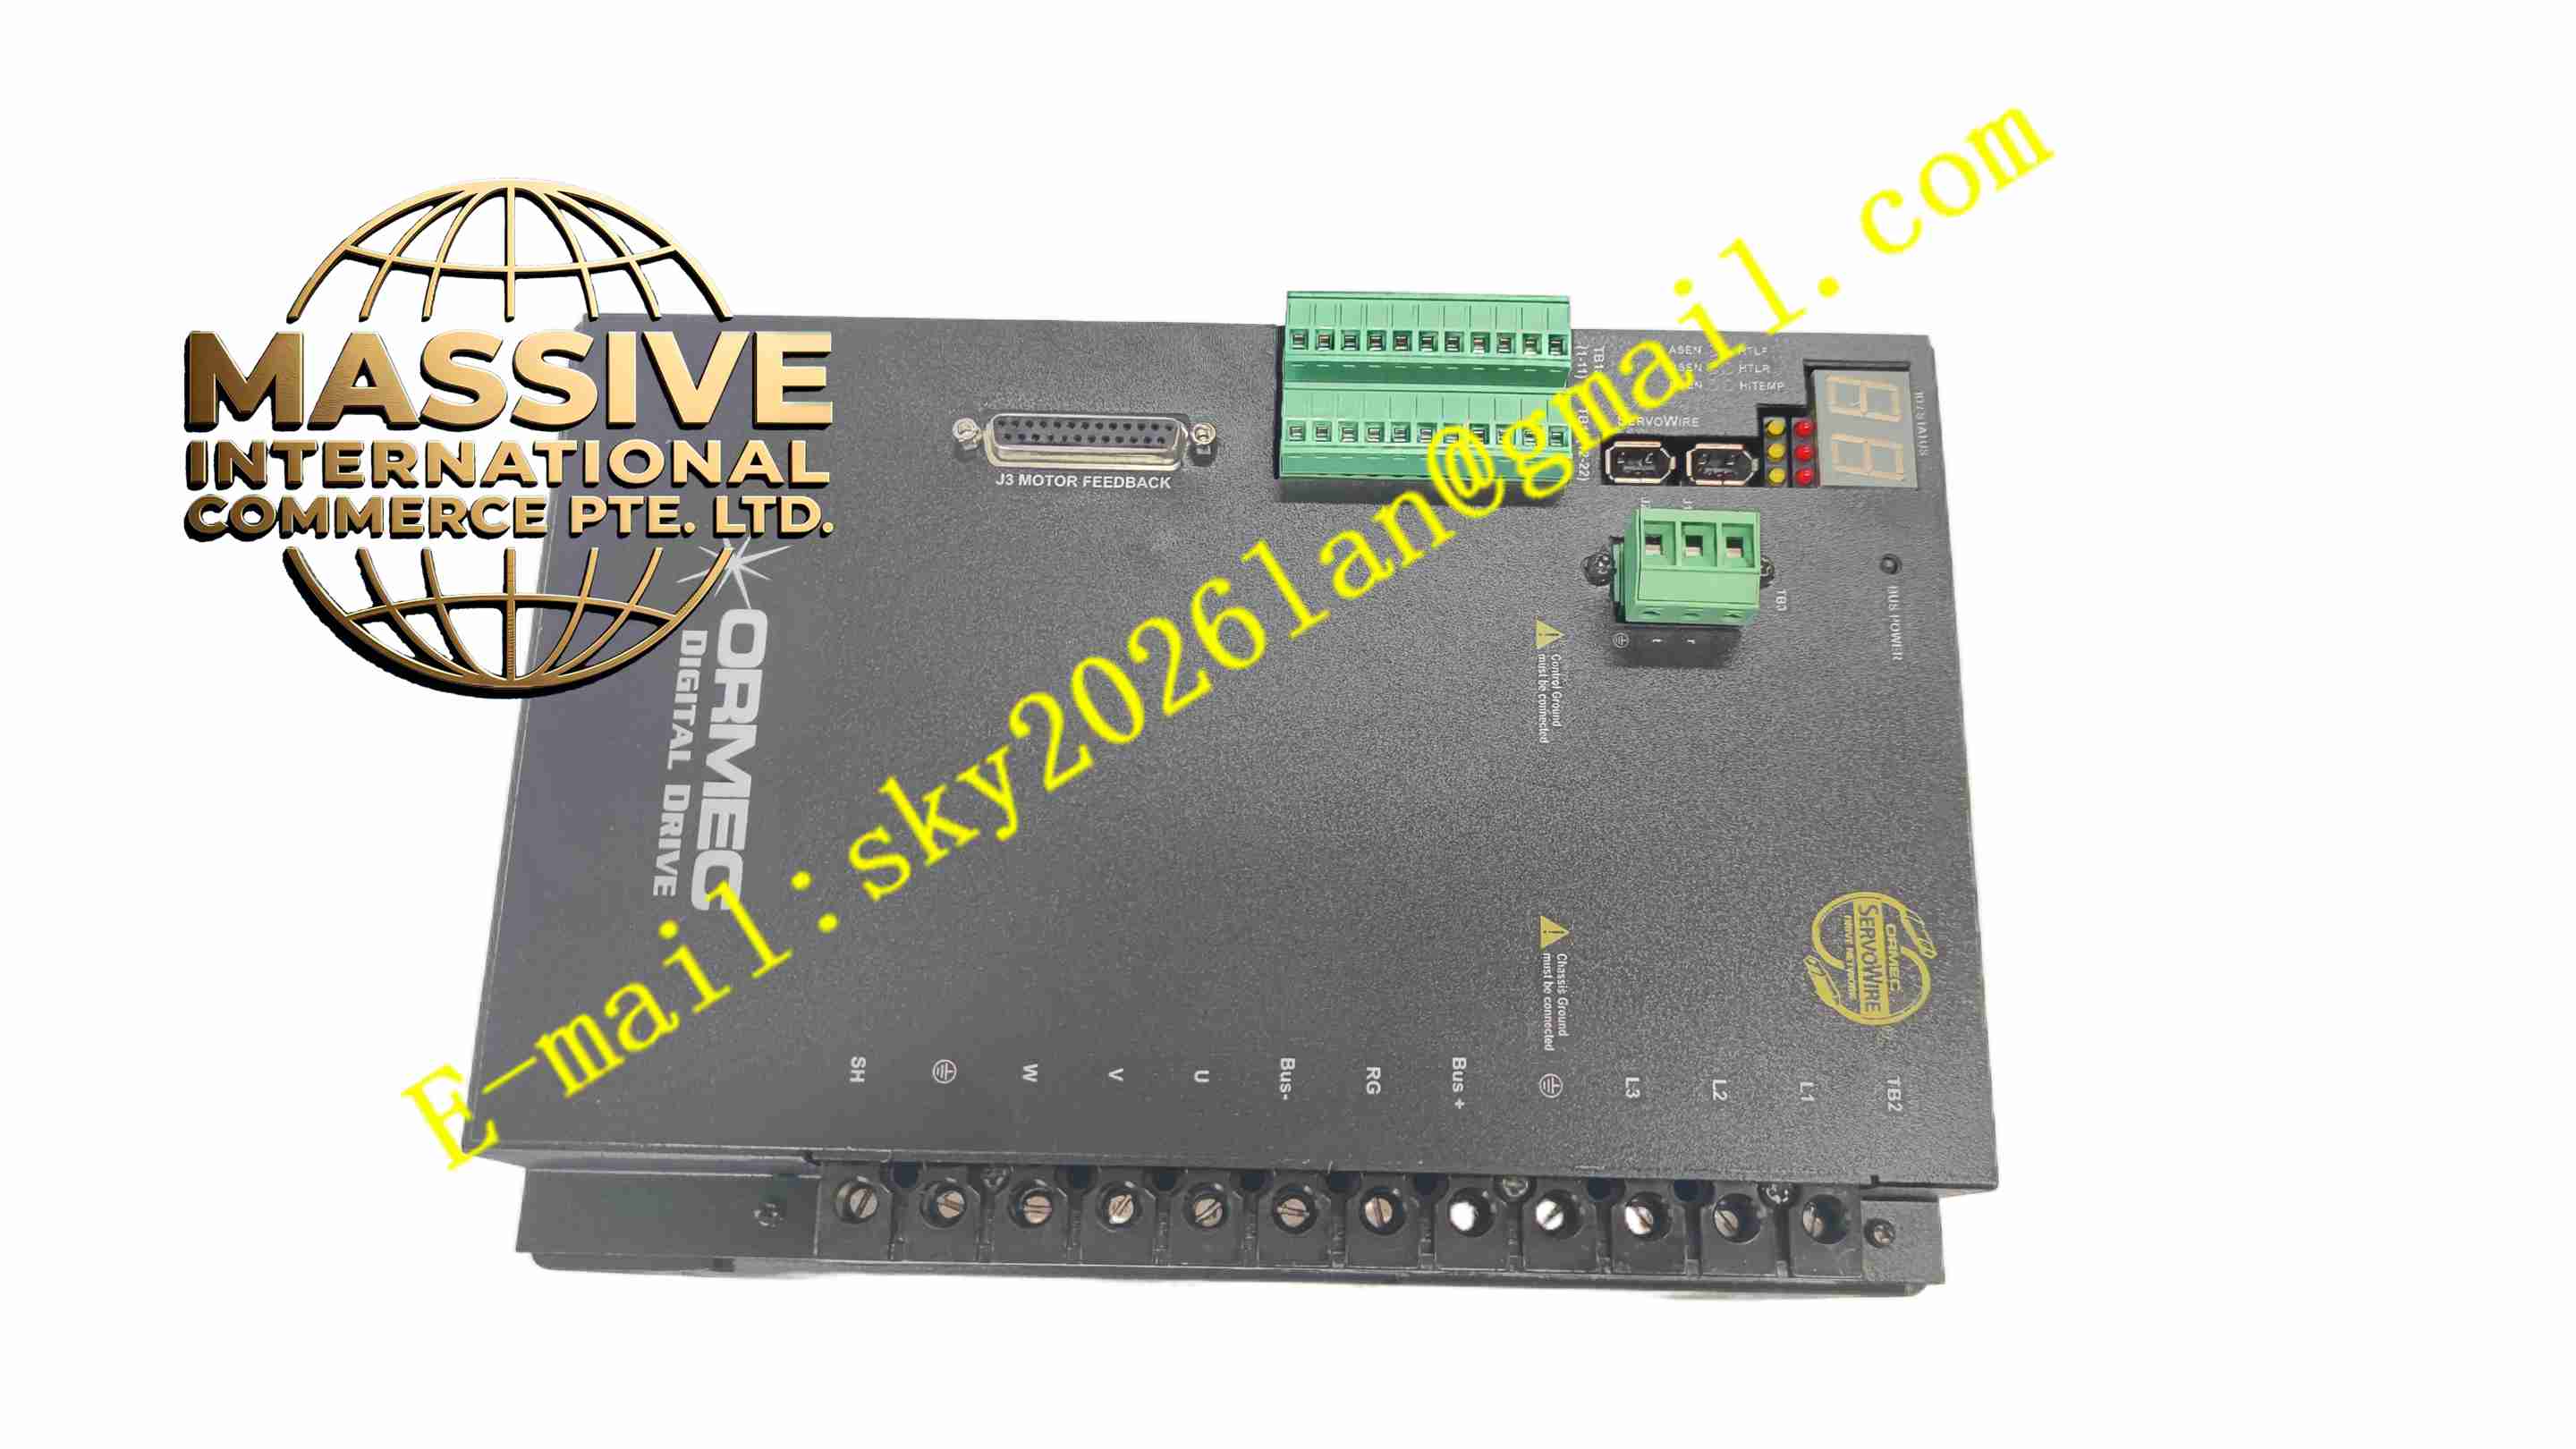
Description
ORMEC SAC-SW235EB
Technical Specifications Brand: ORMEC Model: SAC-SW235EB Rated Output Power: 235 W Input Voltage: 200 VAC to 480 VAC Control Method: Field oriented vector control Communication: EtherCAT, RS485 Operating Temperature: -10°C to +40°C Protection Grade: IP65 Weight: 1.6 kg
Functional Features High efficiency power conversion reduces heat generation during continuous operation. Vector control delivers constant torque across full speed range. EtherCAT real-time bus for multi-axis synchronization. Built-in complete fault protection including overcurrent, overvoltage, overtemperature and encoder fault. Programmable digital inputs and outputs for limit switch and machine interlock signals. PC software for parameter configuration, auto tuning and fault diagnosis. Sealed enclosure resists dust and splash in machine environment.
Application Scenarios Packaging automation production line, conveyor positioning control, medical processing equipment, semiconductor handling mechanism, automated test equipment, small robotic motion axes.
Performance Parameters High power conversion efficiency reduces energy consumption. Fast current loop response for dynamic load changes. Rapid fault detection for wiring and hardware abnormality. Real-time bus synchronization maintains precise multi-axis coordination. Long continuous operating life under cyclic machine load.
Material Composition Housing: Die cast aluminum alloy sealed housing with surface anti-corrosion treatment. PCB: FR4 multilayer power and control PCB with conformal coating. Core Components: IGBT power module, DSP motion processor, optocoupler, surge protection components. Wiring Interface: Industrial sealed circular connectors.
Structural Features Integrated sealed aluminum housing. All external connections use waterproof circular connectors. Internal metal shielding isolates high power circuit from encoder and communication signals. Heat transfer structure dissipates power loss through aluminum housing surface.
Working Principle AC supply converts to DC bus by internal rectifier circuit. Motion processor receives command signal from host controller over EtherCAT or RS485. Vector control algorithm generates PWM drive signal for IGBT module to drive servo motor. Encoder feedback closes speed and position loop. Internal monitoring circuit continuously measures electrical and thermal conditions and stops output immediately on fault event.
Installation Requirements Mount module firmly on rigid metal mounting plate for heat dissipation. Use shielded motor and encoder cables, properly terminate cable shield. Separate power wiring from low voltage signal wiring. Configure motor specifications and complete servo auto tuning after wiring. Check all connector sealing gaskets for full environmental protection.
Usage Notes Do not apply input voltage beyond rated range. Inspect connector seals regularly, replace damaged gaskets. Avoid liquid splash directly on module housing. Backup parameters before changing configuration. Check encoder wiring continuity before powering up system.







