



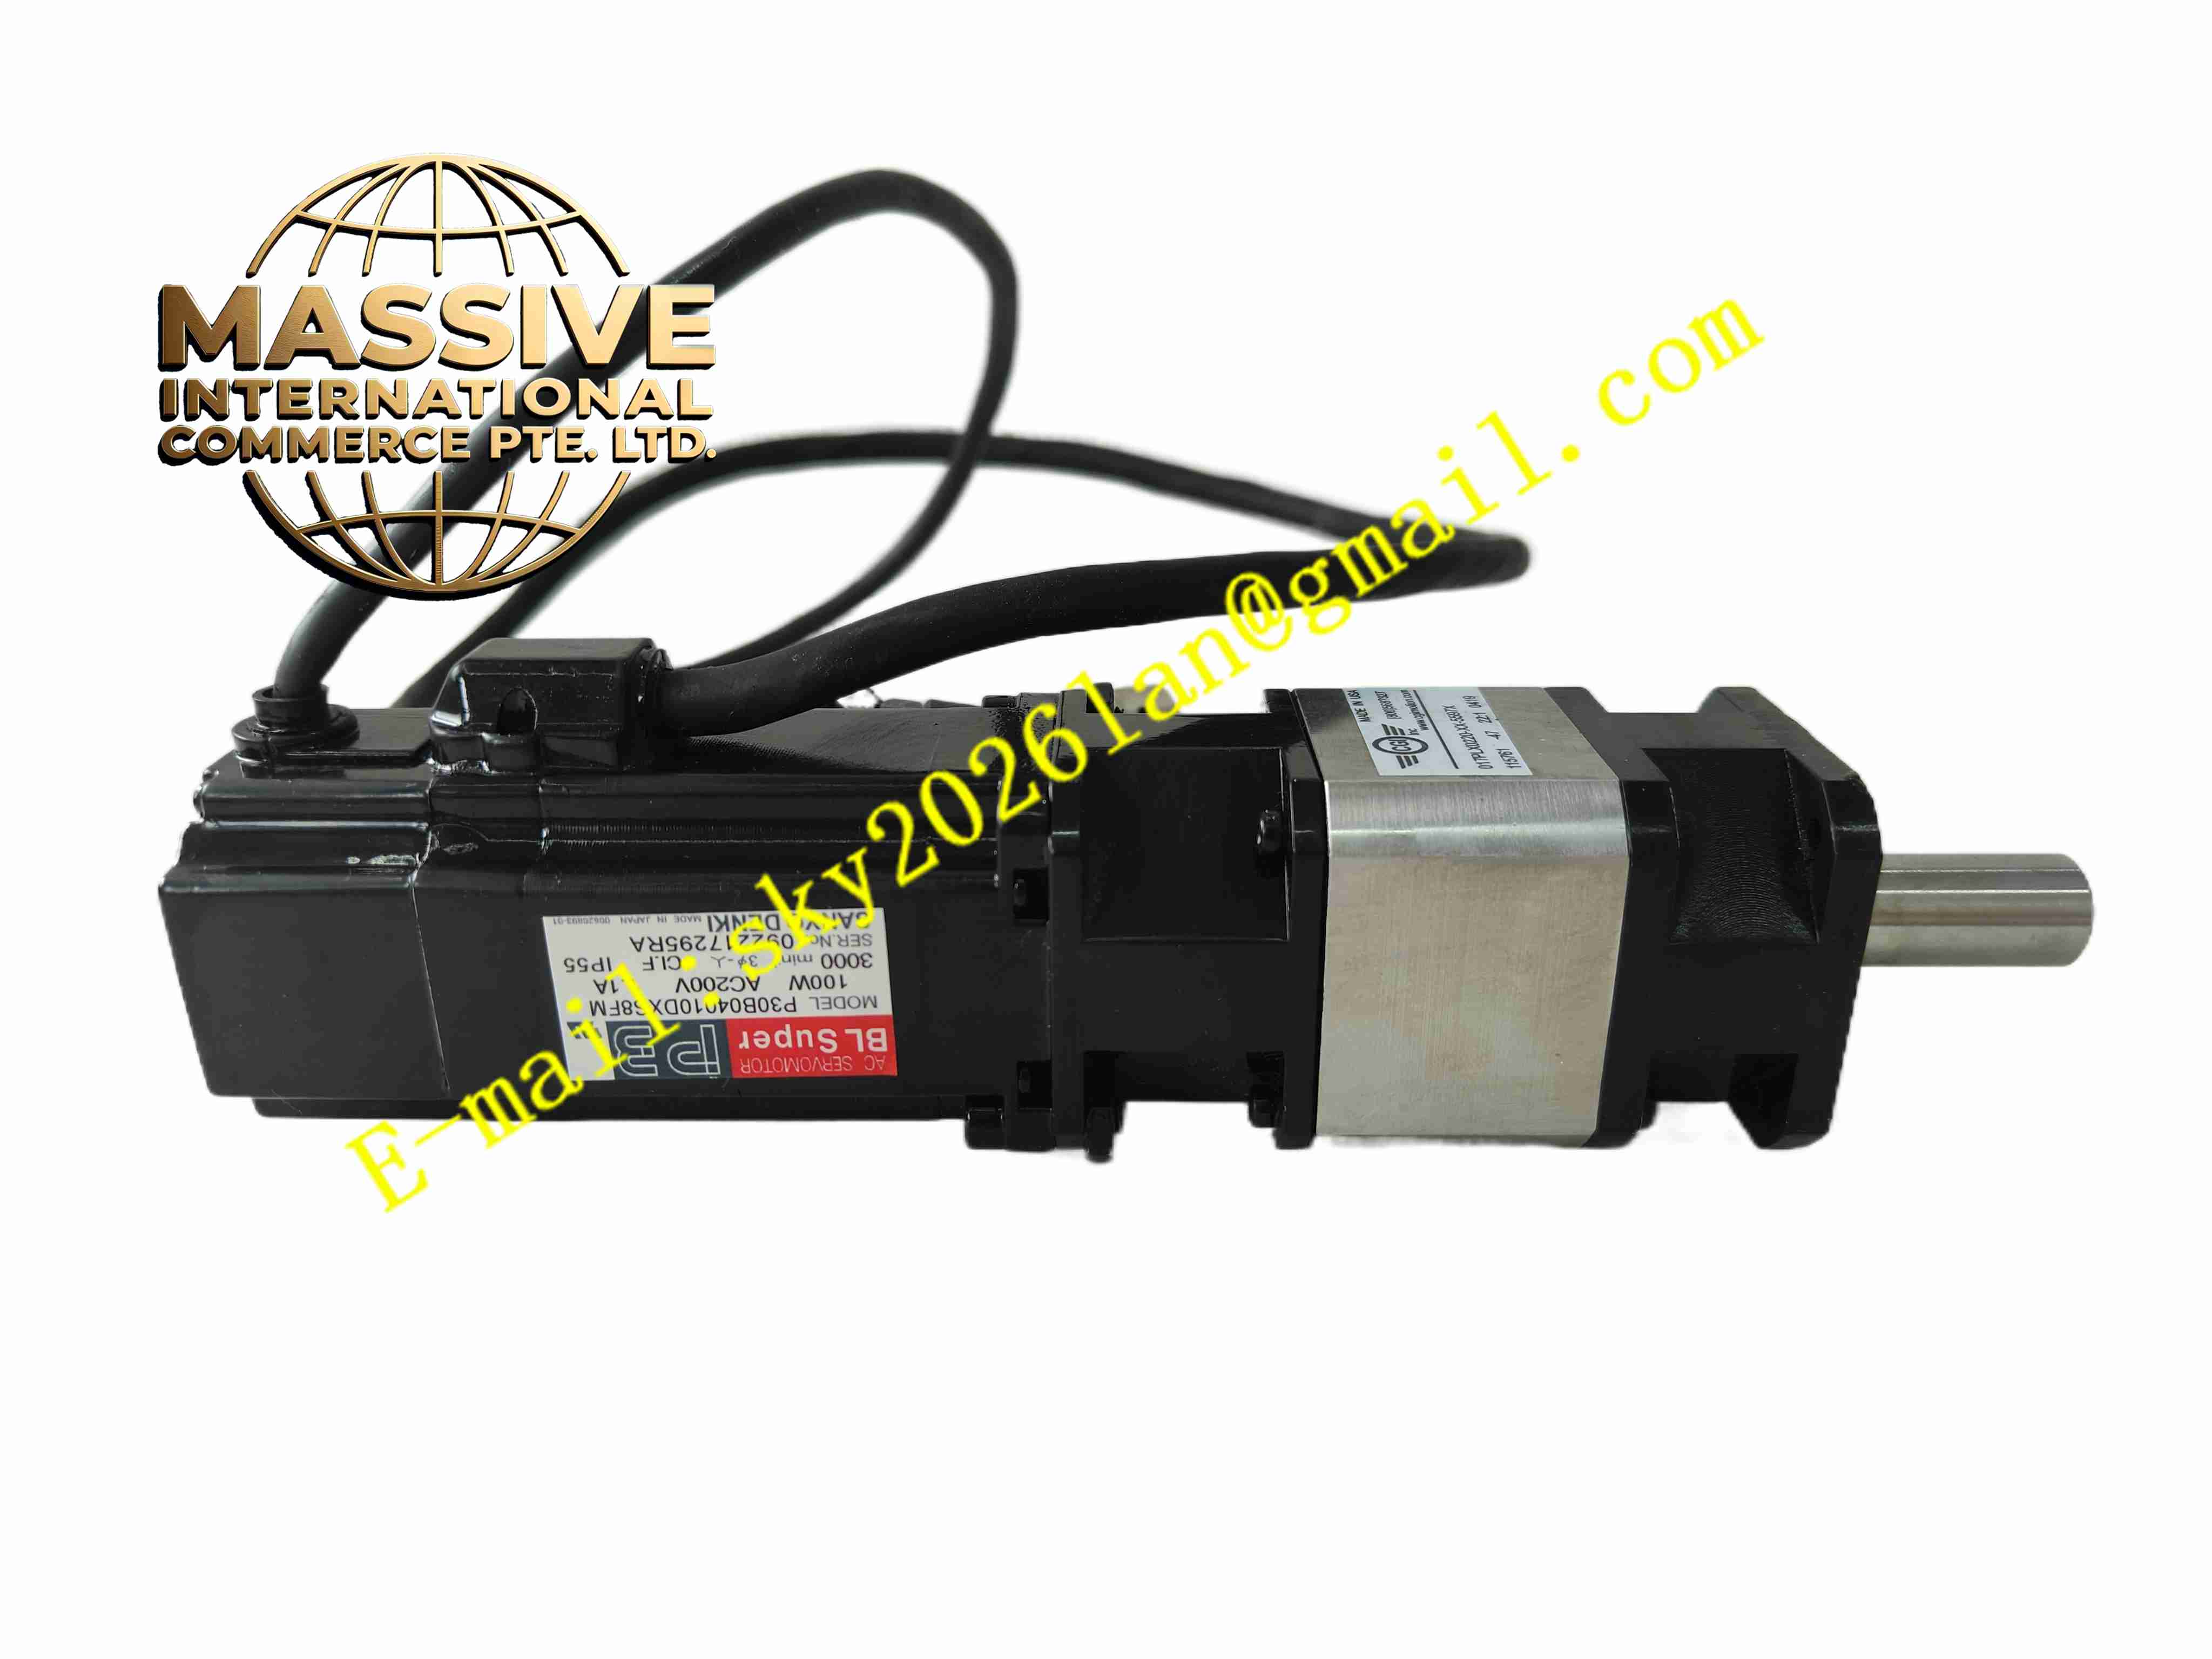
Description
Sanyo Denki P30B04010DXS8FM
Technical Specifications: Series: BL Super P30 series servo motor Rated output power: 100W Rated voltage: 200V AC Rated speed: 3000 rpm Rated torque: 0.32 N·m Maximum torque: 0.96 N·m Encoder type: Incremental encoder Built-in component: Electromagnetic holding brake Flange dimension: 40mm square flange Shaft type: Solid round shaft Operating temperature range: -10℃ ~ +40℃ Storage temperature range: -20℃ ~ +80℃ Relative humidity: 5% to 85%, non-condensing Protection grade: IP65 for motor housing
Functional Features: High dynamic response for fast acceleration and deceleration motion control. Integrated high resolution incremental encoder for rotor speed and position feedback. Built-in electromagnetic holding brake to maintain shaft position during power failure. Low rotor inertia to minimize settling time for short stroke positioning movement. High torque density within compact 40mm flange body size. Low torque ripple for smooth rotation under low speed operating condition. Sealed motor housing to resist dust and splash liquid in workshop environment. Standard servo cable connector for power and encoder signal wiring.
Application Scenarios: Small pick and place automation equipment, desktop dispensing machine, electronic component assembly machine, small conveyor positioning actuator, laboratory precision positioning stage, packaging small indexing mechanism, semiconductor micro inspection equipment.
Performance Parameters: Fast acceleration and deceleration response for high speed short stroke positioning. Stable constant speed rotation at low speed without obvious speed fluctuation. Brake maintains full holding torque after power cut-off. Continuous operation: 24 hours stable operation within rated load range. High overload capacity for short duration peak torque output.
Material Composition: Motor housing: Die cast aluminum alloy with black anti-corrosion coating. Rotor: Silicon steel lamination stack with sintered neodymium permanent magnet. Stator: Copper enameled wire wound stator core. Shaft: High strength quenched alloy steel. Encoder housing: High precision flame retardant plastic. Brake assembly: Electromagnetic coil, friction disc and pressure spring. Connector shell: PA66 flame retardant plastic with nickel plated metal shell.
Structural Features: Compact cylindrical body with square 40mm mounting flange. Front end solid output shaft with keyway for coupling connection. Internal structure divided into stator winding region, permanent magnet rotor region, electromagnetic brake region and encoder region. Double sealed bearing assembly to support rotor rotation. Rear side equipped with power connector and encoder signal connector. Integrated encoder fixed at motor rear end, mechanically coupled with rotor shaft. Housing sealing rubber gaskets between front cover and rear end cover.
Working Principle: Servo amplifier supplies three-phase alternating current to motor stator winding. Alternating magnetic field generated by stator winding interacts with permanent magnetic field on rotor to produce electromagnetic torque and drive rotor rotation. Incremental encoder mounted on rotor rear end continuously detects rotor angular position and rotation speed, and sends pulse feedback signal back to servo drive. Servo drive compares feedback position with target position command and adjusts stator current to correct position error. When power supply cuts off, electromagnetic holding brake coil de-energizes, spring pushes friction disc to clamp rotor shaft and lock rotation.
Installation Requirements: Cut off servo drive power before motor installation and wiring. Fix motor flange onto equipment mounting bracket using specified grade bolts. Connect motor power cable and encoder feedback cable to corresponding connectors. Install flexible coupling between motor shaft and mechanical load shaft. Align shaft centerline to eliminate radial and axial misalignment. Leave ventilation clearance around motor housing for heat dissipation. Ensure motor mounting surface flat and rigid to avoid vibration during operation. Ground motor protective earth terminal reliably.
Usage Notes: Do not apply radial or axial impact force on motor shaft during installation. Do not exceed rated continuous torque and maximum peak torque limit. Use shielded servo cable for power and encoder wiring, separate from high power cables. Do not use brake for dynamic stopping during normal operation, brake only for static holding. Regularly inspect connector tightness and cable insulation integrity. Do not operate motor outside rated temperature and humidity range. Prevent cutting fluid, metal chips and corrosive liquid splashing onto motor housing.







