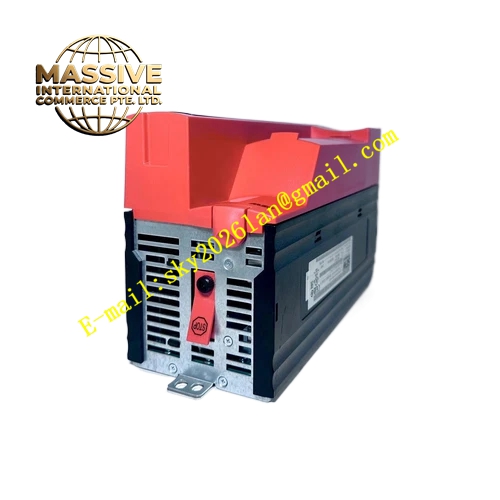
Description
SEW MXM80A-000-000-00-UFR41B
Technical Specifications: Hardware platform: MXM80A motion controller card Interface type: UFR41B hardware variant Bus interface for drive connection Digital input and output channels Analog signal interface Protection class: IP20 Ambient operating temperature: 0℃ ~ +45℃
Functional Features: Centralized multi-axis motion control for SEW MOVIDRIVE servo drives Built-in programming environment for motion sequence editing High-precision electronic cam function Master-slave synchronization and gearing function Absolute and relative positioning control Digital and analog signal acquisition and output Fault monitoring and alarm output for connected servo axes Parameter storage and program backup Real-time motion status feedback for host system Support of high-speed system bus communication
Application Scenarios: Multi-axis packaging production line synchronization control Printing machine multi-roller electronic cam system Continuous web unwinding and winding multi-axis control Gantry robot multi-axis coordinated motion Rotary transfer machine multi-index axis synchronization
Performance Parameters: Supports synchronous control of multiple servo axes High resolution motion trajectory calculation Real-time bus cycle for axis data exchange Fast response for motion trigger and cam switching Fault diagnosis and axis status real-time reporting
Material Composition: Multi-layer industrial PCB circuit board Surface mount industrial-grade chips Gold-plated bus and signal connectors Flame-retardant plastic card edge housing SMT passive components including resistors and capacitors ESD protection circuit components
Structural Characteristics: Plug-in card structure designed for installation inside servo drive cabinet Card edge connector for internal bus connection Front panel equipped with LED status indicators External terminal block for digital and analog I/O wiring Compact board layout with isolation area between power circuit and signal circuit
Working Principle: User downloads compiled motion program into on-board memory of MXM80A card. The controller calculates motion trajectory, cam curve and synchronization target position in real time. Motion commands are transmitted to each connected MDX servo inverter through high-speed internal bus. Servo drives feed back actual axis position, speed and fault information back to MXM80A card. The card compares set target value and actual feedback value to adjust motion commands continuously and realize coordinated multi-axis movement. Digital and analog I/O channels collect external sensor signals and output execution signals to peripheral actuators.
Installation Requirements: Install MXM80A card into reserved expansion slot of SEW servo cabinet Power off the whole drive system before card plugging Ensure firm insertion of card edge connector Separate signal cable and power cable routing PE ground connection for control cabinet must be reliable Installation environment avoids dust, moisture and corrosive gas
Precautions for Use: ESD anti-static protection must be adopted during card installation and replacement Download complete backup of motion program before firmware upgrade Do not plug or unplug the card when system is powered on Check bus cable tightness regularly during long-time operation Do not expose PCB circuit area to dust or conductive debris Follow official programming manual for motion program editing