



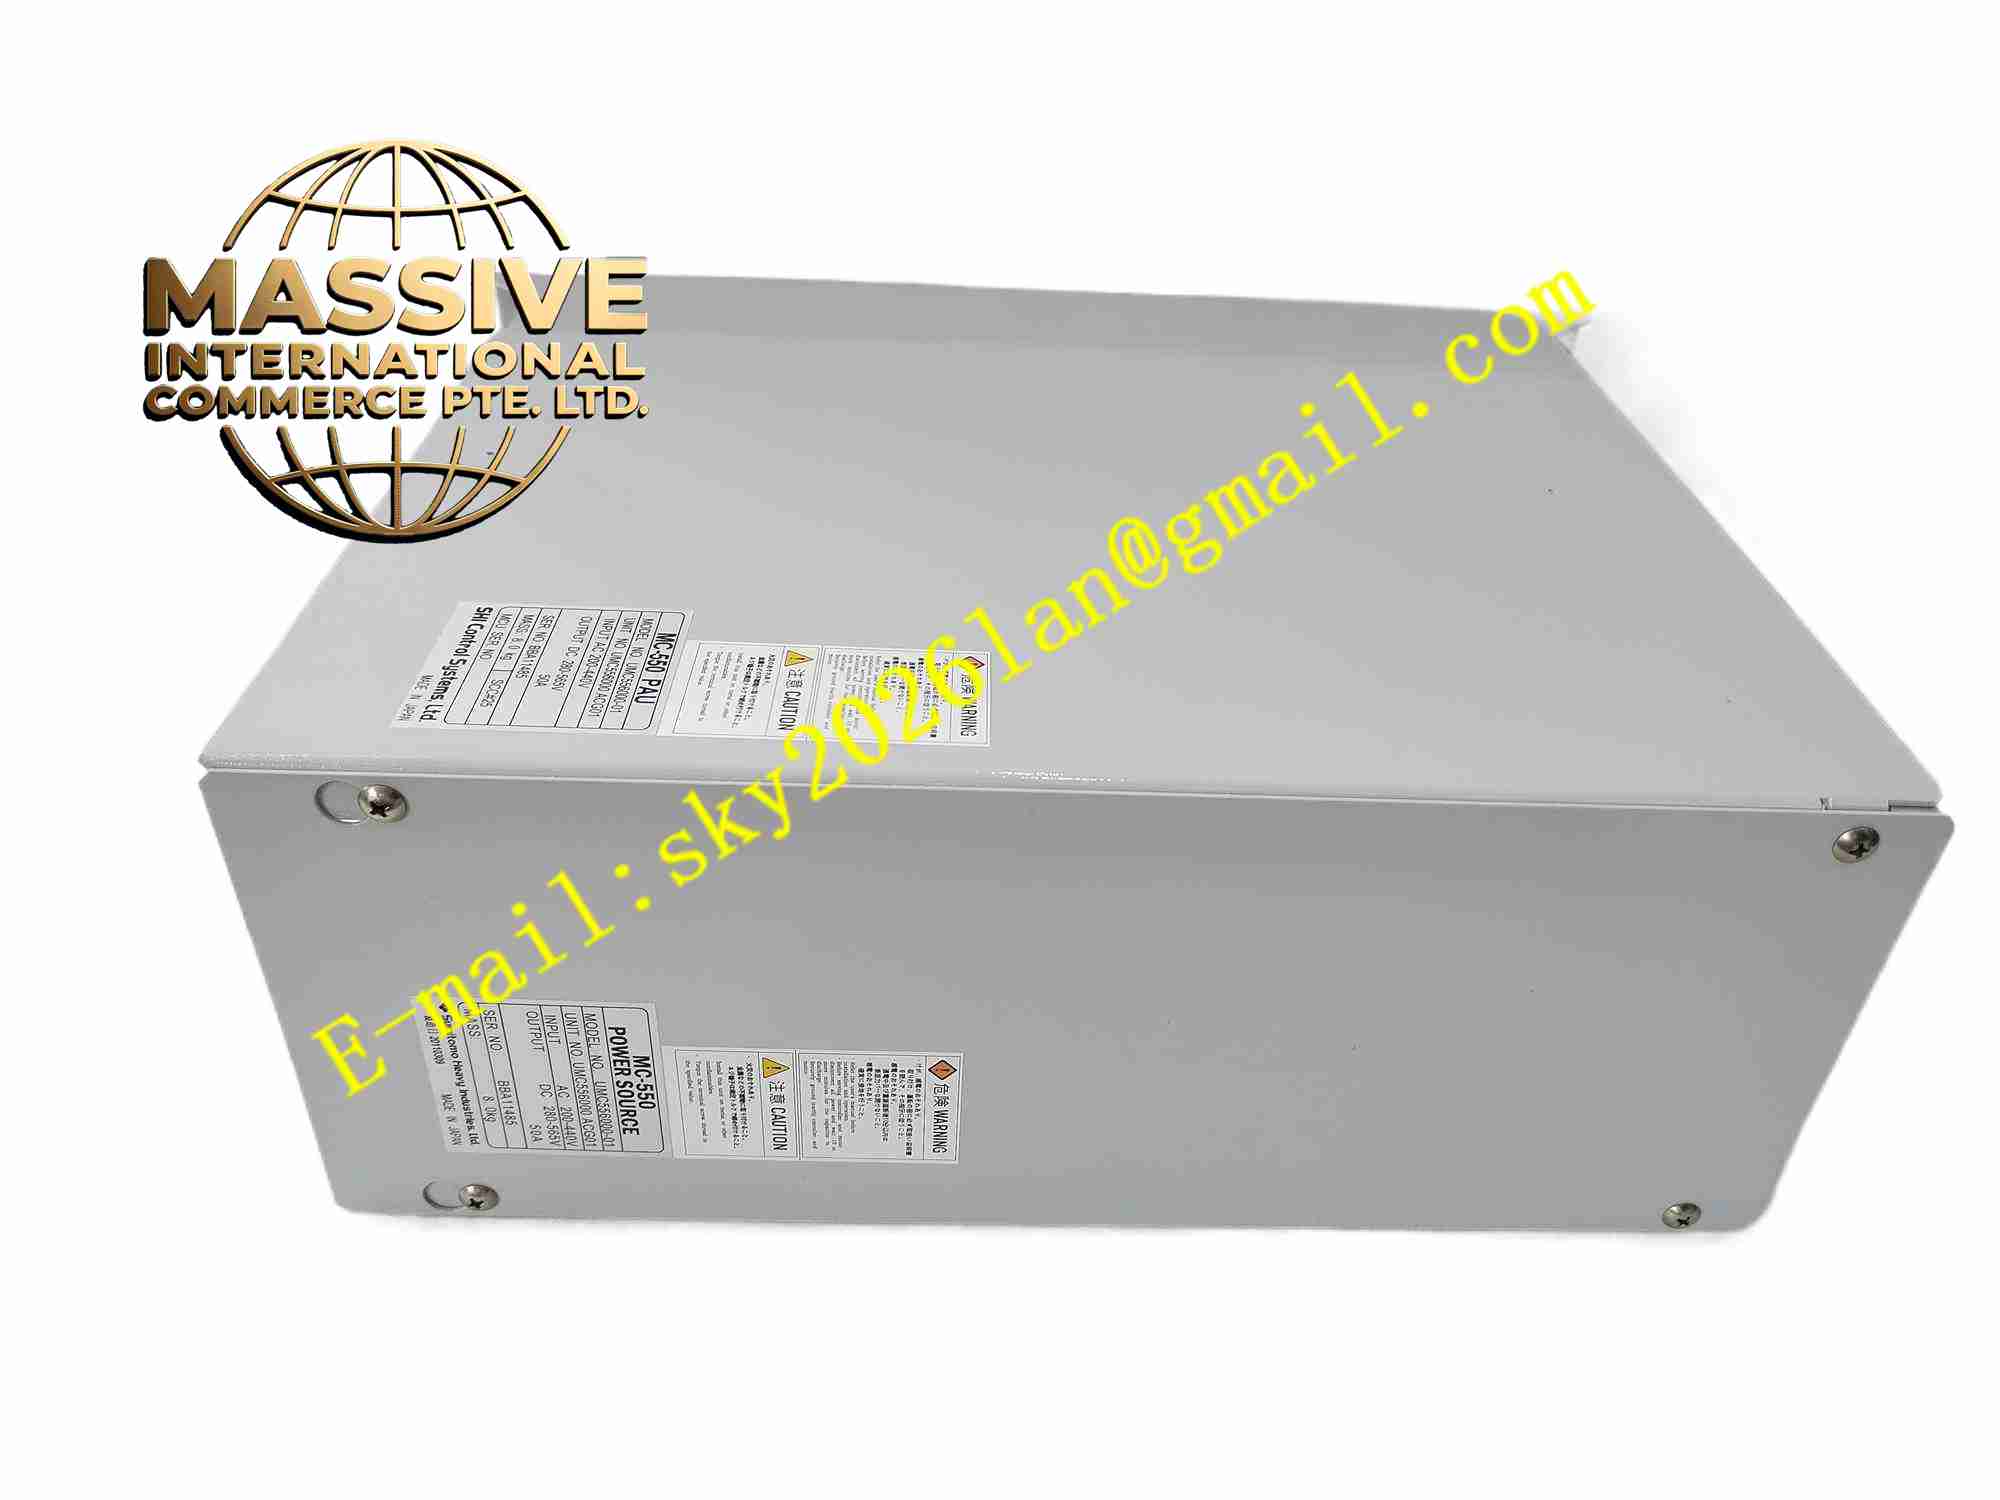
Description
Sumitomo UMC556000-01
Technical Specifications Control mode: Position control, speed control, torque control; Power input AC200V class; Supports incremental encoder feedback; Built-in overcurrent, overvoltage, undervoltage, overheat protection; Digital input and output terminals; Communication interface supports serial motion bus; Operating temperature 0°C to +50°C; PWM power modulation.
Functional Features High dynamic vector control realizes fast speed response; Multiple control modes can be switched according to working condition; Electronic gear function simplifies position command configuration; Real-time monitoring of motor current, speed and position; Built-in fault memory records fault code and operating data; Gain adjustment function optimizes motion response for different mechanical loads; Hardware protection triggers immediate pulse blocking when abnormal state detected.
Application Scenarios Packaging machine motion axis; Material handling robotic axis; Precision cutting machinery; Printing machine register control; Automated assembly equipment; Conveyor speed fine adjustment system.
Performance Parameters Speed regulation range is wide; Position repeat positioning accuracy is high; Motor torque output keeps stable under load fluctuation; Fault detection response is rapid; Dynamic response speed meets high-speed motion requirement.
Material Composition Metal aluminum alloy heat dissipation housing; IGBT power module; Glass fiber PCB control board; Current sampling sensor; Encoder signal processing circuit; Screw power terminals; Status LED indicators.
Structural Features Vertical cabinet DIN rail or base plate mounting; Aluminum casing with fin structure for heat dissipation; Front panel LED status indicators; Terminal blocks for main power, motor wiring, encoder and digital I/O; Internal isolation between power circuit and control circuit.
Working Principle Upper motion controller sends command signal to servo drive. The drive samples motor encoder feedback signal and actual motor current. Internal vector control processor calculates required output voltage and frequency. PWM power circuit supplies adjustable three-phase power to servo motor. The drive continuously compares command value and feedback value to adjust output, maintaining target position, speed or torque. When abnormal electrical condition appears, power output is shut off immediately.
Installation Requirements Mount on flat metal base plate for heat conduction; Reserve sufficient air circulation space around drive; Use shielded cable for encoder wiring; Power cable cross-section matches rated current; Equipment ground terminal must connect to protective earth.
Precautions for Use Do not touch power terminals after power off until internal capacitor discharge completes; Confirm motor wiring phase sequence correctness before first commissioning; Do not run drive beyond rated torque and speed limit; Periodically clean dust on heat sink; Keep encoder cable separated from power cable.







