



Description
Delta Tau ACC-36E
Technical Specifications Supports 6 channels of differential RS-422 quadrature encoder input; maximum encoder pulse frequency 40MHz; each encoder channel includes index, home and limit capture inputs; 16 opto-isolated digital input channels and 16 opto-isolated digital output channels; powered by PMAC backplane 5V DC; operating temperature -20°C to +70°C; relative humidity 5% to 95% non-condensing.
Functional Features Decodes A/B/Z quadrature signals from incremental encoders and transmits position count values to the PMAC main controller. Captures index pulse and home switch signals through hardware latching to record precise axis position. Triggers digital outputs synchronized to specified position points of motion profiles. Reads emergency stop, overtravel limit and machine safety interlock signals from field switches. Reports encoder signal loss and I/O circuit faults to the PMAC system. Allows configuration of encoder direction, index polarity and I/O logic through host software.
Application Scenarios Precision coordinate measuring machines, optical inspection positioning stages, high-speed pick-and-place automation, grinding and polishing CNC equipment, robotics joint feedback systems.
Performance Parameters Low latency encoder signal decoding; hardware timestamping for home and index events; high common-mode noise rejection for differential encoder lines; stable trigger synchronization with trajectory generation cycle.
Material Composition Circuit substrate is FR-4 multilayer flame-retardant printed circuit board; differential line receivers and optocoupler chips are high-speed industrial semiconductors; edge connectors adopt gold-plated copper alloy contacts; passive components are low-drift industrial resistors and capacitors; external wiring connectors use nickel-plated copper contacts.
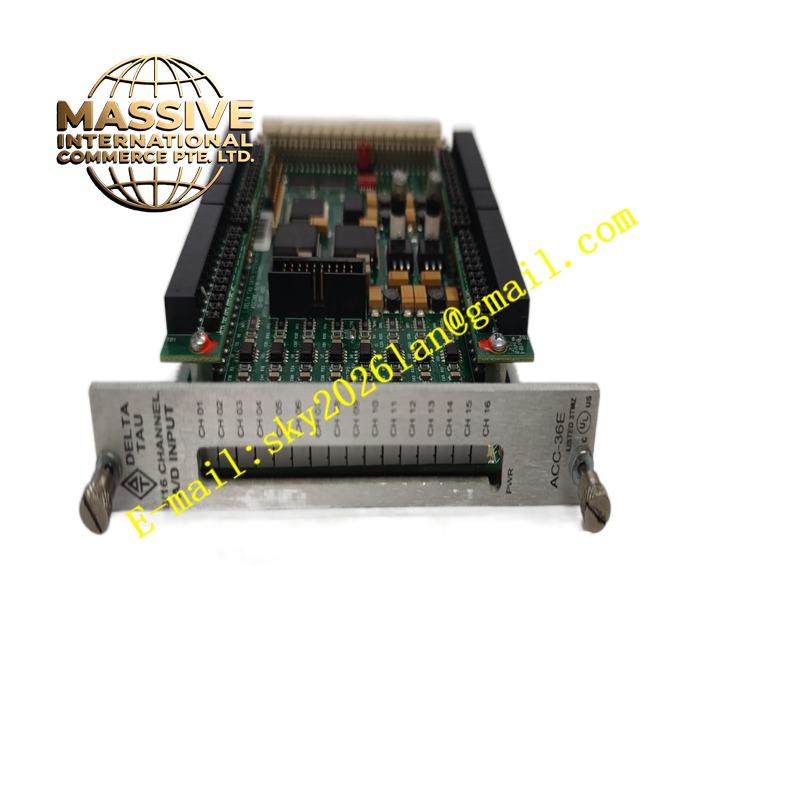
Structural Characteristics Compact rectangular daughter board designed for PMAC carrier expansion slots. Multiple high-density connectors on the board edge for encoder feedback and digital I/O wiring. Small LED indicators show power supply and encoder signal activity status. Locating pins and bus connectors guarantee accurate mating with the PMAC main controller.
Working Principle Differential quadrature encoder signals from servo motors enter RS-422 receiver circuits on the board. The decoding circuit converts pulse sequences into digital position counts and sends data to the PMAC processor over the expansion bus. Home and index pulses trigger hardware latch circuits to freeze position values instantly. Digital input signals pass through opto-isolation and feed into the logic circuit, while output commands from the main controller activate the output drive circuits.
Installation Requirements Power down the PMAC chassis before installing the ACC-36E board. Fix the board to the designated expansion slot of the PMAC carrier board. Use shielded differential cables for encoder wiring and terminate the differential lines at the receiver end. Map encoder channels and set capture modes in PMAC configuration software. Perform encoder direction test and limit switch function verification after wiring.
Precautions for Use Maintain proper differential line termination to reduce signal reflection. Route encoder cables away from variable-frequency drive power cables. Confirm that encoder voltage levels match the board input specifications. Do not apply overvoltage to opto-isolated I/O terminals.







