Description
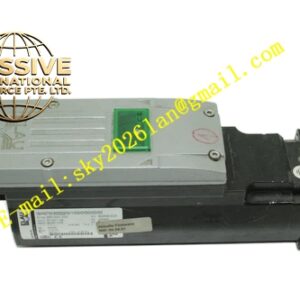
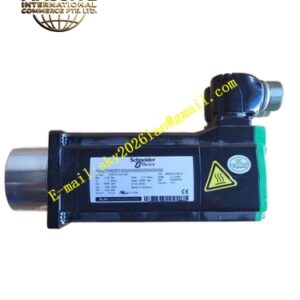
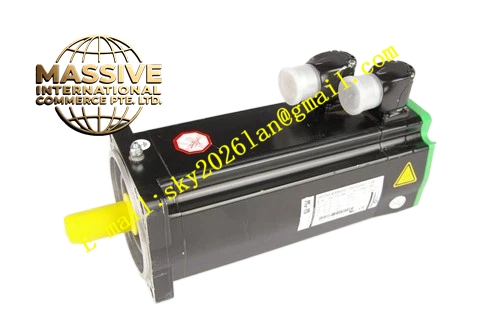
ELAU SH31003P11A2000
Technical Specifications: Rated voltage 400 VAC, flange dimension 100 mm, continuous stall torque 8.2 Nm, peak torque 24.6 Nm, rated speed 3000 rpm, absolute multi‑turn Hiperface encoder, shaft diameter 24 mm, insulation class F, IP65 protection rating on shaft and housing.
Functional Features: Ultra‑low rotor inertia for fast dynamic response, multi‑turn absolute encoder retains position data after full power loss, rotatable M23 power and feedback connectors, built‑in motor‑winding thermal protection sensor, high‑overload capability for short‑duration peak‑torque operation, full compatibility with Schneider PacDrive3 drive hardware.
Application Scenarios: High‑speed packaging machinery, printing and converting lines, robotic handling axes, food‑processing automation, semiconductor manufacturing equipment, multi‑axis synchronized motion platforms.
Performance Parameters: Rotor inertia 21.0 kg·cm², torque ripple lower than 2.0 %, multi‑turn encoder measuring range 4096 revolutions, operating temperature range ‑20 °C ~ +40 °C.
Material Composition: Die‑cast aluminum alloy housing, laminated silicon‑steel stator core, high‑energy neodymium permanent‑magnet rotor, alloy steel output shaft, glass‑fiber‑reinforced plastic connector shells.
Structural Characteristics: Fully enclosed fin‑cooled housing, flange‑mount installation, side‑mounted rotatable circular connectors, PT100 thermal sensor embedded within stator windings, non‑brake variant structure, key‑equipped output shaft.
Working Principle: Three‑phase sinusoidal stator current generates rotating magnetic field to drive permanent‑magnet rotor rotation. Multi‑turn Hiperface encoder continuously transmits absolute shaft position and velocity data to servo drive. Servo drive implements closed‑loop current‑speed‑position cascade control to achieve precise motion output.
Installation Requirements: Fasten to machine mounting flange with specified torque values; maintain coupling coaxial tolerance ≤ 0.05 mm; preserve adequate surrounding space for natural convection cooling; route power and feedback cables separately; secure connector locking rings against vibration loosening.
Usage Notes: Prevent mechanical shock impact to motor shaft; strictly match encoder type with supporting servo‑drive firmware configuration; avoid continuous operation above thermal‑limit threshold; protect shaft sealing lip from oil mist and chemical solvent attack; apply ESD precautions while handling encoder‑related wiring.