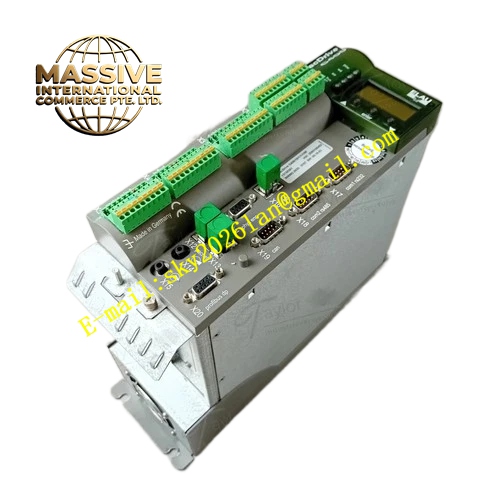
Description
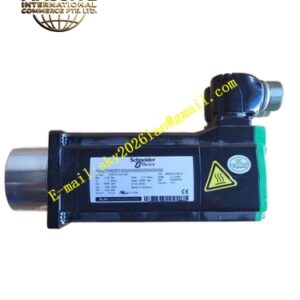
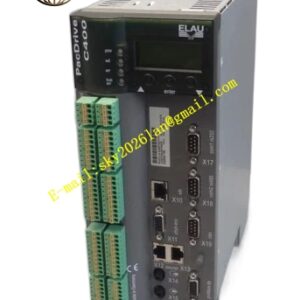
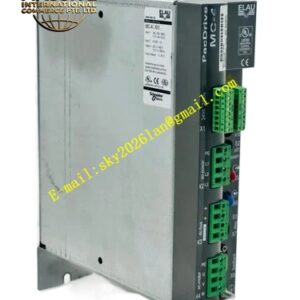
ELAU VDMO1D10AA00
Technical Specifications: DC‑link input voltage 565‑680 VDC, continuous output current 10 A, peak output current 20 A, support Hiperface, EnDat and incremental encoder feedback, SERCOS III optical‑fiber bus interface, built‑in brake chopper channel, protection rating IP20, operating ambient temperature range 0 °C‑+55 °C, performance derating when temperature higher than 45 °C.
Functional Features: Integrated current‑speed‑position cascade closed‑loop control algorithm, SERCOS III bus realizes high‑speed multi‑axis synchronization, built‑in motor parameter automatic identification function, comprehensive hardware fault detection covering over‑current, over‑voltage, under‑voltage, over‑temperature, configurable digital input and output channels, front‑panel multi‑color LED diagnostic indicator array.
Application Scenarios: Single‑axis or multi‑axis synchronous motion control of packaging machinery, printing press drive axes, textile equipment servo axes, automated assembly station motion control, converting machinery multi‑axis drive system.
Performance Parameters: Motion control loop cycle time 125 µs, speed‑loop bandwidth up to 1200 Hz, fault detection response time less than 10 ms, support motor thermal sensor signal acquisition, maximum configurable 16 digital I/O points.
Material Composition: Sheet‑metal cabinet‑grade housing, IGBT power switching modules, high‑voltage DC‑link film capacitors, multi‑layer printed‑circuit control board, flame‑retardant plastic insulated terminal blocks.
Structural Characteristics: Vertical book‑style cabinet installation structure, DIN‑rail mounting compatible, front‑panel LED status indicator, upper‑area DC‑bus power wiring terminals, lower‑area motor power, encoder feedback and bus‑signal terminals, internal forced‑air convection cooling airflow path.
Working Principle: High‑voltage DC‑bus power input from central power supply enters internal IGBT power bridge circuit, converts DC‑link voltage to three‑phase variable‑frequency variable‑voltage AC output to drive servo motor. Motion command set‑point received from upper‑level motion controller via SERCOS III bus. Encoder feedback signal is sampled locally. Closed‑loop control algorithm generates PWM driving waveform. Built‑in monitoring circuit completes real‑time detection for voltage, current and temperature parameters.
Installation Requirements: Install inside IP20‑grade industrial control cabinet; keep vertical‑direction ventilation clearance above and below drive unit according to manufacturer specification; use shielded motor cable and encoder feedback cable complying with ELAU specification; connect protective earth terminal to cabinet ground bar; keep physical separation between high‑power motor cables and low‑signal communication cables.
Usage Notes: Do not open housing cover under power‑on condition; complete motor parameter dataset configuration during equipment commissioning; verify DC‑bus voltage value before first power‑on; avoid operating in environment with conductive dust and corrosive gas; make proper shielding grounding for signal cables; regularly inspect terminal tightening torque in high‑vibration application scenario.