Description
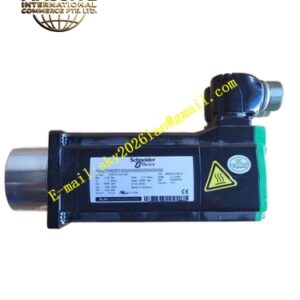
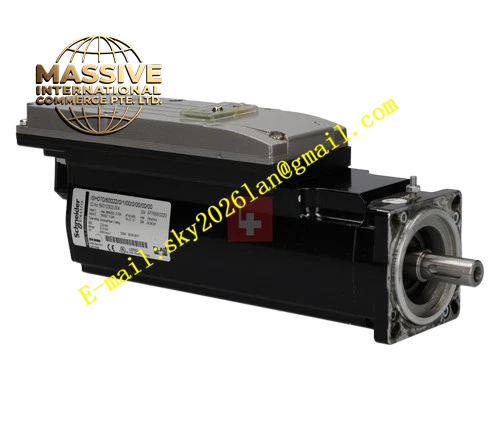
ELAU VIA0703D11A0000
Technical Specifications: Rated power 0.6 kW, rated speed 3000 rpm, maximum mechanical speed 6000 rpm, continuous stall torque 2.2 Nm, peak torque 6.6 Nm, rotor inertia 0.32 kg·cm², insulation class F, protection grade IP65, natural convection cooling, B5 70 mm mounting flange, 14 mm flat‑key shaft, single‑turn absolute Hiperface Sin‑Cos encoder, without built‑in holding brake, total weight 2.8 kg, ambient operating temperature 0 °C‑40 °C.
Functional Features: Absolute Sin‑Cos Hiperface encoder stores electronic nameplate data for automatic parameter reading by PacDrive drives. Compact high‑torque‑density structure saves mechanical installation space. Low‑inertia rotor delivers fast acceleration‑deceleration response. Internal stator‑embedded PTC thermal sensor performs over‑temperature protection. Maintenance‑free sealed bearing assembly supports long‑term continuous operation.
Application Scenarios: High‑speed pick‑and‑place robotic stations, small‑format packaging machinery, electronic component assembly equipment, precision textile automation devices, laboratory‑grade multi‑axis positioning platforms.
Performance Parameters: Encoder resolution 128 sine‑cosine periods per revolution, CE and UL certification, three‑phase 400‑480 V AC power supply.
Material Composition: Light‑weight die‑cast aluminum motor housing, thin‑gauge laminated silicon‑steel stator core, neodymium‑iron‑boron permanent‑magnet rotor, oxygen‑free copper winding conductors, quenched alloy steel output shaft, reinforced thermoplastic connector housing parts.
Structural Features: Compact B5 front‑flange mounting structure. Independent power and feedback signal connectors arrange on motor top housing. Shaft‑end integrated IP65 labyrinth sealing assembly. PTC thermal sensing elements embed inside stator winding coils. Short overall body length adapts narrow mechanical installation space.
Working Principle: Servo drive provides three‑phase sinusoidal excitation current for stator windings and generates rotating magnetic field. Rotor permanent magnet interacts with stator magnetic field to produce output torque. Absolute Hiperface Sin‑Cos encoder continuously transmits rotor absolute position and real‑time velocity information to servo drive to realize high‑precision closed‑loop motion control.
Installation Requirements: Secure motor on flat rigid metal mounting surface. Control coupling concentricity error less than 0.04 mm. Reserve surrounding ventilation clearance for heat dissipation. Lay power cable and encoder feedback cable inside separate cable channels. Connect protective‑earth terminal reliably to ground busbar. Verify connector full locking condition after wiring completion.
Usage Notes: Operate under non‑condensing ambient humidity range 5‑85 %. Do not apply radial or axial shaft load exceeding published specification limits. Configure servo drive feedback parameter for Hiperface Sin‑Cos absolute encoder mode. Avoid long‑duration continuous operation under peak‑torque status. Prevent welding electric current passing through motor housing shell.