Description
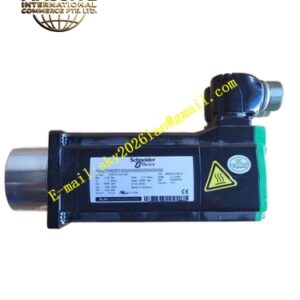
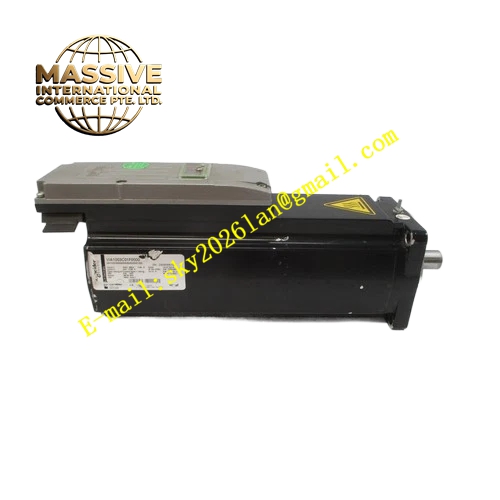
ELAU VIA1003C01F0000
Technical Specifications: Rated power 2.3 kW, rated speed 3000 rpm, maximum mechanical speed 4500 rpm, continuous stall torque 7.2 Nm, peak torque 21.6 Nm, rotor inertia 1.85 kg·cm², insulation class F, IP65 protection rating, natural air cooling, B5 100 mm mounting flange, 19 mm flat‑key shaft, incremental Sin‑Cos encoder feedback, no built‑in holding brake, net weight 6.9 kg, operating ambient temperature 0 °C‑40 °C.
Functional Features: Incremental Sin‑Cos encoder supports high‑resolution velocity and position feedback. Electronic nameplate inside encoder allows automatic motor‑parameter identification by PacDrive servo controllers. Medium‑inertia rotor balances dynamic response and heavy‑load driving capability. Built‑in PTC thermal sensor implements winding over‑temperature protection. High sine‑wave back‑EMF characteristic reduces cable copper loss. Sealed maintenance‑free bearing unit extends service life.
Application Scenarios: Medium‑load packaging production lines, printing equipment main and auxiliary axes, automated material handling gantries, rubber and plastic processing auxiliary drive mechanisms, general‑purpose multi‑axis processing machinery.
Performance Parameters: Encoder 128 sine‑cosine periods per revolution, CE and UL certified, three‑phase 400‑480 V AC power input.
Material Composition: High‑strength die‑cast aluminum alloy housing, stacked silicon‑steel‑sheet stator core, high‑energy neodymium‑iron‑boron permanent‑magnet rotor, oxygen‑free copper winding wires, quenched alloy steel output shaft, reinforced thermoplastic connector shells.
Structural Features: Standard B5 front‑flange mounting layout. Separated power connector and encoder signal connector mount on top housing surface. Shaft‑end labyrinth‑type sealing assembly ensures IP65 protection level. PTC thermal sensing components embed within stator winding structure. Compact rectangular frame layout optimizes cabinet mechanical arrangement.
Working Principle: Three‑phase sinusoidal current output from servo drive creates stator rotating magnetic field. Magnetic‑field coupling between stator and rotor permanent magnet generates driving torque. Incremental Sin‑Cos encoder delivers real‑time rotor position and speed analog signals back to servo drive to complete closed‑loop position, speed and torque regulation.
Installation Requirements: Mount motor onto sufficiently rigid low‑vibration metal base. Guarantee coupling concentricity deviation below 0.05 mm. Maintain adequate surrounding ventilation space for heat dissipation. Route power cables and encoder signal cables in separated cable ducts. Complete reliable protective‑earth connection. Inspect connector locking state after wiring work finishes.
Usage Notes: Ambient relative humidity must keep in 5‑85 % non‑condensing scope. Do not subject motor shaft to radial and axial overload exceeding technical specification. Set servo drive feedback parameter to incremental Sin‑Cos encoder mode. Prohibit continuous long‑time peak‑torque operation. Prevent welding current flowing through motor housing.