



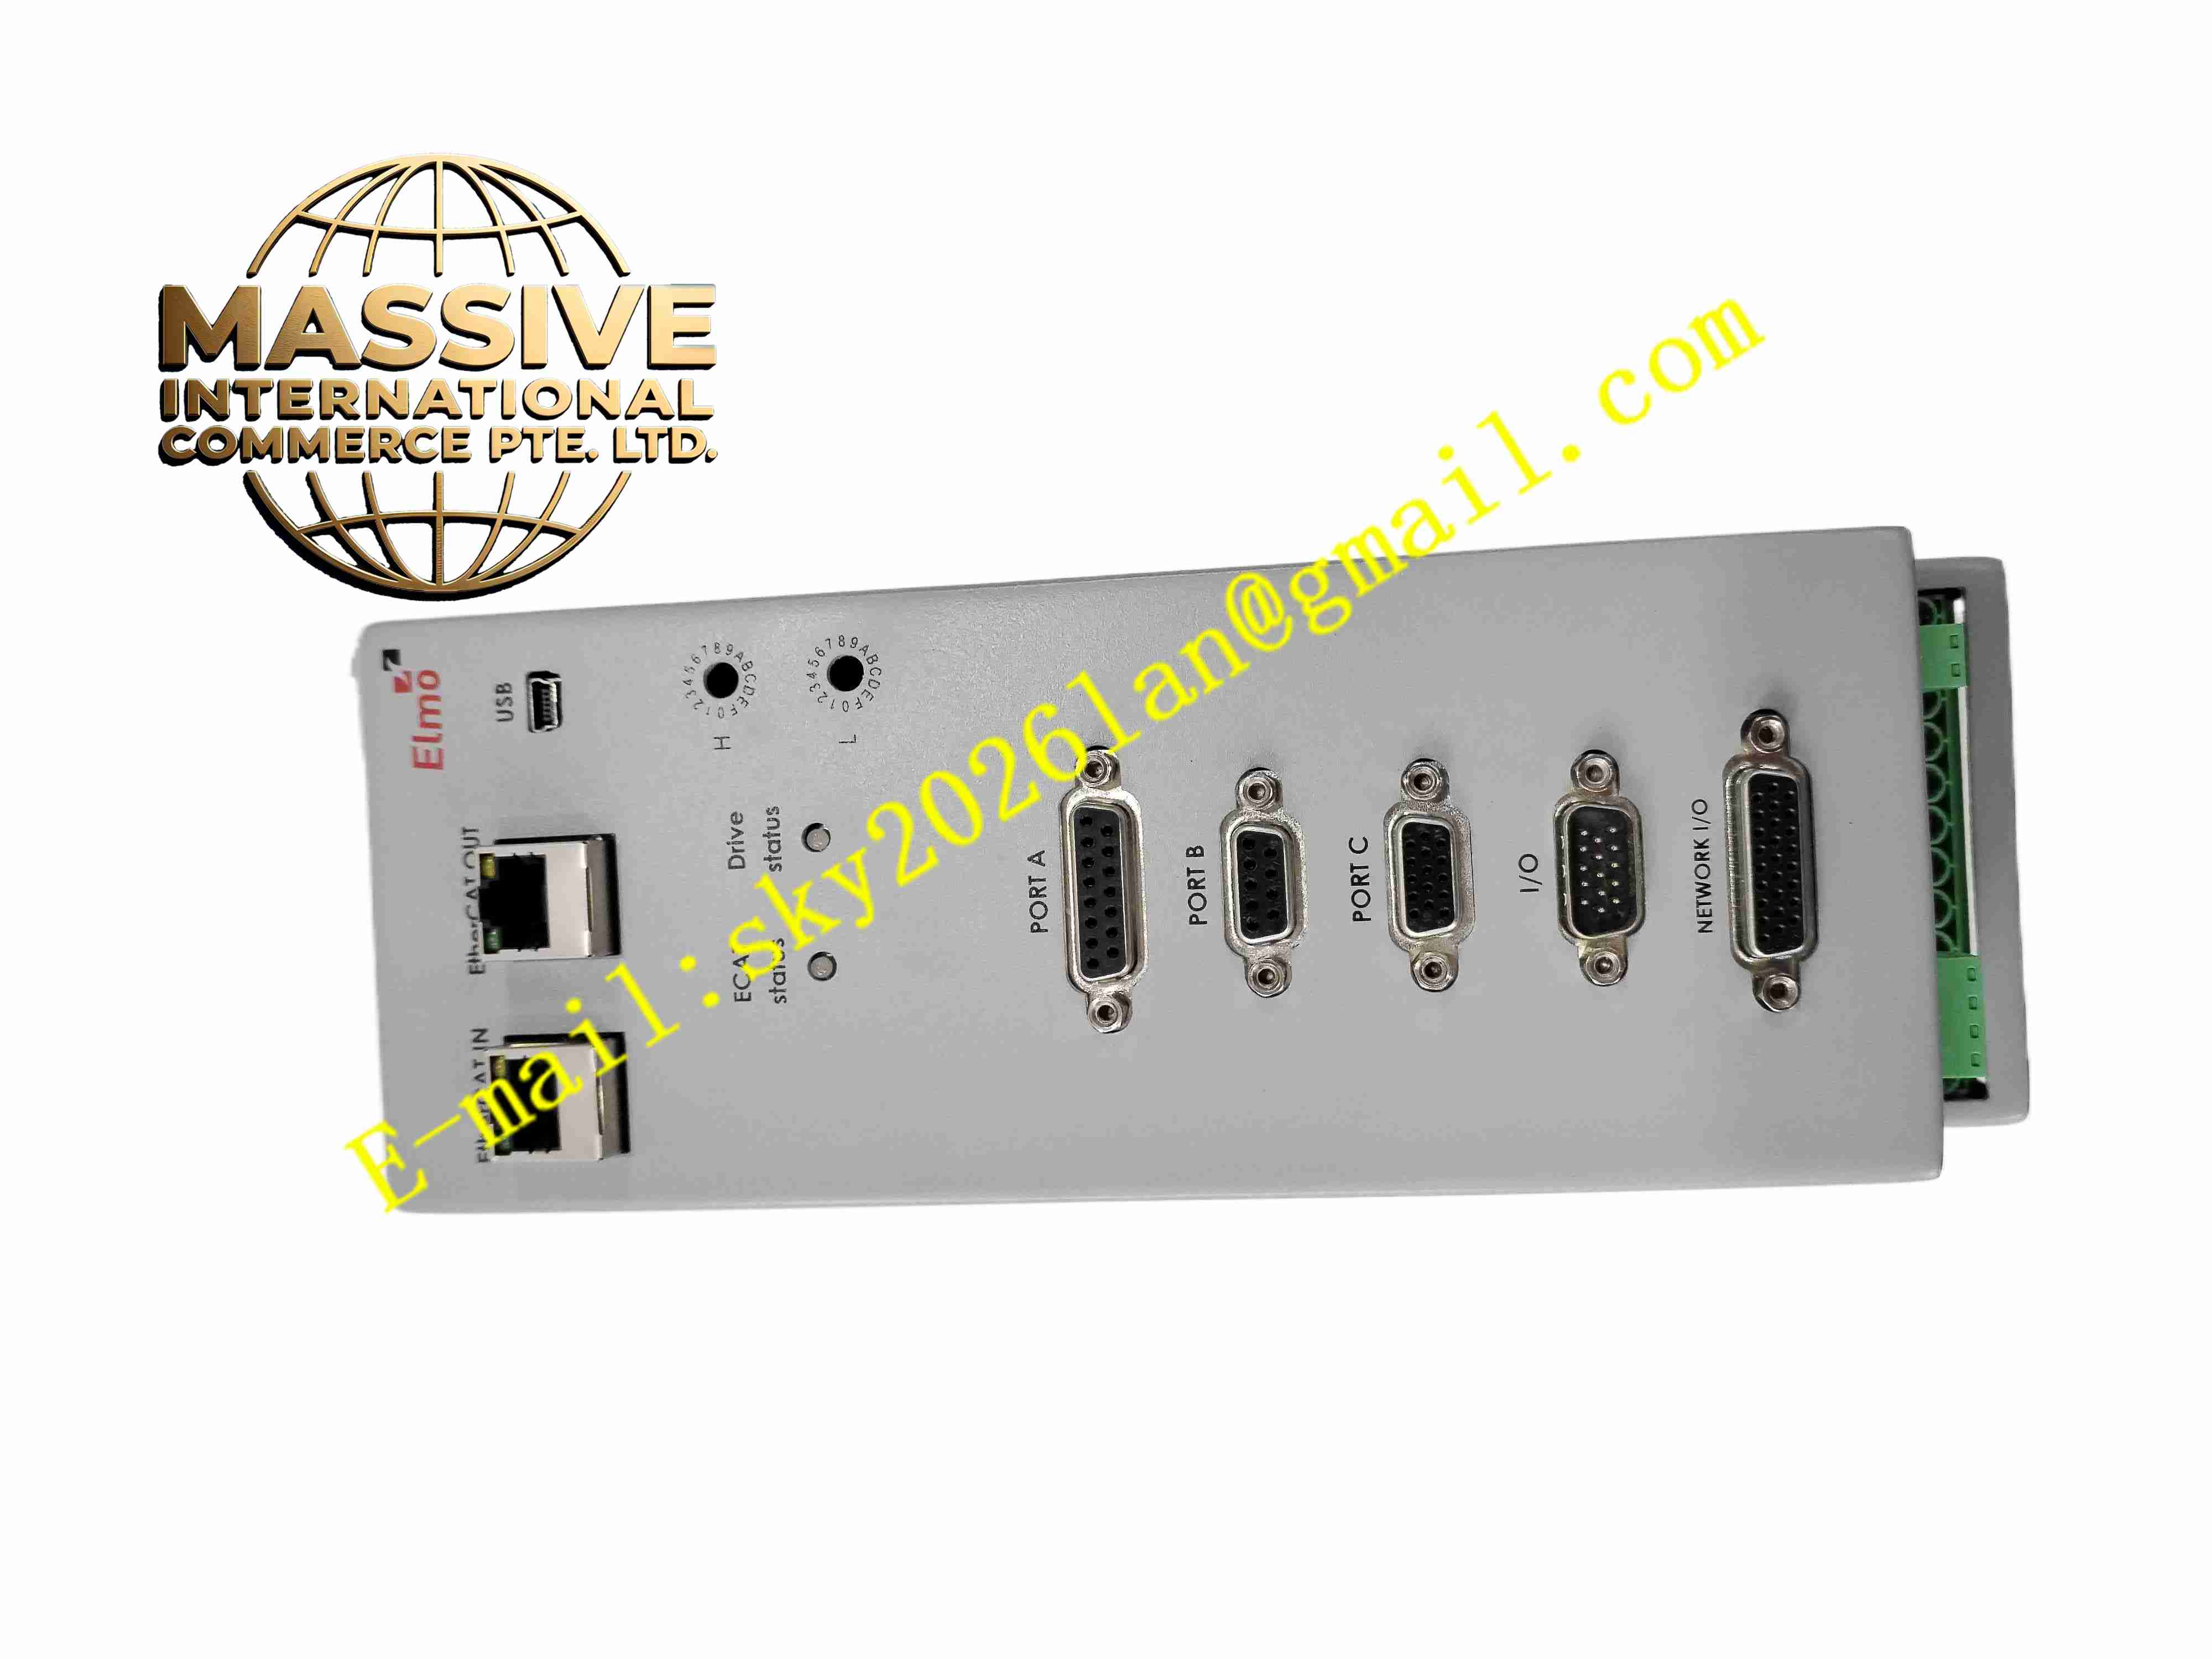
Description
Elmo G-TUB30
Technical Specifications
- Product Type: Digital high power servo drive
- DC Input Voltage: 20 V DC to 80 V DC
- Continuous Output Current: 30 A RMS
- Peak Output Current: 60 A RMS
- Control Modes: Torque, speed, position closed loop control
- Communication Interfaces: EtherCAT, CANopen
- Feedback Support: Encoder, resolver, Hall sensor
- Switching Technology: FASST fast soft switching
- Power Conversion Efficiency: Above 99 %
- Protection Functions: Overcurrent, overvoltage, undervoltage, overtemperature, short circuit, feedback fault
- Protection Rating: IP20
- Operating Temperature: -20 °C to +70 °C
- Mounting: Panel mounting with heat sink interface
- Cooling Method: Forced air or liquid cooling via base plate
Functional Features
- High bandwidth three closed-loop control for precise torque, speed and position regulation.
- FASST fast soft switching technology reduces switching EMI and power loss.
- EtherCAT real-time bus support for multi-axis synchronised motion control.
- Multiple feedback interfaces compatible with incremental encoder, absolute encoder and resolver.
- Built-in automatic motor identification and auto-tuning function for fast commissioning.
- Comprehensive hardware protection prevents damage under overload, short circuit and over-temperature conditions.
- High power density compact mechanical structure reduces cabinet space occupation.
- Stand-alone operation mode supports pre-programmed motion sequences without upper controller.
- Elmo EASII software supports parameter configuration, oscilloscope monitoring and fault diagnosis.
- Low thermal stress design improves long service life under continuous heavy load operation.
Application Scenarios
- Industrial robotic joint high power servo control
- Automated machine tool heavy feed axis drive
- Packaging machinery high dynamic motion axis
- AGV and mobile robot traction motor control
- Aerospace test bench precision motion equipment
Material Composition
- Housing: High strength aluminium alloy heat sink base and plastic front frame
- Main PCB: FR4 high reliability printed circuit board with conformal coating
- Power components: High efficiency MOSFET power chips
- Processor: High speed motion control ASIC and microcontroller
- Terminal blocks: High current nickel-plated copper screw terminals
- Communication connectors: Gold plated contact D-Sub connectors
Structural Characteristics
- Flat rectangular metal base plate designed for thermal dissipation.
- Front panel with LED indicators for power, run and fault status.
- High current screw terminals for DC bus and motor power wiring.
- Separate low current connectors for encoder feedback and communication signals.
- Internal circuit layout segregates high power switching circuit and low noise signal circuit.
- Base plate surface flatness ensures good thermal contact with external heat sink.
Working Principle Upper motion controller sends motion command via EtherCAT or CANopen bus to G-TUB30. Drive internal ASIC executes closed-loop control algorithm according to feedback signal from motor encoder. PWM power stage converts DC bus voltage into three-phase variable frequency AC output to drive servo motor. FASST switching technology controls power device turn-on and turn-off to minimise voltage overshoot and electromagnetic interference. Built-in protection circuit monitors current, voltage and temperature continuously, and cuts off power output immediately when fault condition triggers.
Installation Requirements
- Mount drive on properly sized heat sink with thermal grease applied evenly.
- Tighten mounting screws to specified torque value.
- Use high gauge shielded cable for motor power and encoder feedback wiring.
- Separate motor power cable from signal and communication cables.
- Complete protective earth connection to heat sink and cabinet ground bar.
- Perform motor auto identification and servo loop auto-tuning after wiring completion.
- Verify bus communication and feedback signal integrity before full load test.
Usage Notes
- Do not exceed maximum DC input voltage and peak output current rating.
- Maintain sufficient cooling airflow or liquid cooling flow to limit base plate temperature.
- Keep cabinet environment free of conductive dust and corrosive vapor.
- Use ESD protection when handling drive and encoder cables.
- Backup drive parameters before firmware upgrade or program modification.
- Disconnect DC bus power and discharge bus capacitor before opening wiring terminals.
- Replace drive immediately when permanent power stage or control hardware fault occurs.







