Description
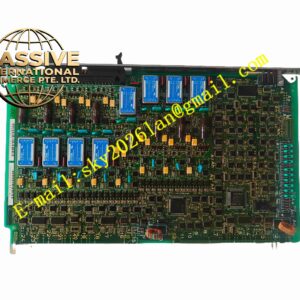
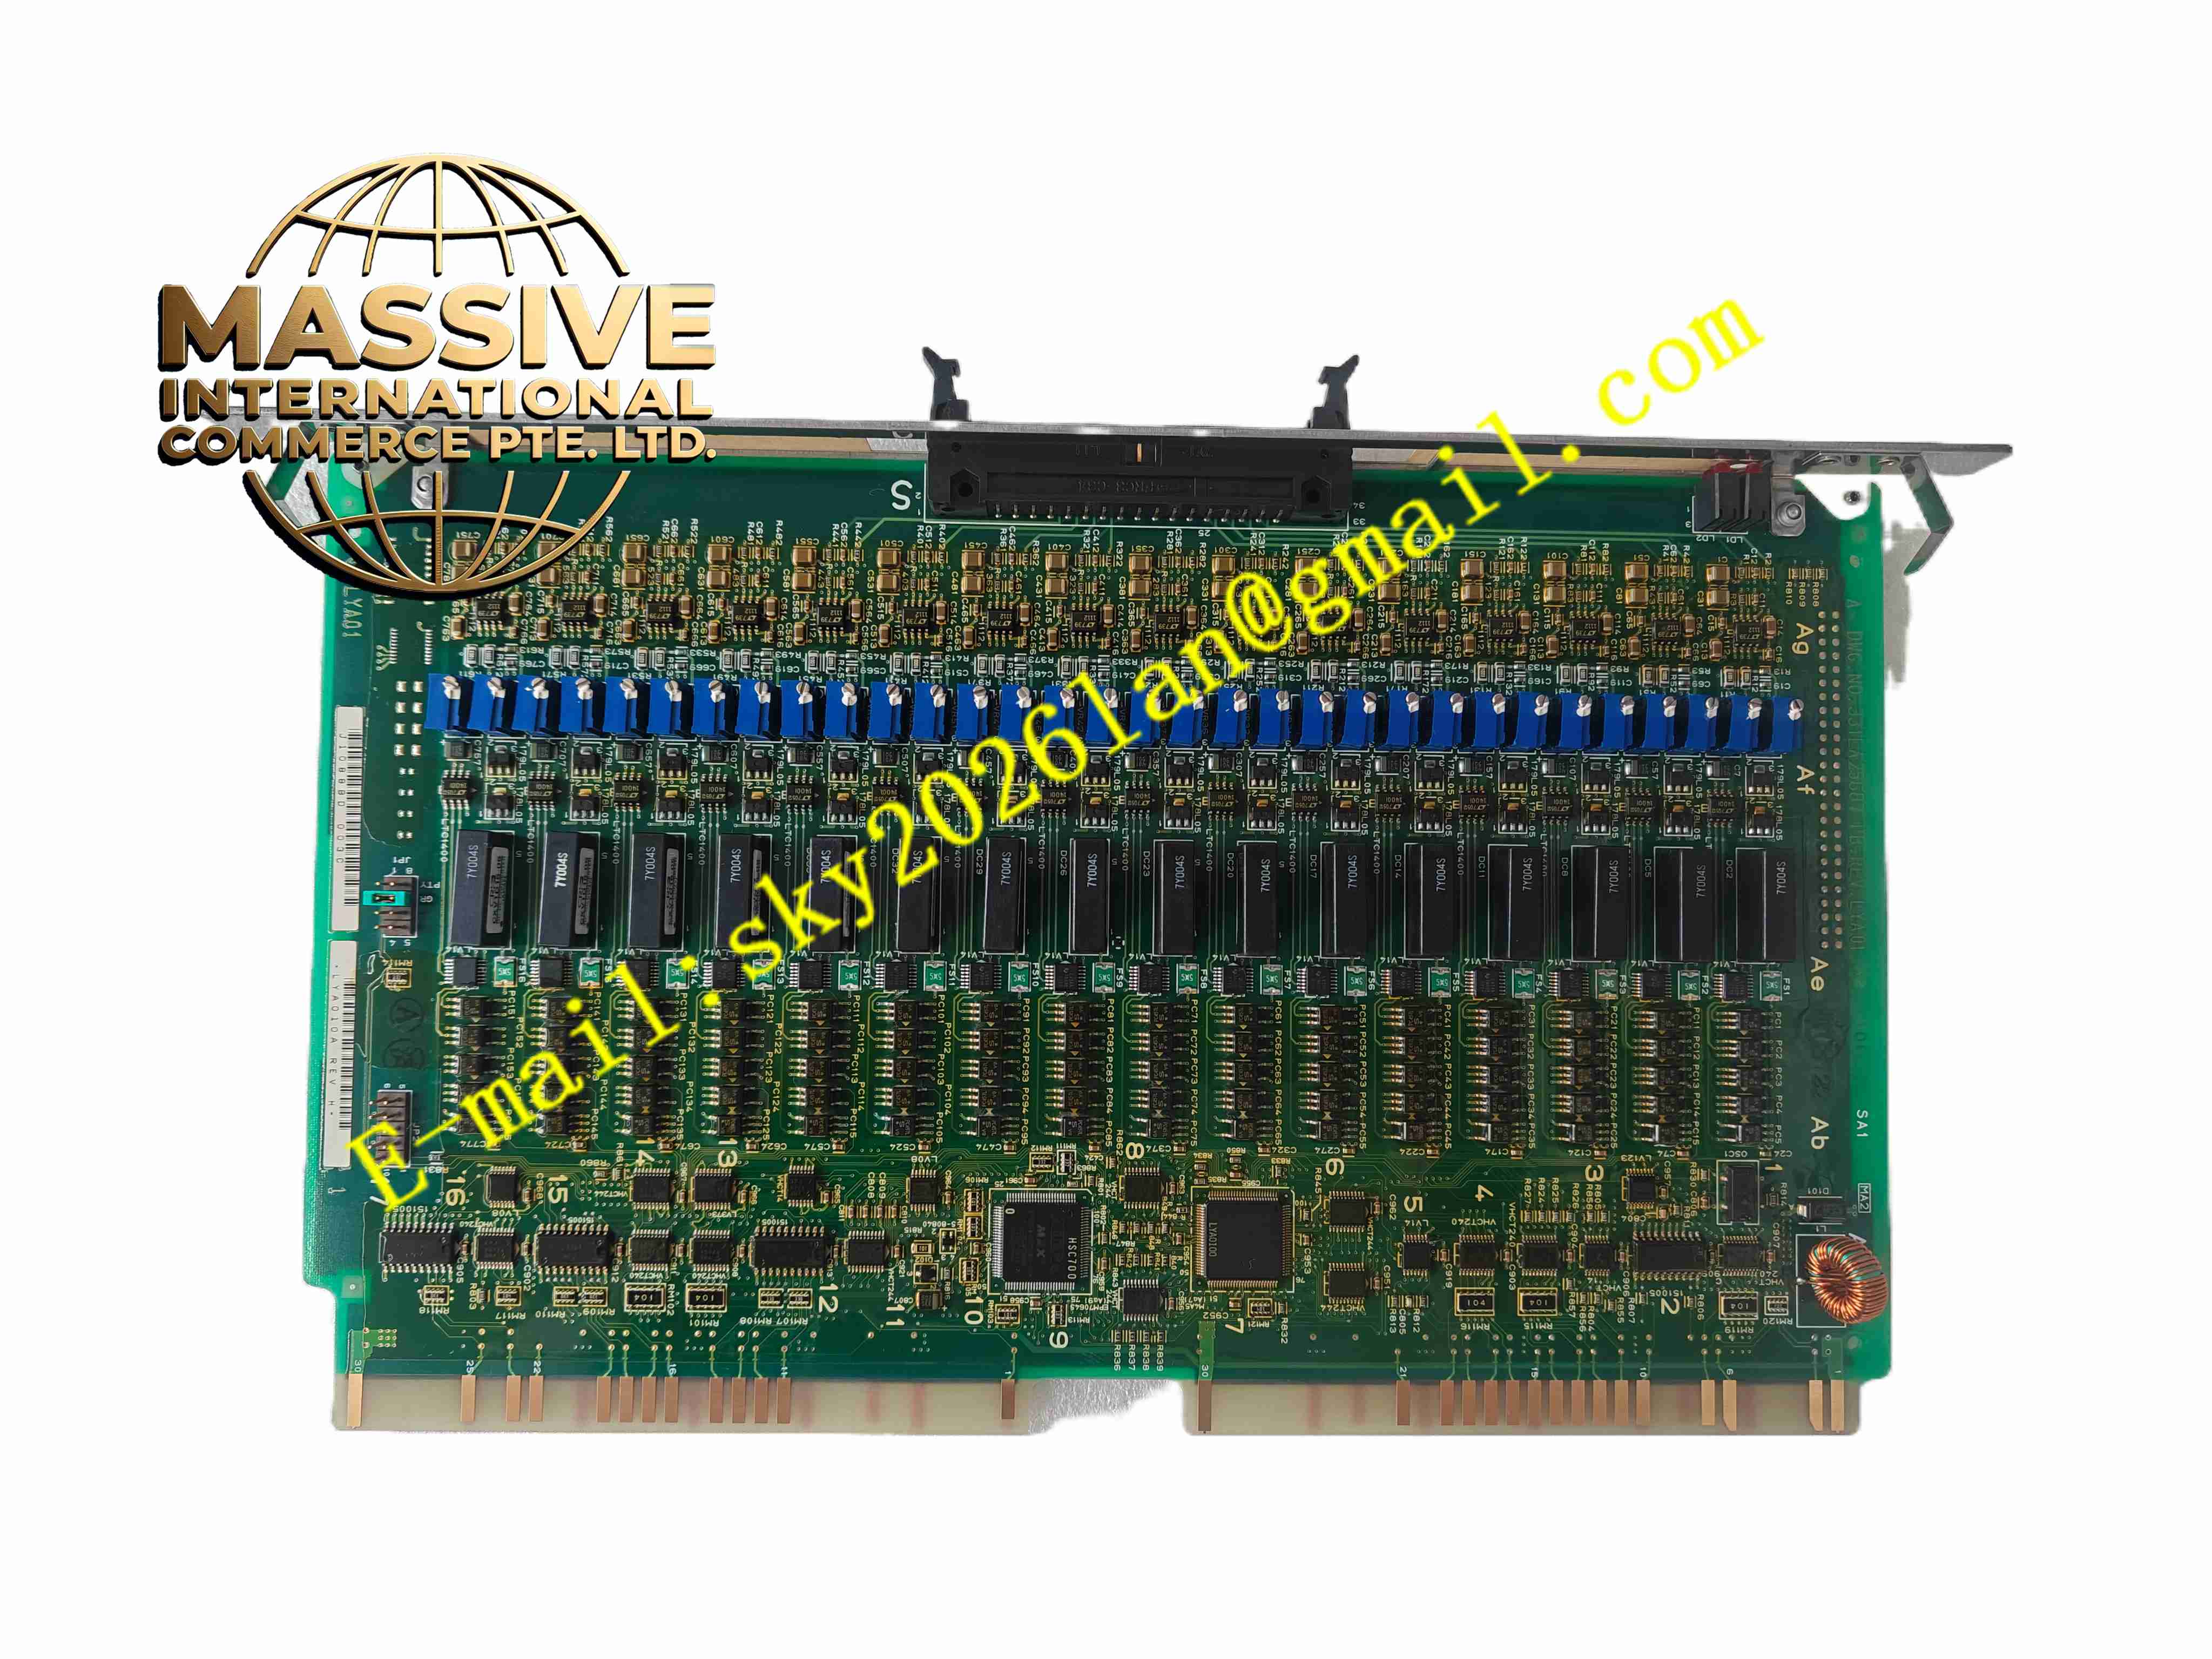
HITACHI LYA010A
Technical Specifications
Product type: servo drive
Compatible motors: Hitachi L-series servo motors
Input voltage: single-phase or three-phase AC 200 to 230 V, ±10 percent
Input frequency: 50/60 Hz
Output power: approximately 100 W class
Control modes: position control, speed control, torque control
Command input: pulse input, differential or open-collector
Encoder feedback: incremental encoder
Encoder resolution: approximately 2500 PPR, equivalent to 10000 pulses per revolution
Communication interface: RS-422/RS-485
Optional fieldbus: DeviceNet or MECHATROLINK with expansion card
Speed response frequency: 500 Hz or higher
Position repeatability: approximately ±1 pulse depending on encoder and system configuration
Functional Features
Multi-mode control including position, speed, and torque
Pulse command interface for PLC or motion controller integration
Incremental encoder feedback for closed-loop control
RS-422/RS-485 communication for parameter setting
Optional fieldbus expansion
Overcurrent, overvoltage, undervoltage, and overheat protection
Encoder fault detection
Compact low-power servo solution
Suitable for precision small-load motion applications
Application Scenarios
Small automated assembly equipment
Labeling machines
Sorting and indexing systems
Precision positioning mechanisms
Packaging machinery auxiliary axes
Light-load robotic or linear positioning stages
Test equipment and laboratory automation
OEM machines using Hitachi L-series servo motors
Performance Parameters
Power class: approximately 100 W
Control accuracy: high-resolution incremental encoder feedback
Position repeatability: approximately ±1 pulse
Speed response: 500 Hz or higher
Input supply: AC 200 to 230 V, 50/60 Hz
Command interface: pulse train input
Feedback interface: incremental encoder
Communication: RS-422/RS-485
Optional networks: DeviceNet, MECHATROLINK
Material Composition
Industrial plastic or metal drive housing
Power electronics PCB
Control PCB with microprocessor
Encoder interface circuitry
Pulse input interface circuit
Communication interface components
Terminal block connectors
Heat dissipation structure
Status indicator LEDs
Internal protection circuits
Structural Features
Compact servo drive form factor
Front or side wiring terminals
Encoder feedback connector
Pulse command input connector
RS-422/RS-485 communication port
Optional fieldbus expansion slot
LED status indicators
Mounting holes for panel or cabinet installation
Thermal management surfaces for heat dissipation
Working Principle
The LYA010A receives motion commands from a PLC or motion controller through pulse input or communication interface. It regulates motor current, voltage, and commutation to control the connected Hitachi L-series servo motor. Encoder feedback is continuously monitored to close the position, speed, or torque control loop. Internal protection functions monitor current, voltage, temperature, and encoder signals to prevent damage and provide fault diagnostics.
Installation Requirements
Match the drive to a compatible Hitachi L-series servo motor
Confirm input power is single-phase or three-phase AC 200 to 230 V
Connect motor power cables according to the wiring diagram
Connect the encoder cable securely to the feedback port
Wire pulse command signals with correct polarity and termination
Configure control mode and gain parameters before operation
Ensure adequate ventilation around the drive
Verify grounding and shielding for encoder and command cables
Confirm optional fieldbus cards are correctly installed if used
Usage Precautions
Do not operate with mismatched motor models
Verify input voltage phase and rating before power-on
Do not disconnect encoder cables during operation
Avoid exceeding the rated output power class
Check fault codes before resetting the drive
Use shielded cables for encoder and pulse signals
Keep the drive away from moisture, oil mist, and conductive dust
Perform tuning carefully to avoid instability
Replace only with Hitachi-approved equivalents