Description
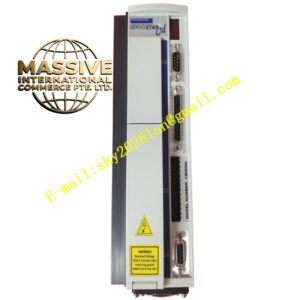
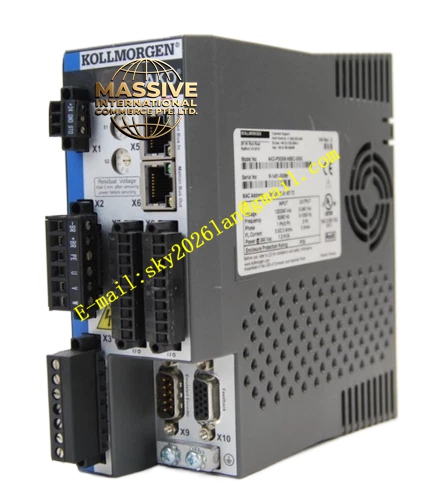
Kollmorgen AKD‑P00306‑NBEC‑0000
Technical Specifications: Single‑/three‑phase 120‑240 VAC input, 50‑60 Hz; auxiliary 24 VDC logic‑power‑supply; continuous output current 3 Arms RMS; peak output current 9 Arms for 5 seconds; DC‑bus voltage 160‑360 VDC; switching frequency 8 kHz; EtherCAT real‑time fieldbus interface; STO SIL3 / PLe safety‑function; supported feedback: resolver, SFD, SFD3, Hiperface, Hiperface‑DSL, EnDat, BiSS, incremental encoder; 7‑channel optically‑isolated digital‑input; 4‑channel optically‑isolated digital‑output; 1‑channel ±10 V analog‑input; 1‑channel ±10 V analog‑output; USB service‑interface for parameter‑configuration; encoder‑emulation output function; operating temperature 0‑45 °C; storage temperature‑25‑70 °C; humidity 5‑95 % RH non‑condensing; IP20 protection‑rating; DIN‑35 rail mounting; weight 1.1 kg; CE, UL, cUL, RoHS certifiedKollmorgen.
Functional Features: Full‑digital torque‑velocity‑position three‑loop closed‑loop motion‑control; motor auto‑identification and control‑loop auto‑tuning function; electronic‑cam, electronic‑gear and master‑slave synchronization function; encoder‑emulation output; plug‑and‑play for Kollmorgen SFD‑equipped motors; EtherCAT real‑time cyclic‑communication for multi‑axis coordinated‑motion; STO hardware safety‑channel for safe‑torque‑off; comprehensive hardware‑protection covering over‑current, over‑voltage, under‑voltage, over‑temperature, feedback‑signal‑loss; multi‑LED status‑indicator for fault‑diagnosis; parameter‑storage inside drive non‑volatile‑memory; support AKD Workbench configuration‑software for commissioning and diagnosis.
Application Scenarios: Small‑size packaging‑machinery, electronic‑assembly‑equipment, desktop test‑platforms, miniature‑robot axes, semiconductor‑handling‑mechanisms, multi‑axis compact‑automation‑systems based on EtherCAT fieldbus.
Performance Parameters: Current‑loop update‑cycle 0.625 μs; velocity‑loop update‑cycle 125 μs; position‑loop update‑cycle 250 μs; current‑loop bandwidth up to 4 kHz; velocity‑loop bandwidth up to 1000 Hz; position‑loop bandwidth up to 250 Hz; 300 % short‑term peak‑overload capacity for 5 seconds; fast hardware‑fault‑detection and safe‑state transition capabilityKollmorgen.
Material Composition: Flame‑retardant plastic DIN‑rail‑mount housing; high‑power IGBT power‑module; gold‑plated industrial‑grade signal‑and‑power‑connectors; high‑voltage flame‑retardant PCB circuit‑board; metal heat‑sink fin‑assembly; multi‑channel status‑LED indicator‑array; EtherCAT RJ45 transceiver‑module; USB service‑port assembly; opto‑coupler isolation‑components for digital‑I/O circuits.
Structural Features: Compact book‑style DIN‑35 rail‑mount housing; front‑panel multi‑color LED status‑indicator lights; front‑side USB service‑interface; lateral EtherCAT RJ45 communication‑ports; rear‑side power‑input terminals, motor‑output connector, feedback‑connector, analog‑digital I/O terminals; built‑in metal heat‑sink for convection‑cooling without internal‑fan; rear‑side DIN‑rail locking‑clip for fast cabinet‑installation.
Working Principle: Single‑or three‑phase AC input‑power passes internal rectifier‑circuit and converts into DC‑bus high‑voltage DC‑power. IGBT inverter‑circuit outputs three‑phase variable‑frequency sinusoidal current to drive matched AKM‑series servo‑motor. Motor feedback‑signal transfers to drive DSP control‑chip, completes high‑speed three‑loop closed‑loop algorithm‑calculation. Motion‑commands are received from upper‑level EtherCAT‑master controller. Hardware safety‑circuit implements STO safe‑torque‑off function. Internal monitoring‑circuits continuously sample current, bus‑voltage and internal‑temperature, trigger power‑stage shutdown once fault‑condition is detected.
Installation Requirements: Vertically mount on standard DIN‑35 rail inside IP20‑rated industrial‑control‑cabinet; maintain 25 mm upper‑lower ventilation‑clearance and 10 mm left‑right clearance; separate high‑power motor‑cable routing and signal‑communication‑cable routing with physical‑spacing; EtherCAT‑bus adopts shielded industrial‑Ethernet‑cable with single‑end shield‑grounding; reliably connect drive protective‑earth terminal to cabinet grounding‑bar; strictly comply with IEC‑61508 safety‑standard for STO safety‑circuit wiring; auxiliary 24 VDC logic‑power‑supply must adopt independent power‑source; forbid mixing‑routing power‑cables and signal‑cables inside same cable‑duct without partition.
Usage Notes: Do not perform hot‑swap of communication‑connectors and feedback‑connectors under powered‑on‑state; DC‑bus still stores high‑voltage energy after main‑power‑off, wait for full‑discharge before opening cabinet‑for‑maintenance; ambient operating‑temperature shall not exceed 45 °C; keep heat‑sink surface free of dust‑accumulation; complete motor‑parameter‑configuration via AKD Workbench software before first‑time power‑on; spare‑part replacement must verify hardware‑revision and firmware‑version‑compatibility; EtherCAT‑bus terminal‑resistor must be correctly configured at bus‑two‑ends for long‑distance‑wiring‑scenarios.