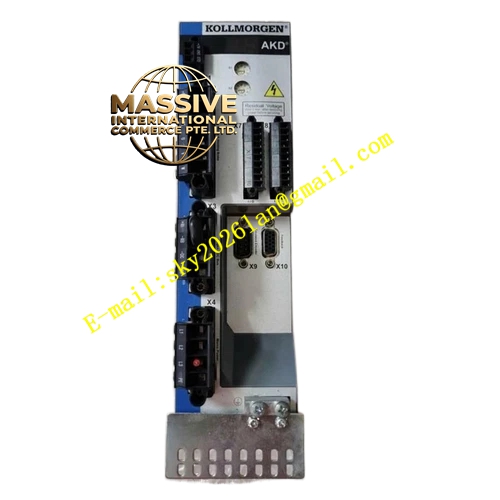
Description
Kollmorgen AKD-P00607-NBPN-0000
Technical Specifications
- Series: AKD Series Digital AC Servo Drive
- Drive Variant: Position Indexer (AKD-P Motion Tasking Drive)
- Continuous Output Current: 6.0 Amps RMS
- Peak Output Current: 18.0 Amps RMS for 5 seconds
- Rated Supply Voltage: 240 VAC to 480 VAC, three-phase, 50/60 Hz
- DC Bus Voltage Range: 300 VDC to 680 VDC
- Rated Active Output Power: Up to 4.0 kW
- Communication Protocol: EtherCAT real-time Ethernet with SDO and PDO messaging
- Control Modes: Torque, velocity, and position modes with electronic gearing and camming
- Feedback Support: Resolver, EnDat 2.2, Hiperface, BiSS, SFD, incremental encoder
- Safety Function: Safe Torque Off (STO) integrated
- Cooling: Natural convection or forced air cooling depending on installation density
- Operating Temperature: 0 degrees Celsius to plus 45 degrees Celsius with derating to plus 55 degrees Celsius
- Protection Rating: IP20 for control cabinet installation
- Dimensions: Approximately 45 millimeters by 125 millimeters by 180 millimeters
- Weight: Approximately 0.9 kilograms
Functional Features
- Real-time EtherCAT master/slave functionality for high-speed deterministic multi-axis synchronization
- Position Indexer firmware stores and executes multi-step motion profiles directly on the drive
- 2.5 kilohertz current loop bandwidth suppressing mechanical resonance
- Universal multi-feedback evaluation accommodating absolute encoders, incremental encoders, resolvers, and Smart Feedback Devices
- Integrated line filter and regenerative resistor controls
- Eight digital inputs, three digital outputs, one 16-bit analog input, and one 16-bit analog output
- Plug-and-play commissioning with automatic motor parameter identification
Application Scenarios
- High-speed packaging machinery and labeling applicators
- Semiconductor manufacturing equipment
- Rotary indexing tables
- Electronic component inserters and sorting networks
- General industrial motion control requiring 480V position indexing and EtherCAT integration
Performance Parameters
- Current loop bandwidth of 2.5 kilohertz ensures effective mechanical resonance suppression
- Positioning repeatability within plus or minus one pulse equivalent
- 3:1 peak-to-continuous current ratio delivers rapid dynamic acceleration torque
- Stable operation under 120 percent overload conditions with temperature rise controlled within 35 Kelvin
Material Composition and Structure
- Aluminum heatsink chassis with compact industrial enclosure
- Industrial-grade power electronics and conformal coated circuit boards
- Detachable screw terminals for power, brake, and input/output connections
- RJ45 connectors for EtherCAT network interface
- Status LEDs for operational state monitoring
Working Principle The drive receives motion commands through the EtherCAT fieldbus interface or internal motion tasking programs. Digital signal processors execute current, velocity, and position loop algorithms at high update rates. The three-phase PWM inverter stage converts DC bus voltage into precisely controlled sinusoidal current for brushless servo motors. Feedback devices provide closed-loop position and velocity information, enabling accurate trajectory following and disturbance rejection.
Installation Requirements
- Mount in ventilated electrical enclosure with IP20 protection minimum
- Connect to 240/480 VAC three-phase supply with proper overcurrent protection
- Use shielded cables for motor power and feedback connections
- Install EtherCAT network with proper termination at both ends
- Maintain adequate clearance around heatsink for thermal dissipation
Operating Precautions
- Verify input voltage compatibility before energizing
- Configure motor parameters to match connected servo motor ratings
- Monitor thermal status during sustained peak current operation
- Maintain backup of motion task programs and parameter settings before modifications