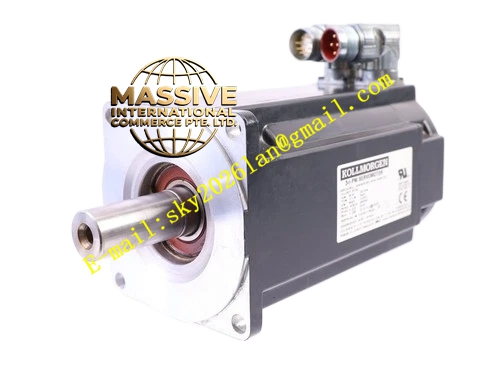
Description
Kollmorgen AKM43E-ANCNR-00
Technical Specifications:
- Frame Size: AKM4 (130mm flange diameter)
- Stack Length: 3 (medium stack)
- Winding Type: E winding
- Feedback Device: Resolver (R designation)
- Connector Type: C (0.5m shielded cable with IP65 connector)
- Brake: N (no brake)
- Shaft: R (standard shaft)
- Seal: 00 (standard IP54 motor)
- Continuous Current (Ics): 2.76 Arms
- Stall Torque (Tcs): 4.7 Nm
- DC Bus Voltage: 640 VDC
- Rated Speed (Nrtd): 3000 RPM
- Rated Power (Prtd): 1.18 kW
- Phase Resistance (L-L): 8.61Ω at 25°C
- Ambient Temperature: 40°C
- Protection Rating: IP54
- Insulation Class: F
- Certifications: CE, EN60034
Functional Features:
- Resolver feedback providing robust position sensing in harsh environments
- High torque density within a compact AKM4 frame
- Low cogging torque for smooth low-speed operation
- Compatible with Kollmorgen AKD and SERVOSTAR series drives
- Plug-and-play motor identification for rapid commissioning
- Full-frequency auto-tuning on AKD drives
Application Scenarios:
- Industrial automation with vibration-prone environments
- Machine tool spindle and feed drives
- Robotic arm joint actuators
- Material handling systems
- Textile and printing machinery
- General-purpose servo positioning applications
Performance Parameters:
- Continuous Torque: 4.7 Nm at stall
- Peak Torque: Within AKM4 frame specifications
- Rated Speed: 3000 RPM
- Rated Power: 1.18 kW
- Continuous Current: 2.76 Arms
- Thermal Time Constant: Designed for 100°C temperature rise above 40°C ambient
Material Composition:
- Silicon steel laminated stator core
- NdFeB permanent magnet rotor
- Aluminum alloy housing
- Class F insulation winding
- Resolver stator and rotor elements
- Precision ball bearings
Structural Features: Cylindrical motor body with 130mm diameter flange. The resolver is mounted at the rear of the motor, providing absolute position feedback without requiring a battery backup. The 0.5m shielded cable exits from the motor rear with an IP65-rated connector. The shaft is a standard round shaft without keyway.
Working Principle: The resolver feedback device operates on the principle of electromagnetic induction. A rotor winding excited by a reference signal induces voltages in two stator windings (sine and cosine) that vary proportionally with the rotor angle. The servo drive decodes these signals to determine the absolute rotor position, enabling precise field-oriented control of the permanent magnet synchronous motor.
Installation Requirements:
- Mount using standard AKM4 flange mounting pattern
- Ensure proper cable routing with minimum bend radius for the resolver cable
- Use shielded cables and proper grounding for resolver signal integrity
- Provide adequate ventilation around the motor housing
- Verify drive compatibility with resolver feedback type before commissioning
Usage Precautions:
- Handle the resolver with care to avoid damaging the precision electromagnetic elements
- Verify resolver excitation frequency matches drive requirements
- Monitor motor temperature during continuous operation at rated torque
- Use Kollmorgen WorkBench software for motor parameter configuration
- Ensure the motor is properly grounded through the mounting flange
- Check cable connections periodically for loosening due to vibration