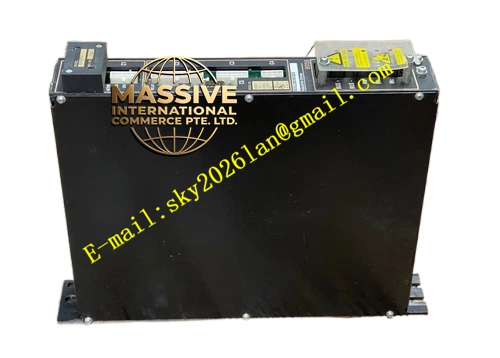
Description
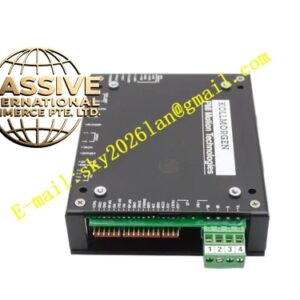
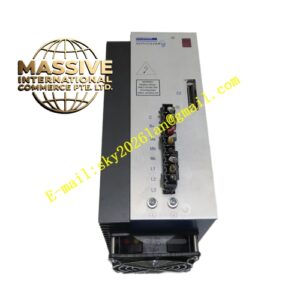
Kollmorgen BDS5T-203-0010-101205A2-041P
Technical Specifications
- Main DC Bus Voltage: 225 VDC minimum to 360 VDC maximum
- Unregulated Logic Bus: ±15 to 20 VDC at 0.25 Amps; +8 to 12 VDC at 1.00 Amp
- Continuous Output Current: 3.0 Amps RMS at 45°C ambient with convection cooling
- Peak Output Current: 6.0 Amps RMS for 2.0 seconds duration
- Output Power at 160 VDC Bus: 1.2 KVA continuous; 2.4 KVA peak
- Internal Heat Dissipation: 35 Watts maximum
- Control Modes: Torque loop, velocity loop, and position loop with three-closed-loop control architecture
- Programming: Built-in high-level motion programming language with multitasking capability
Functional Features
- Standalone programmable motion controller with 6 task levels including alarm handling, variable input, main program, and background tasks
- S-curve acceleration profiling with 5 selectable curve types from straight-line to sinusoidal
- Electronic gearbox functionality for master/slave synchronization
- Registration and capture capabilities for high-speed marking applications
- Macro move commands for complex motion sequences
- Software travel limits and hardware overtravel protection
- Autobauding RS-232 serial communication up to 19.2 kbps
- Resolver-to-digital conversion with 12-bit, 14-bit, or 16-bit resolution options
- Encoder feedback support for incremental encoders
- General purpose I/O for machine interfacing
Application Scenarios
- Standalone single-axis positioning systems
- Flying shear and cutoff applications
- Rotary indexing tables
- Web handling and tension control
- Automated assembly equipment
- Test and measurement platforms requiring programmable motion profiles
Performance Parameters
- Position loop update rate optimized for high servo stiffness
- Velocity loop with proportional and integrating compensation
- Current command mode where motor torque is directly proportional to command signal at lower speeds
- Foldback current limiting for motor thermal protection
- Adjustable current limits with continuous monitoring
Material Composition and Structure
- Steel and aluminum chassis construction with integrated power electronics
- Isolated logic and power sections for noise immunity
- Modular compensation board architecture
- Heavy-duty terminal blocks rated for industrial power levels
- LED status indicators for operational state monitoring
Working Principle The drive operates by receiving command inputs through serial communication or internal program execution. The processor calculates motion profiles and generates current commands for the three-phase PWM output stage. Motor position feedback from resolver or encoder is compared against commanded position to generate error signals. The control algorithm processes position, velocity, and current loops sequentially to produce smooth, accurate motion. In torque mode, the velocity feedback loop is bypassed and current command is derived directly from the torque command input multiplied by the proportional gain constant.
Installation Requirements
- Install in NEMA-rated electrical enclosure with minimum IP54 protection
- Maintain 6-inch clearance around heatsink for natural convection
- Connect external regeneration resistor kit if duty cycle exceeds internal dissipation capacity
- Use Kollmorgen PSR4/5 connector kits for proper motor and feedback cable termination
- Configure autobaud communication before applying motor power
Operating Precautions
- Only qualified personnel should install, set up, and operate this equipment
- Ensure all system components including motor and drive are properly grounded
- Verify DC bus polarity before connection as reverse polarity causes permanent damage
- Do not operate without proper motor feedback connected
- Monitor internal temperature during extended peak current operation
- Back up all motion programs before firmware updates