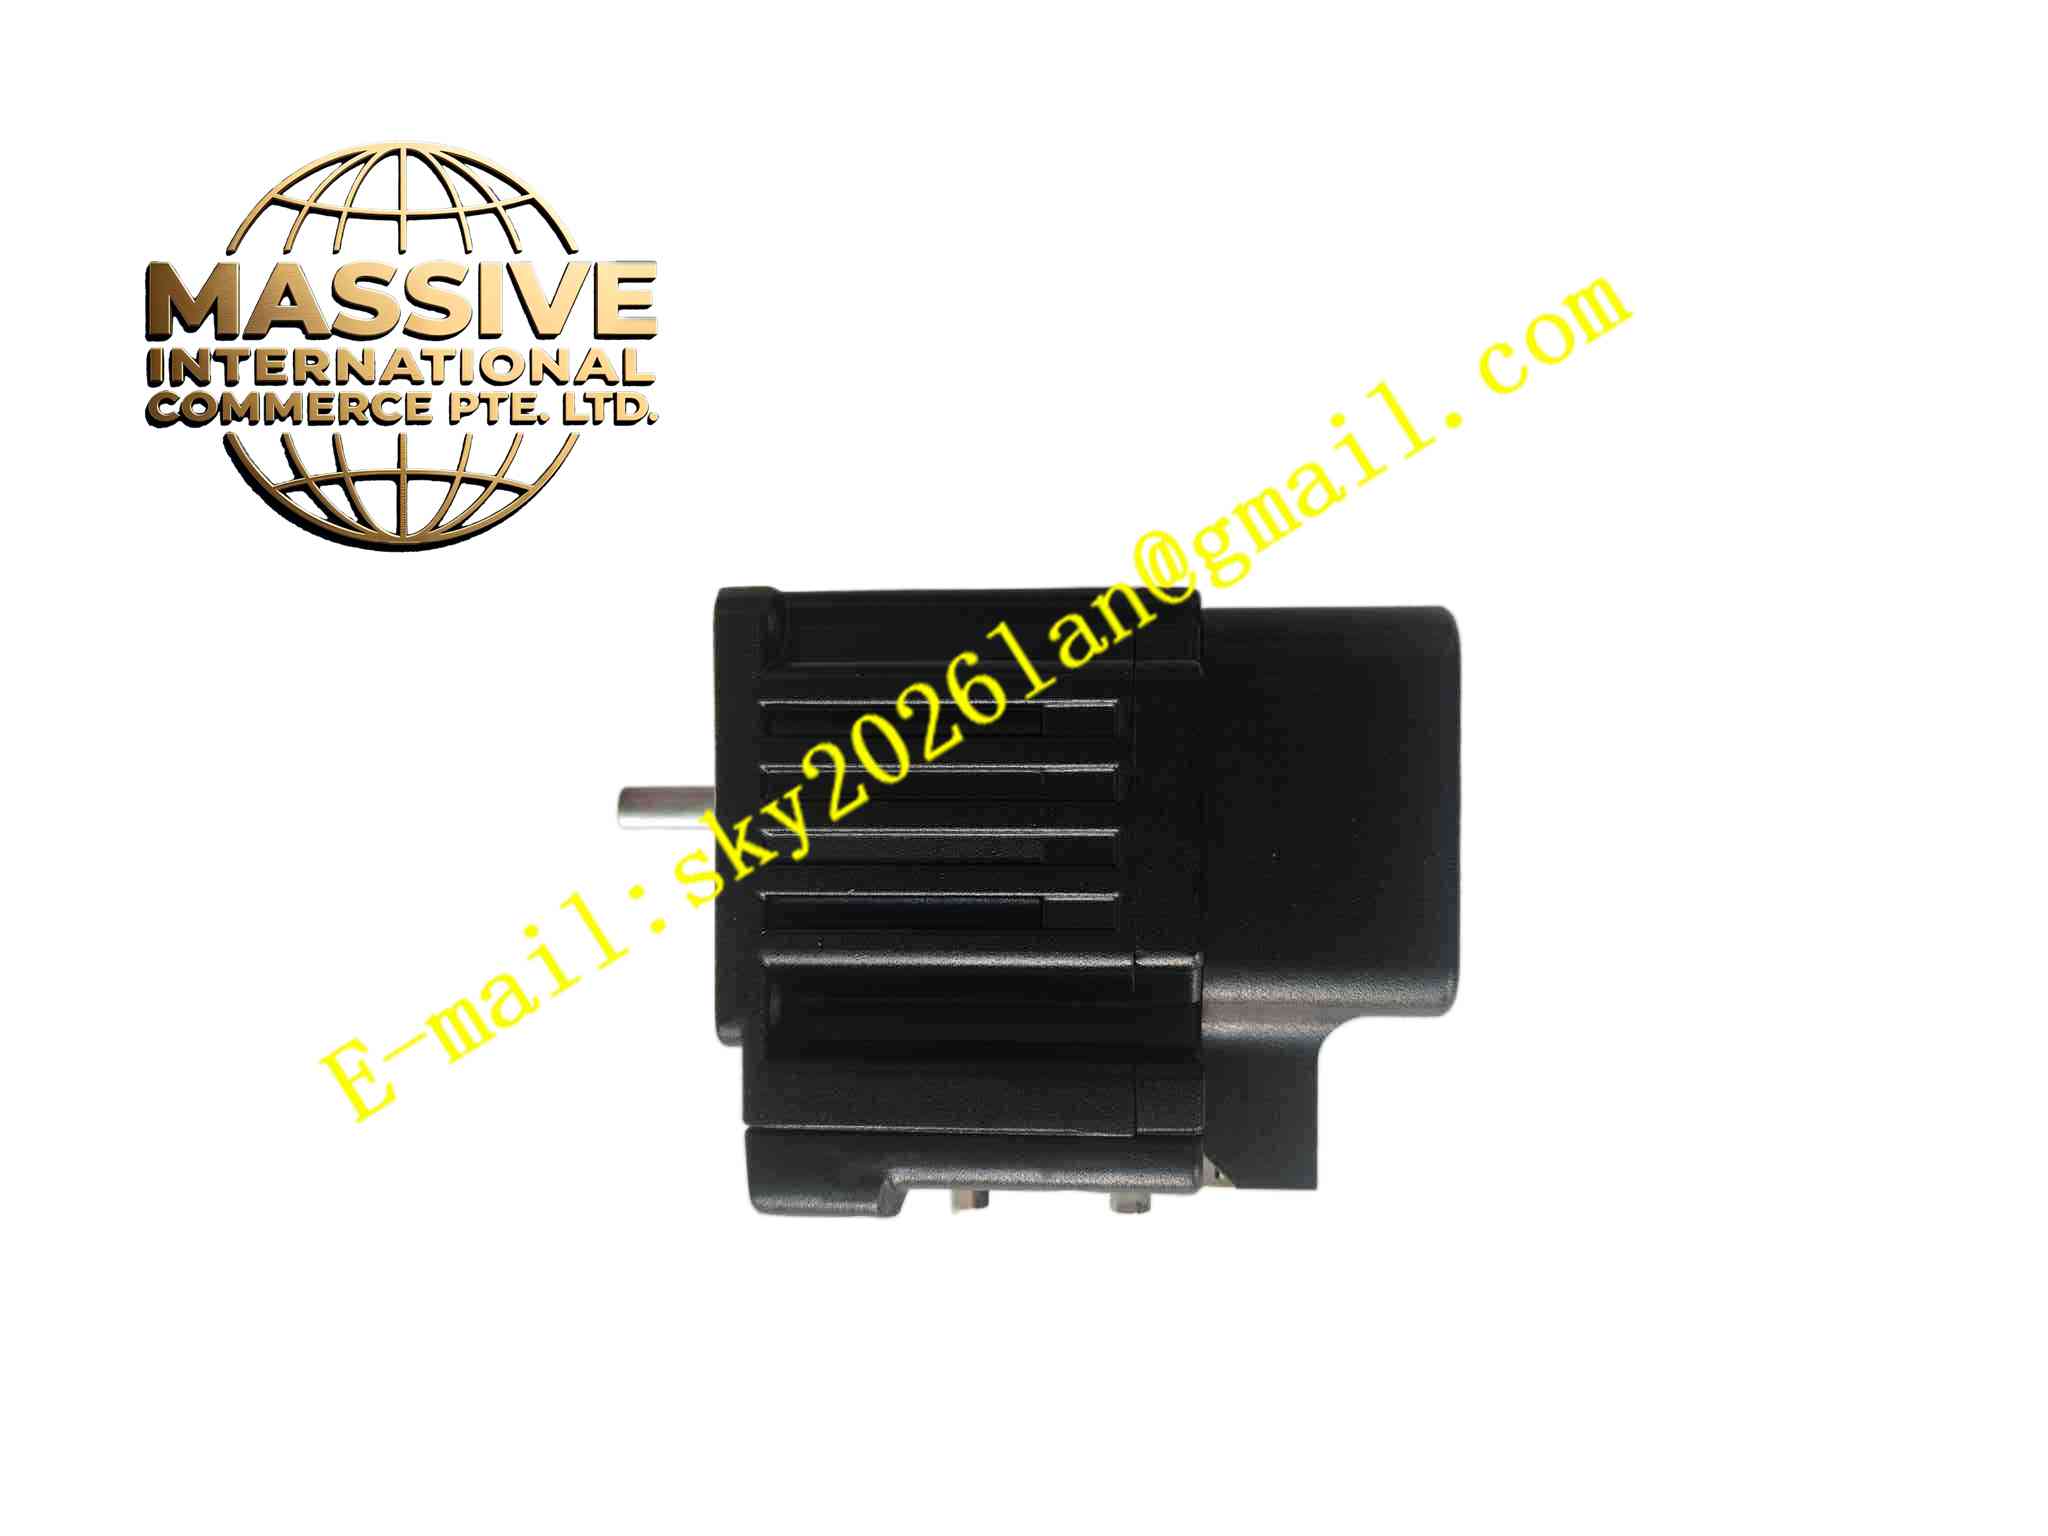
Description
Moog SM2315DT-BRKETH
Technical Specifications
- Product type: Integrated smart servo motor
- Frame size: NEMA 23
- Rated power: Corresponding to SmartMotor class
- Supply: DC24 V to 48 V
- Communication: Ethernet
- Feedback: Integrated encoder
- Brake: Integrated electromagnetic brake
- Control: Built-in motion controller
- Operating temperature: 0 °C to +40 °C
- Storage temperature: -20 °C to +70 °C
- Humidity: 5 % to 95 %, non-condensing
- Protection: IP40
- Mounting: Face mount
- Connectors: Power and Ethernet
Functional Features
- Integrated motor, drive, and controller in one housing
- Ethernet communication
- Integrated electromagnetic brake
- Built-in programmable motion controller
- Single cable power and network
- Auto-tuning servo loops
- Position, velocity, and torque modes
- Multi-axis synchronization over network
- Compact NEMA 23 package
- No separate drive cabinet required
Application Scenarios
- Medical device motion axis
- Semiconductor handling equipment
- Laboratory automation
- Small 3D printer and CNC
- Packaging and dispensing machine
Materials and Construction
- Housing: Aluminum
- Rotor: Permanent magnet
- Stator: Copper winding
- Encoder: Optical magnetic encoder
- Brake: Electromagnetic disc brake
- Connectors: Industrial round connectors
Structural Features
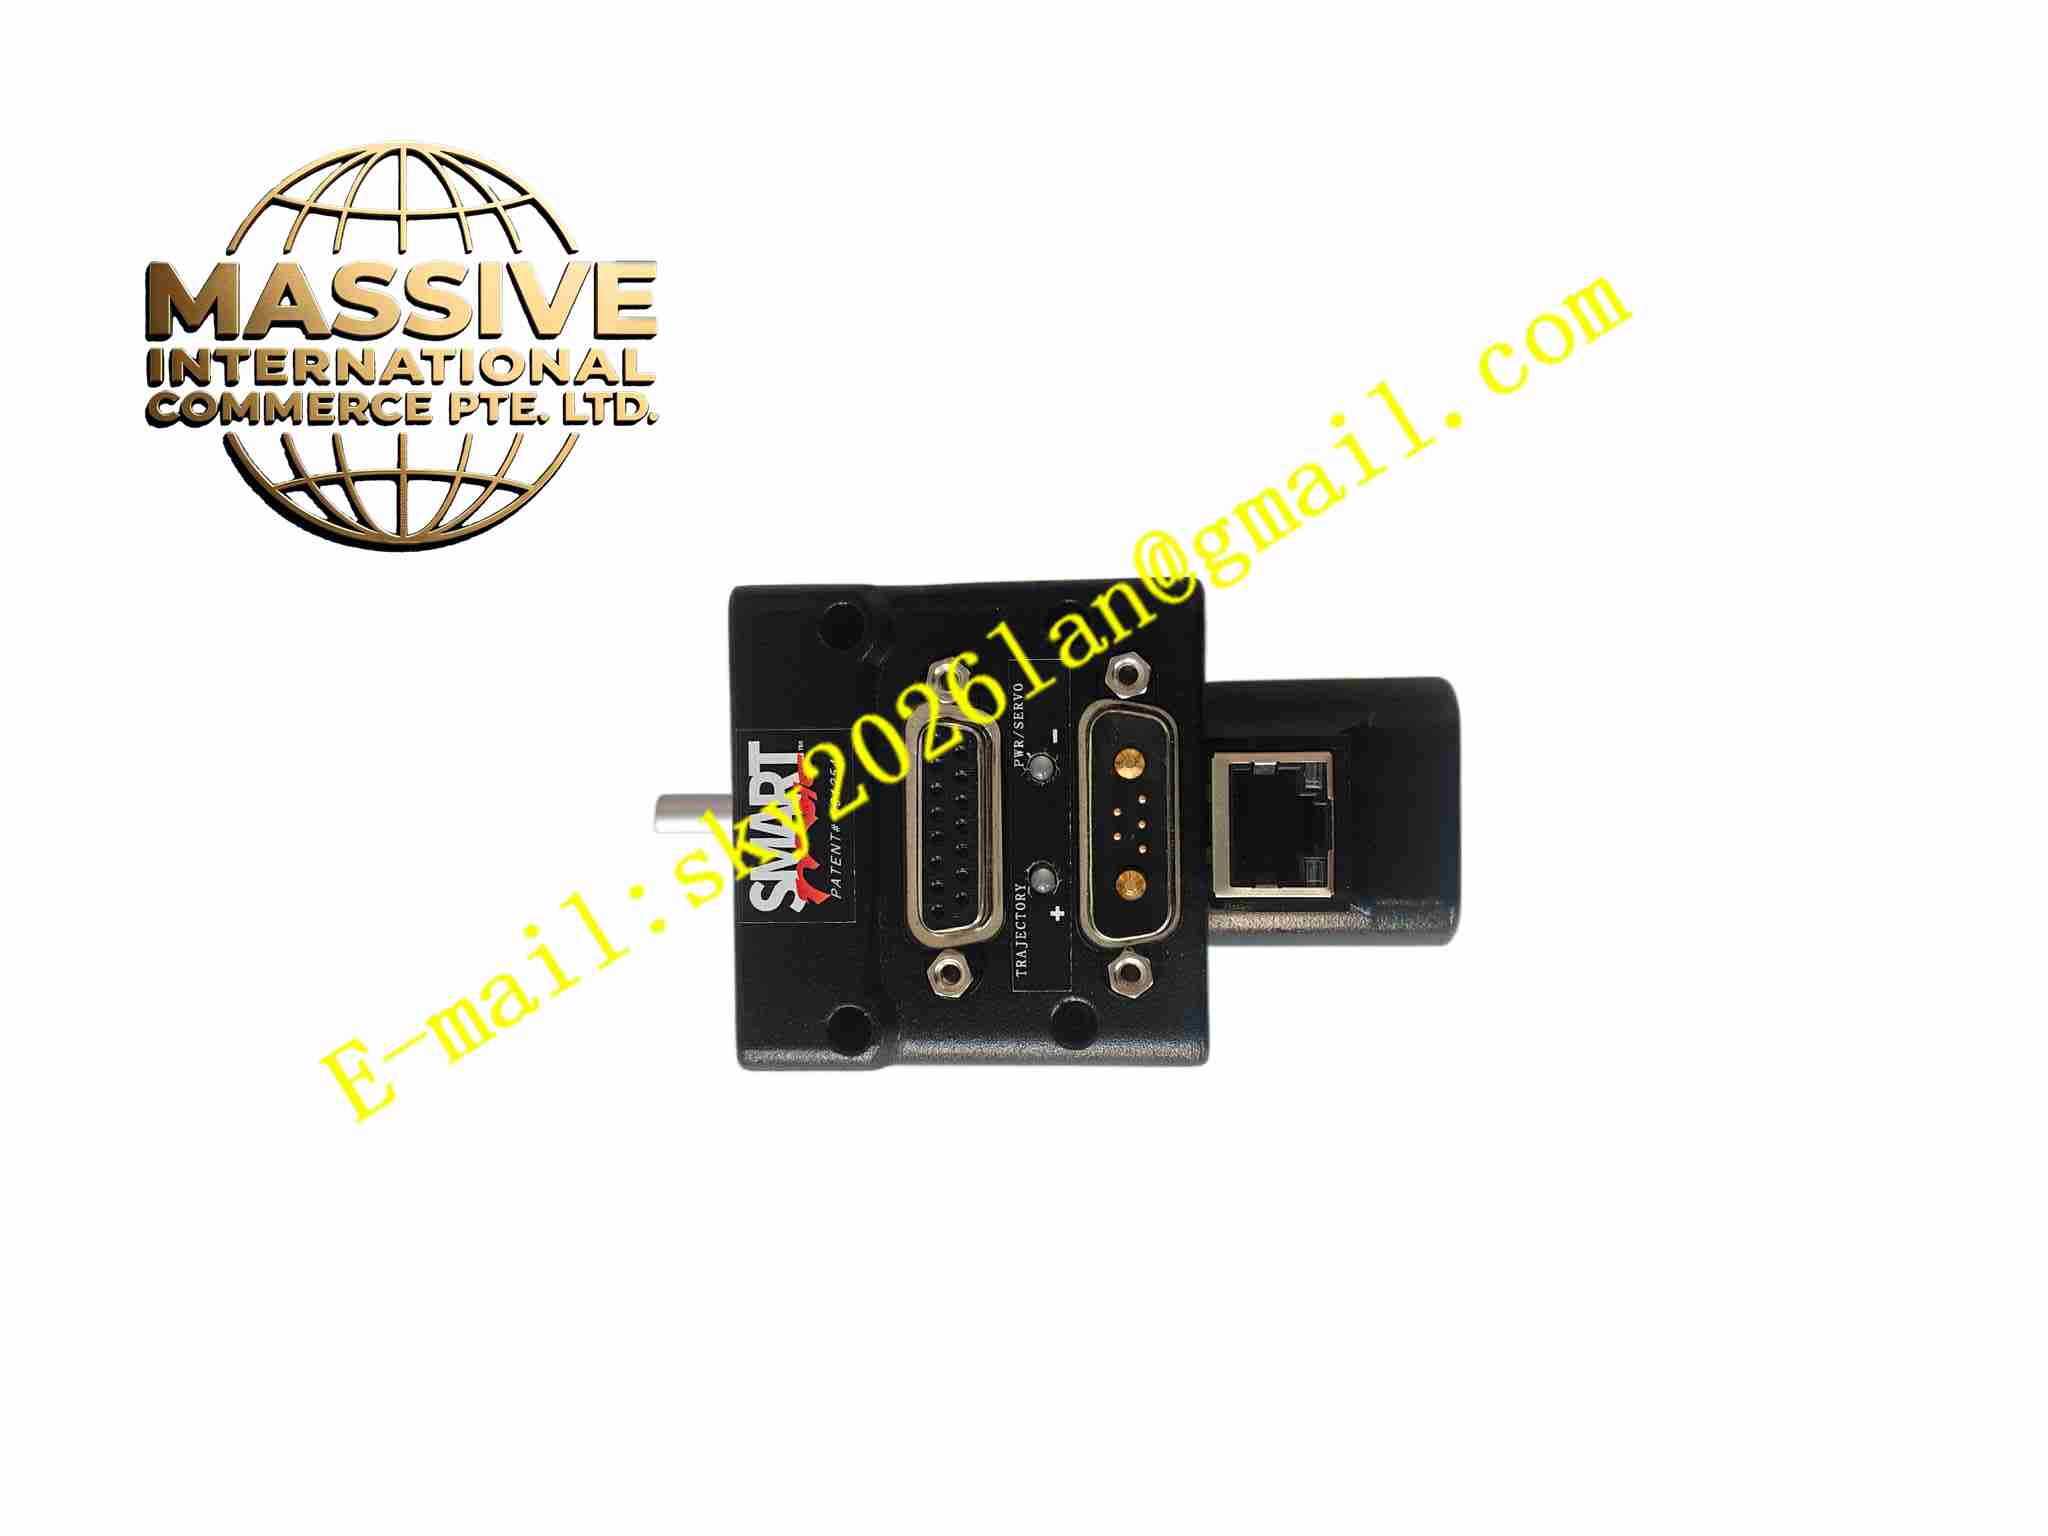
- Cylindrical aluminum NEMA 23 motor
- Rear integrated drive and controller electronics
- Integrated brake at rear or shaft end
- Side power and Ethernet connectors
- Front output shaft
- Fully integrated sealed housing
Working Principle DC power enters integrated drive electronics inside motor. Controller executes motion program from host over Ethernet. Drive outputs current to motor windings. Encoder feedback closes position and velocity loops. Brake engages when power removed to hold shaft.
Installation Requirements
- Face mount motor
- Connect DC power cable
- Connect Ethernet network cable
- Ground shield
- Temperature 0 °C to +40 °C
- Configure motor address and motion program after power-up
- Align coupling
- Reserve cooling space
Precautions
- DC voltage must match rating
- Do not disable brake holding function
- Ethernet cable shield grounded
- Avoid motor overheating
- Store spares in anti-static packaging
- Do not open rear electronics cover
- Check brake holding torque after long service