



Description
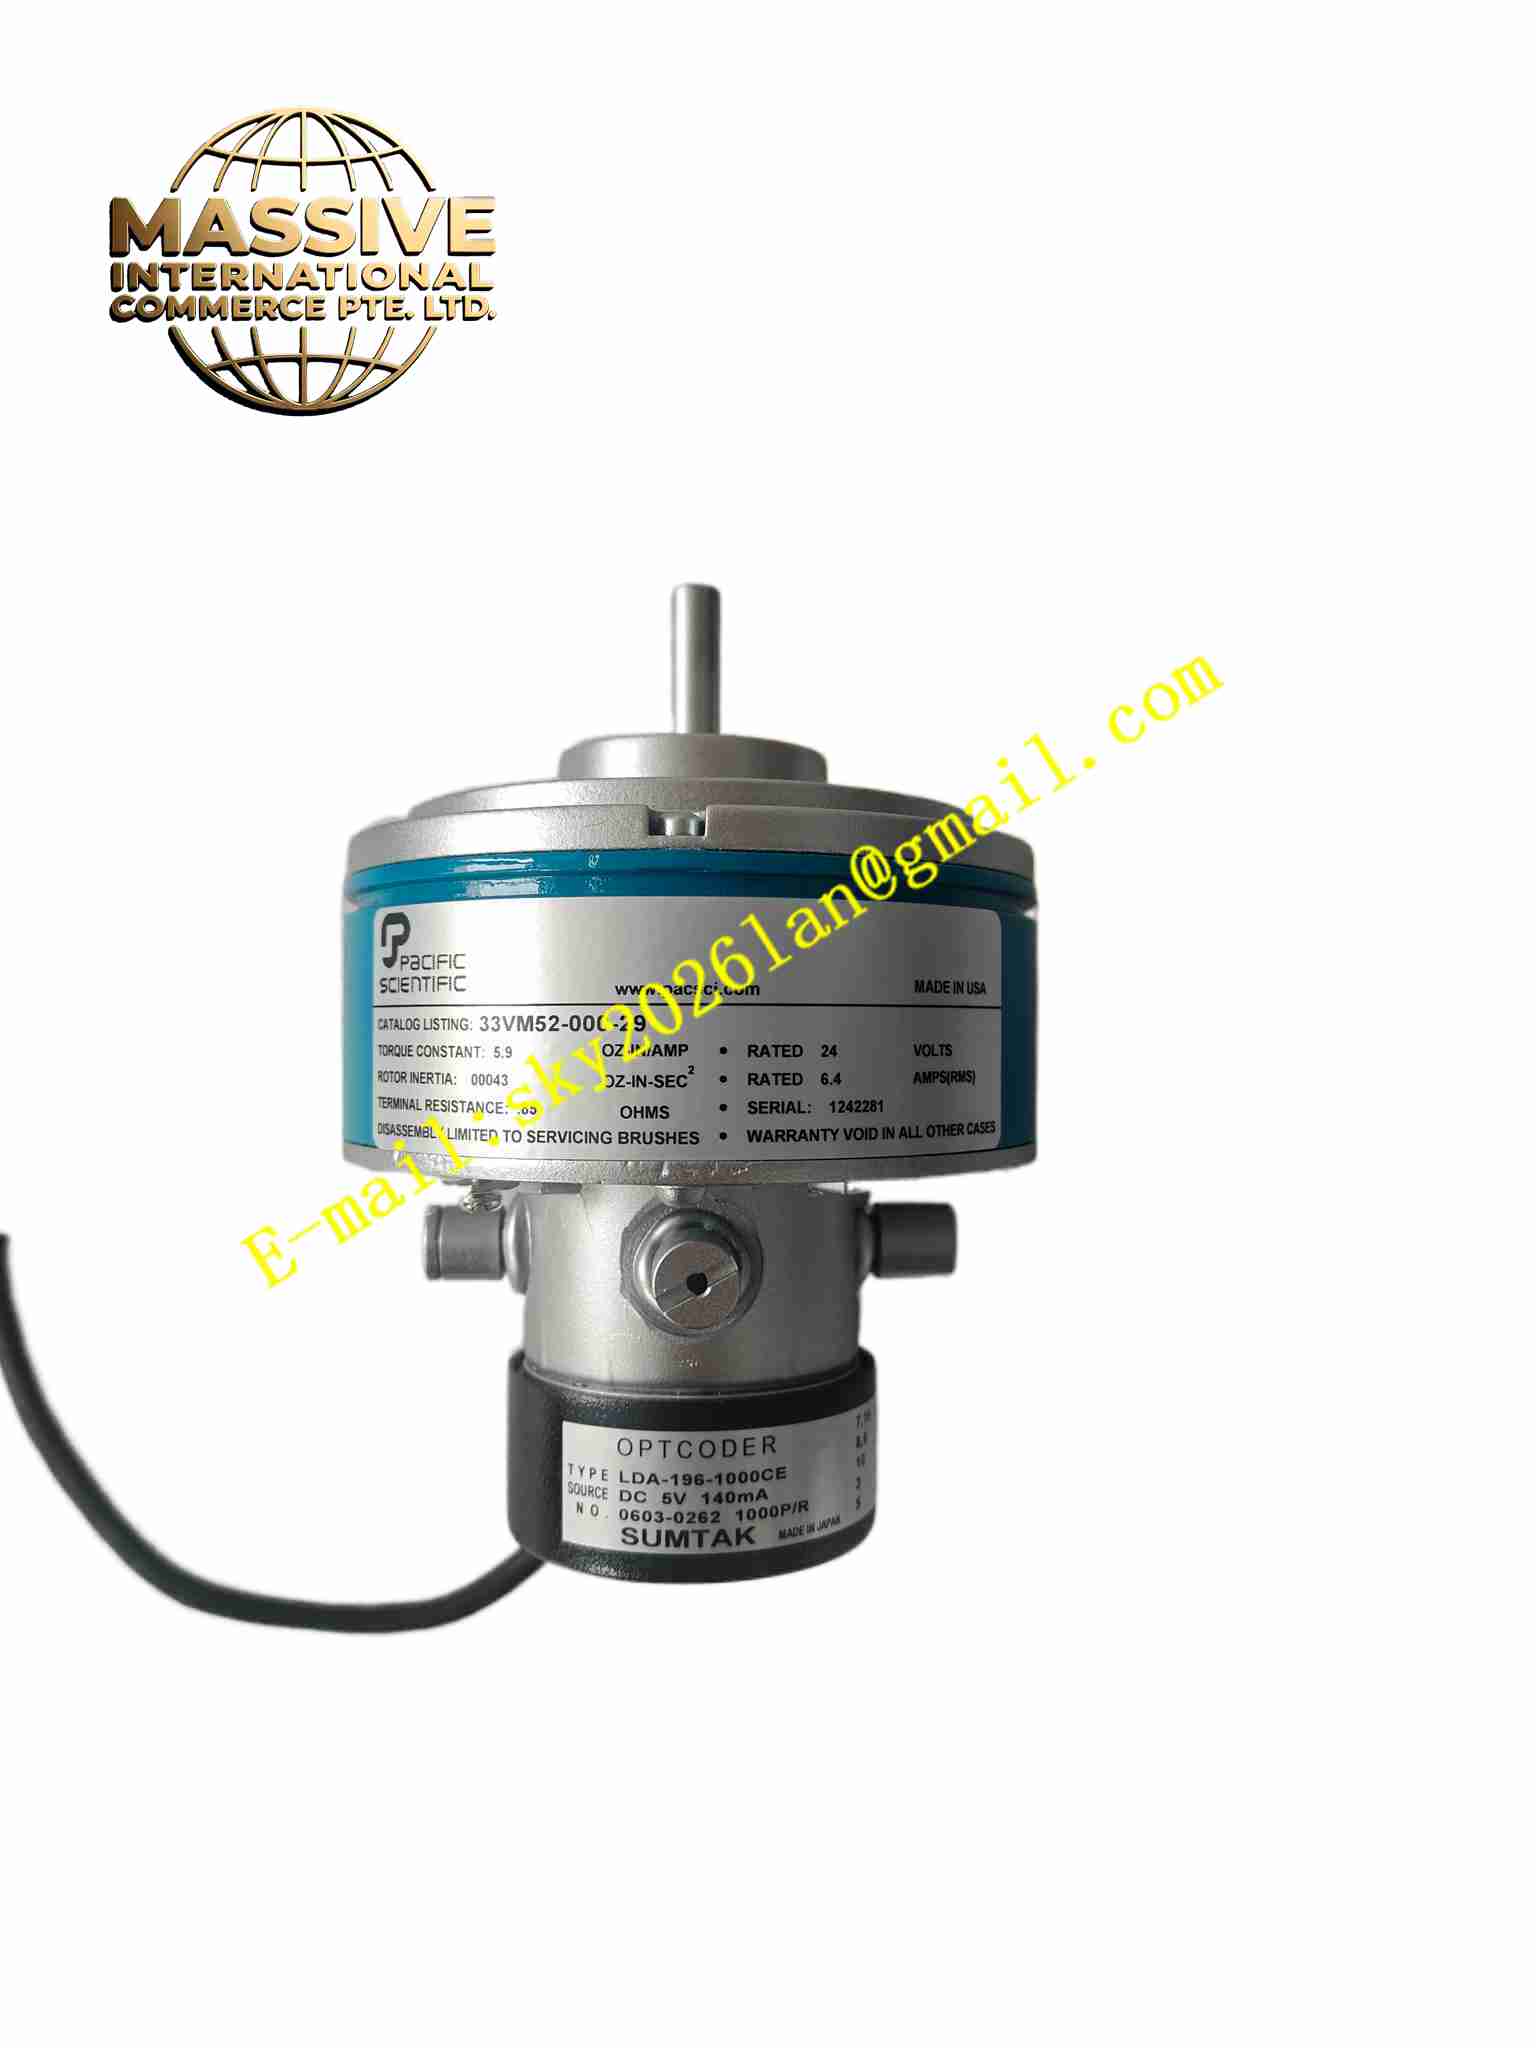
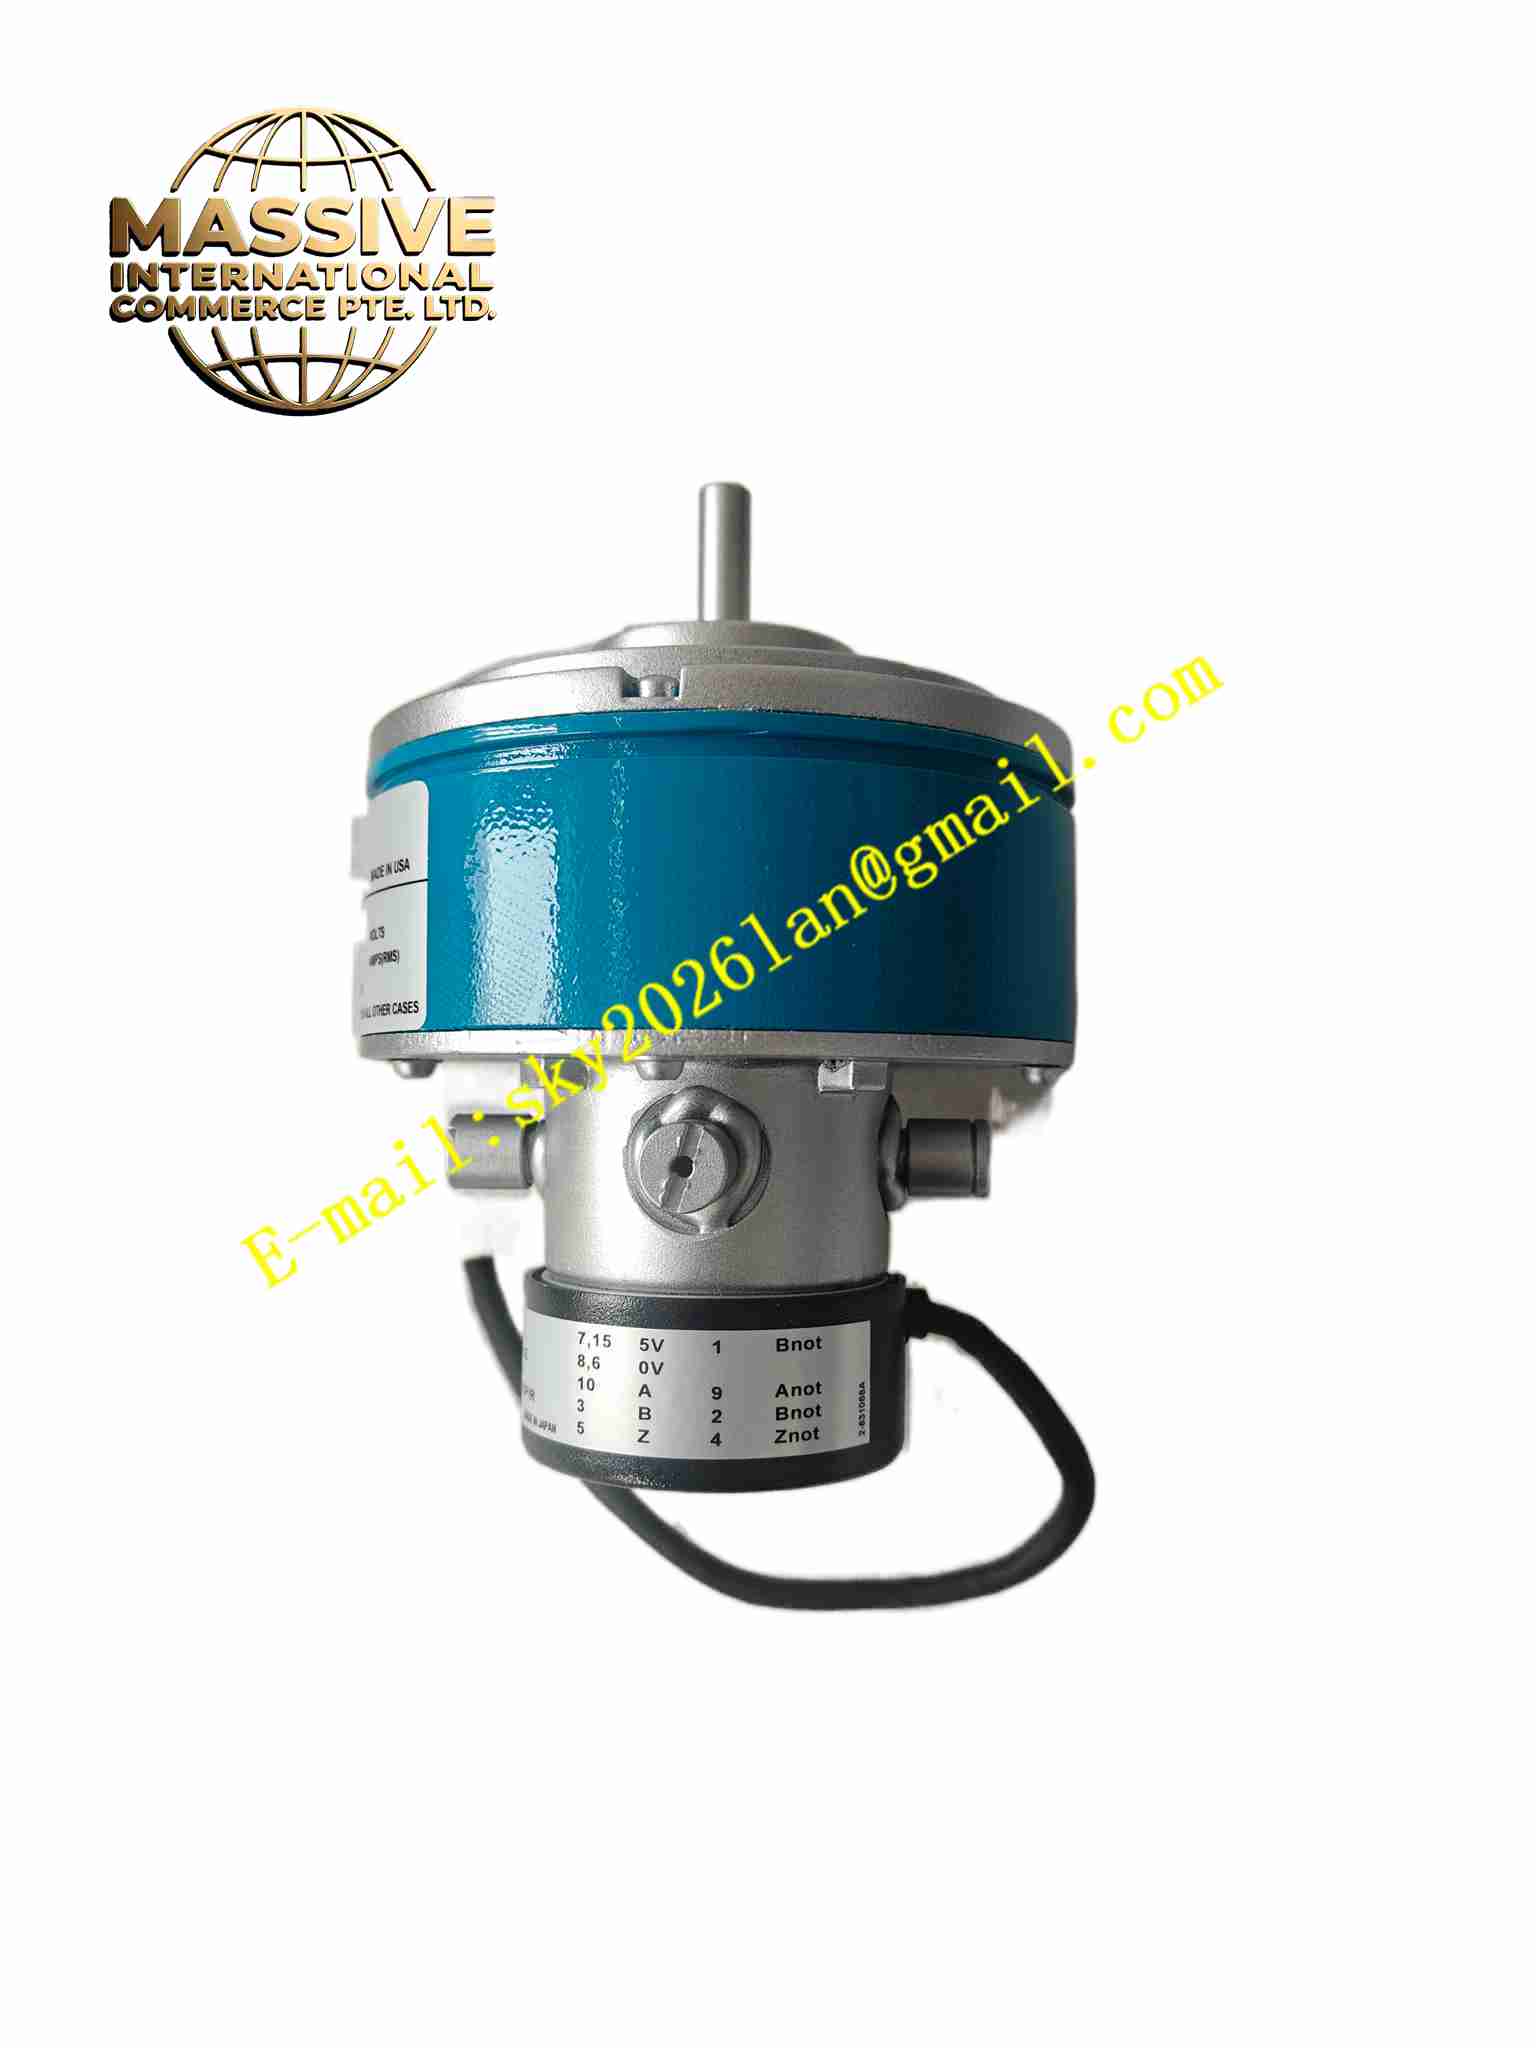
PACIFIC SCIENTIFIC 33VM52-000-29
Technical Specifications: Motor type: three-phase brushless DC servo motor Rated output power: 400 W Rated speed: 3000 rpm Rated torque: 1.27 Nm Peak torque: 3.8 Nm Feedback device: incremental encoder Motor voltage: 24 VDC to 48 VDC Operating temperature: 0 ℃ to 40 ℃ Shaft: single-ended output shaft with keyway Mounting: NEMA 23 flange
Functional Features: Brushless design eliminates commutator wear. Integrated encoder provides position and velocity feedback. High torque density compact package. Low cogging torque for smooth velocity regulation. Built-in Hall sensors for electronic commutation. Double-sealed bearings for extended service life.
Application Scenarios: CNC machine feed axis, industrial robot joint, packaging machine servo axis, printing press paper drive, material handling actuator.
Performance Parameters: Encoder resolution: 2500 pulses per revolution Rotor inertia: 0.45 kg·cm² Motor winding inductance: 2.5 mH Efficiency: greater than 85%
Material Composition: Motor housing: anodized aluminum. Shaft: hardened stainless steel. Bearings: sealed precision ball bearings. Encoder housing: engineering plastic. Magnet: neodymium rare earth.
Structural Features: Cylindrical motor housing with cooling fins. NEMA 23 mounting flange. Rear end cap houses encoder. Front output shaft with keyway. Motor cable exits from rear gland.
Working Principle: Three-phase stator windings generate rotating magnetic field. Hall sensors detect rotor magnet position. Drive electronics sequentially energize stator phases to maintain rotor rotation. Encoder disc rotates with motor shaft, photodetectors generate position pulse signals. Drive uses encoder feedback to close velocity and position loops.
Installation Requirements: Align motor shaft with load coupling using flexible coupling. Do not exceed allowable radial and axial shaft loads. Secure motor mounting bolts to specified torque. Connect motor power cable and encoder cable to matched drive. Keep cable bending radius above minimum value.
Precautions for Use: Do not exceed peak torque rating for extended duration. Protect motor cable from oil and coolant. Do not apply impact force to output shaft. Verify encoder cable shield grounding. Allow motor to reach thermal steady state before performance calibration.







