Description
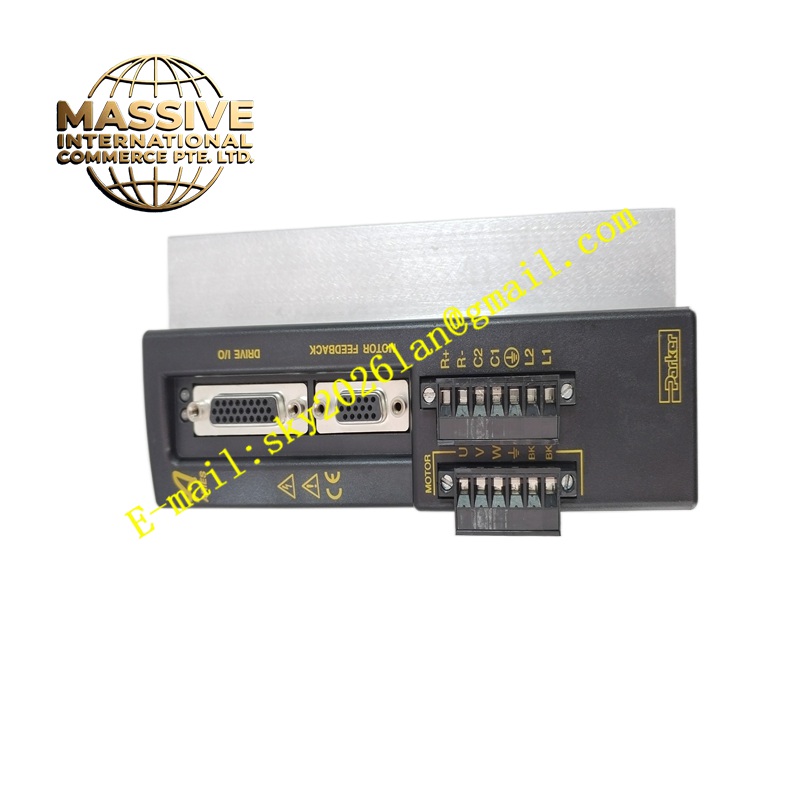
Parker AR-08AE-14293
Technical Specifications
- Brand: Parker Hannifin / Compumotor Division
- Model: AR-08AE-14293
- Product Family: Aries Series Digital Servo Drive
- Motor Output Power (Continuous): 750 Watts
- Motor Output Power (Peak): 2250 Watts
- Continuous Output Current (RMS): 4.5 Amps
- Peak Output Current (RMS): 13.5 Amps
- DC Bus Voltage: 170/340 VDC
- AC Input Voltage: 120/240 VAC, Single Phase, 50/60 Hz
- PWM Switching Frequency: 16 kHz or 32 kHz (motor dependent)
- Servo Update Rate: 62.5 microseconds ± 1 encoder count
- Command Input Resolution: 14-bit ADC, ±10V analog (torque/velocity control)
- Step/Direction Input: 2 MHz maximum (position control)
- Enable/Reset Input: 5-24 VDC logic level
- Encoder Input: 5 MHz (pre-quadrature), RS-422 compatible differential input
- Resolver Input: 12-bit A-to-D conversion (4096 counts/revolution, 11 arc-minute absolute accuracy)
- Fault Output: 5-24 VDC logic level
- Brake Output: Solid state, normally open, 1 Amp @ 24VDC maximum
- Operating Temperature: 0°C to 50°C (derated above 40°C)
- Storage Temperature: -40°C to 85°C
- Humidity: 5% to 95% non-condensing
- Protection Rating: IP20 (open chassis)
- Dimensions: Approximately 100mm × 150mm × 200mm (varies by configuration)
- Weight: Approximately 2.5 kg
Functional Features
- Advanced digital servo control with 62.5 microsecond update rate for exceptional dynamic response
- Dual-mode operation supporting both brushless and brushed servo motors
- Multiple feedback device compatibility including incremental encoders, absolute encoders, and resolvers
- 14-bit analog command input enabling smooth torque and velocity control
- High-speed step/direction interface supporting up to 2 MHz for precise position control
- Programmable PWM switching frequency (16 kHz or 32 kHz) optimizing motor performance and acoustic noise
- Integrated solid-state brake output for direct motor brake control
- Comprehensive fault protection including overcurrent, overvoltage, undervoltage, overtemperature, and following error
- Real-time fault output signaling for immediate system response to abnormal conditions
- Configurable via Parker’s motion control software tools for parameter tuning and diagnostics
- Compact form factor enabling space-efficient panel mounting
- Compatible with Parker’s 6K series motion controllers and other industry-standard controllers
- Custom firmware variant (-14293) providing application-specific functionality and parameter presets
Application Scenarios
- Industrial Robotics: Joint actuation and precision positioning in articulated and SCARA robots
- CNC Machine Tools: Axis drives for milling, turning, grinding, and routing machines
- Packaging Machinery: High-speed filling, capping, labeling, and case packing systems
- Printing and Converting: Web tension control, registration systems, and print cylinder drives
- Semiconductor Manufacturing: Wafer handling, die bonding, and precision inspection equipment
- Medical Equipment: Surgical robots, diagnostic imaging systems, and laboratory automation
- Textile Machinery: Yarn winding, weaving, and fabric handling systems
- Material Handling: Conveyor systems, pick-and-place operations, and automated storage/retrieval
- Test and Measurement: Precision motion stages for material testing and calibration equipment
Performance Parameters
- Continuous Power Output: 750 Watts at rated motor speed
- Peak Power Output: 2250 Watts for short-duration high-dynamic moves
- Current Control Bandwidth: Optimized for high-bandwidth torque response
- Position Loop Bandwidth: Configurable up to several hundred Hz depending on mechanical system
- Velocity Loop Bandwidth: Configurable for smooth low-speed operation and high-speed tracking
- Positioning Accuracy: ±1 encoder count (encoder resolution dependent)
- Velocity Regulation: ±0.01% of rated speed under varying load conditions
- Torque Ripple: Minimized through sinusoidal commutation and advanced current control algorithms
- Dynamic Response: 62.5 microsecond servo update enabling rapid acceleration and deceleration
- Efficiency: >95% power conversion efficiency minimizing heat generation
- Thermal Performance: Optimized heat sink design for continuous operation at rated power
Material Composition
- Power Stage: IGBT or MOSFET power semiconductors for efficient power switching
- DC Link Capacitors: High-temperature electrolytic capacitors rated for bus voltage
- Gate Driver Circuitry: Isolated gate driver ICs with desaturation detection and protection
- Control Processor: High-performance digital signal processor (DSP) for real-time control execution
- Current Sensors: Hall-effect or shunt-based current sensing with high bandwidth
- Heat Sink: Extruded aluminum heat sink with optimized fin geometry for natural convection cooling
- Housing: Sheet metal enclosure with ventilation slots and mounting flanges
- PCB Substrate: High-Tg FR-4 printed circuit board with conformal coating for environmental protection
- Connectors: Industrial-grade terminal blocks and circular connectors for power and signal connections
- Internal Wiring: High-temperature insulated wiring with proper strain relief
Structural Features
- Compact rectangular form factor optimized for DIN rail or panel mounting
- Front-accessible terminal blocks for power, motor, encoder, and I/O connections
- LED status indicators for power, fault, enable, and communication status
- Removable terminal blocks enabling quick wiring and module replacement
- Integrated heat sink with thermal cutout protection preventing overheating damage
- Ventilation slots on top and bottom surfaces promoting natural convection airflow
- Mounting holes on rear panel for secure installation to equipment backplanes
- Clear labeling of all terminal connections with wire size and torque specifications
- Internal fuse or circuit breaker for input power protection
- Grounding stud for proper equipment grounding and EMI shielding
- Optional DIN rail mounting clip for rapid installation in control cabinets
Working Principle
The Parker AR-08AE-14293 operates as a closed-loop digital servo drive controlling the position, velocity, or torque of a connected servo motor. The drive receives AC input power (120/240 VAC) which is rectified to a DC bus voltage (170/340 VDC) by an internal rectifier and filtered by DC link capacitors. The digital signal processor (DSP) executes servo control algorithms at a 62.5 microsecond update rate, processing feedback from the motor’s encoder or resolver to determine the motor’s actual position, velocity, and current.