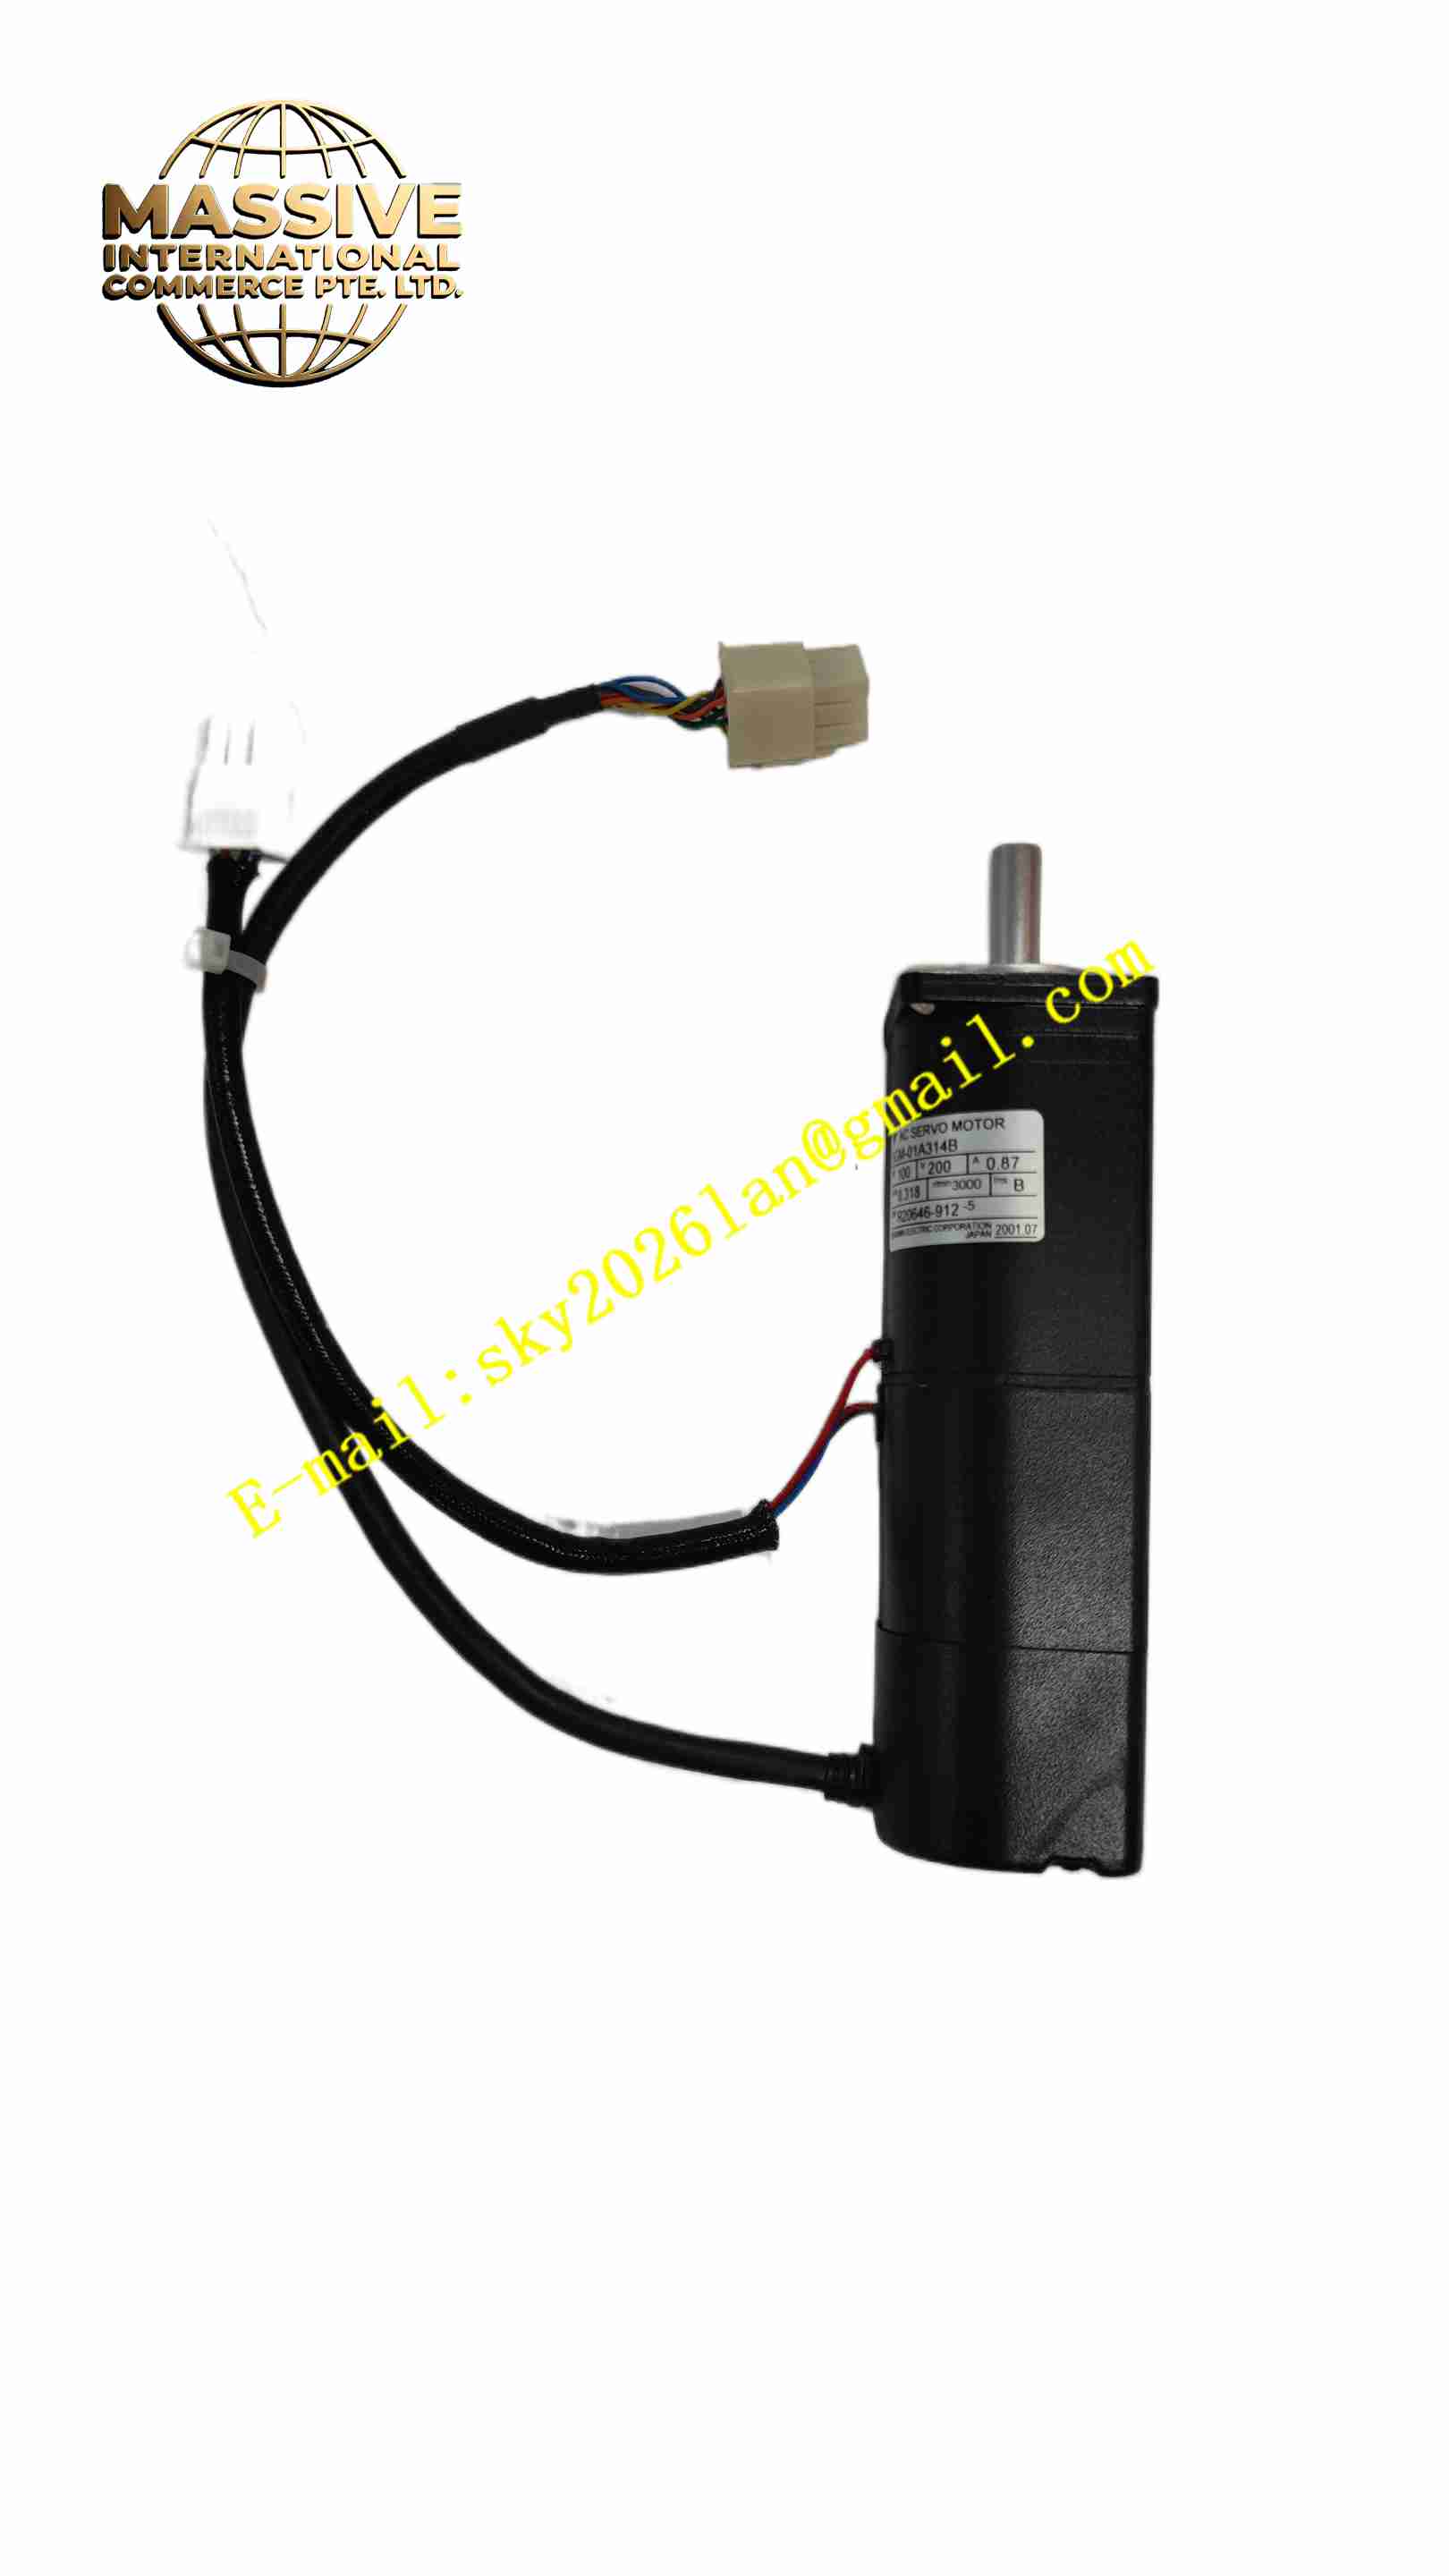
Description
Technical Specifications
- Brand: Yaskawa
- Model: SGM-01A314B
- Series: Yaskawa SGM AC servo motor
- Output power: 100 W / 0.13 HP
- Rated voltage: 200 V class
- Rated speed: 3000 r/min
- Encoder type: Incremental encoder, 2048 P/R
- Brake: No holding brake for the 314 variant; 316 variants include a brake
- Protection structure: IP55 for the motor body, excluding connector and output shaft faces
- Mounting: Flange-mounted servo motor
- Shaft type: Smooth shaft for the 314 variant
- Mass: Approximately 0.7 kg for the non-brake version
- Allowable radial load: Approximately 78 N at 20 mm from the mounting surface
- Allowable thrust load: Approximately 49 N
- Operating temperature: Typically 0 °C to 40 °C for standard servo motor installation
- Storage temperature: Typically −20 °C to +80 °C depending on product manual
- Compatible drive: Yaskawa SGDA or related SGM-series servo drives
Functional Features
- Provides precise rotary motion for automation equipment.
- Uses a permanent-magnet synchronous motor design.
- Includes a 2048 P/R incremental encoder for feedback.
- Supports closed-loop position and speed control with a compatible drive.
- Designed for compact machines requiring small servo motors.
- IP55 motor body improves resistance to dust and water spray.
- Low-inertia rotor supports fast acceleration and deceleration.
- Suitable for continuous duty in industrial environments.
Application Scenarios
- Small industrial robots and manipulators.
- Pick-and-place equipment.
- Packaging and labeling machines.
- Semiconductor and electronics assembly equipment.
- Precision positioning stages.
- Textile and light manufacturing machinery.
- Laboratory automation systems.
- Conveyor indexing and material handling equipment.
Performance Parameters
- 100 W rated output power.
- 200 V class voltage specification.
- 3000 r/min rated speed.
- 2048 P/R incremental encoder.
- Approximately 0.7 kg motor mass for the non-brake version.
- IP55 motor body protection excluding connectors and shaft.
- Exact rated torque, peak torque, rated current, peak current, rotor inertia, electrical time constant, insulation class, encoder cable length and thermal characteristics must be confirmed from the Yaskawa SGM series user manual and motor nameplate.
Material Composition
- Aluminum or steel motor housing.
- Permanent-magnet rotor.
- Stator windings with insulated copper wire.
- Precision bearings.
- Incremental encoder assembly.
- Motor shaft and flange.
- Connector and cable interface.
- Sealing elements for IP55 protection.
Structural Features
- Compact cylindrical servo motor body.
- Flange mounting with precision bolt holes.
- Smooth output shaft for coupling.
- Encoder mounted at the rear of the motor.
- Motor and encoder cable connectors.
- Sealed body construction for improved environmental protection.
- Nameplate with model, serial number and electrical ratings.
Working Principle
The SGM-01A314B operates as a permanent-magnet AC servo motor. When driven by a compatible Yaskawa servo drive, the stator windings receive controlled AC currents that create a rotating magnetic field. The permanent-magnet rotor follows this field, producing torque and rotation. The incremental encoder continuously sends position and speed pulses to the servo drive. The drive compares the actual motor position with the commanded position and adjusts the output current to maintain accurate motion control.
Installation Requirements
- Mount the motor securely to a rigid machine surface.
- Align the motor shaft and coupling carefully to avoid excessive radial or thrust load.
- Do not strike the shaft or encoder during installation.
- Use compatible Yaskawa servo drives and encoder cables.
- Keep encoder cables away from power cables to reduce interference.
- Ensure the operating environment meets the motor IP and temperature ratings.
- Verify wiring polarity and connector orientation before power-up.
- Confirm drive parameters match the motor model.
Precautions for Use
- Do not exceed the rated speed, torque or temperature limits.
- Do not disassemble the motor or encoder.
- Avoid oil, water or chemical ingress at the shaft and connector areas.
- Protect the encoder cable from bending, pulling and abrasion.
- Do not apply excessive radial or axial load to the motor shaft.
- Use proper coupling alignment to prevent bearing damage.
- Follow Yaskawa safety instructions during installation and maintenance.
- Refer to the official Yaskawa SGM series user manual for exact ratings, wiring and maintenance procedures.